Related Experiment Video
Updated: Nov 3, 2025


Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
A Symmetric Three Degree of Freedom Tensegrity Mechanism with Dual Operation Modes for Robot Actuation
1Department of Electronic Engineering, University of York, Heslington, York YO10 5DD, UK.

Abstract:
Tensegrity robots that use bio-inspired structures have many superior properties over conventional robots with regard to strength, weight, compliance and robustness, which are indispensable to planetary exploration and harsh environment applications. Existing research has presented various tensegrity robots with abundant capabilities in broad scenarios but mostly not focused on articulation and manipulability. In this paper, we propose a novel tensegrity mechanism for robot actuation which greatly improves the agility and efficiency compared with existing ones. The design integrates two separate tensegrity substructures inspired by shoulder and hip joints of the human body and features a similar form to a hexapod platform. It mitigates detrimental antagonistic forces in the structural network for optimising actuation controllability and efficiency. We validated the design both on a prototype and in a Chrono Engine simulation that represents the first physically accurate simulation of a wheeled tensegrity robot. It can reach up to approximately 58.9∘, 59.4∘ and 47.1∘ in pitch, yaw and roll motion, respectively. The mechanism demonstrates good agility and controllability as an actuated robot linkage while preserving desirable properties of tensegrity structures. The design would potentially inspire more possibilities of agile tensegrity implementations that enable future robots with enhanced compliance, robustness and efficiency without a tradeoff.


Related Concept Videos
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
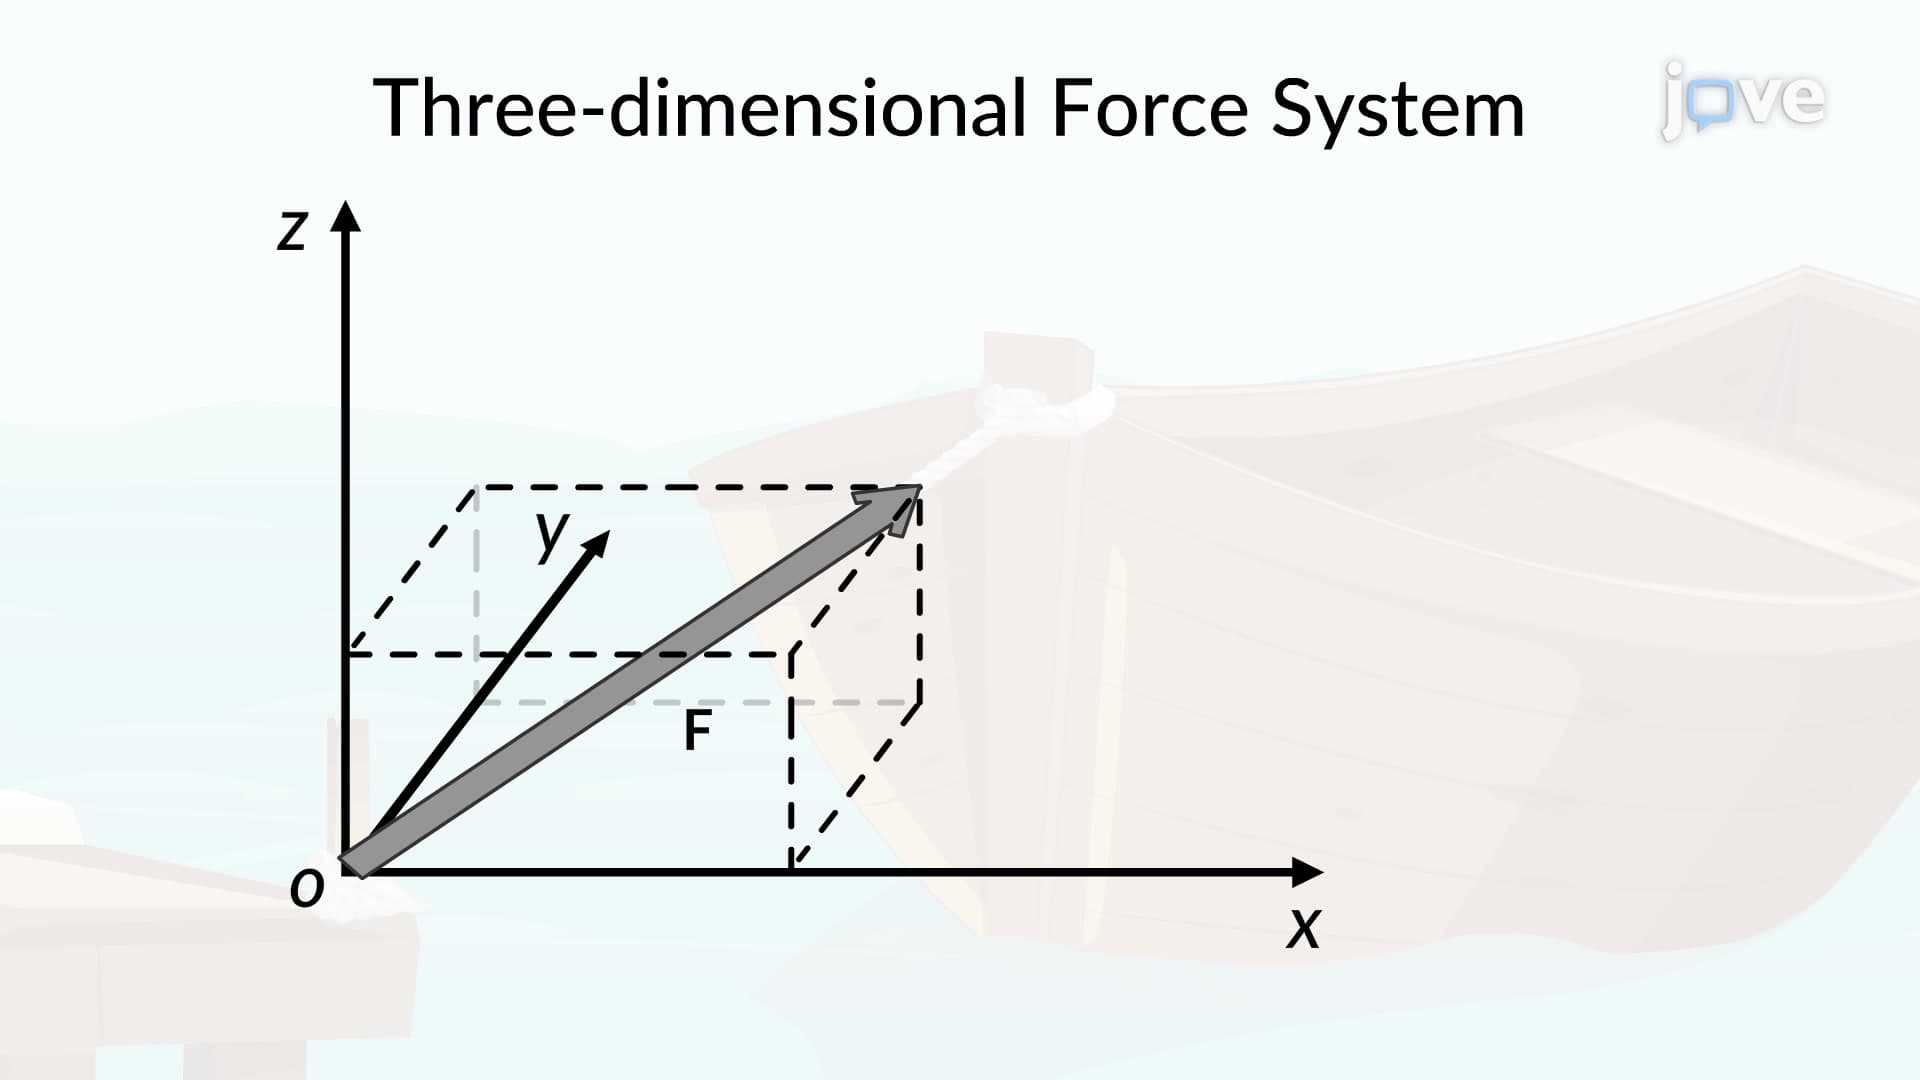
Three-Dimensional Force System
 01:16
Torsion of Noncircular Members
 01:09
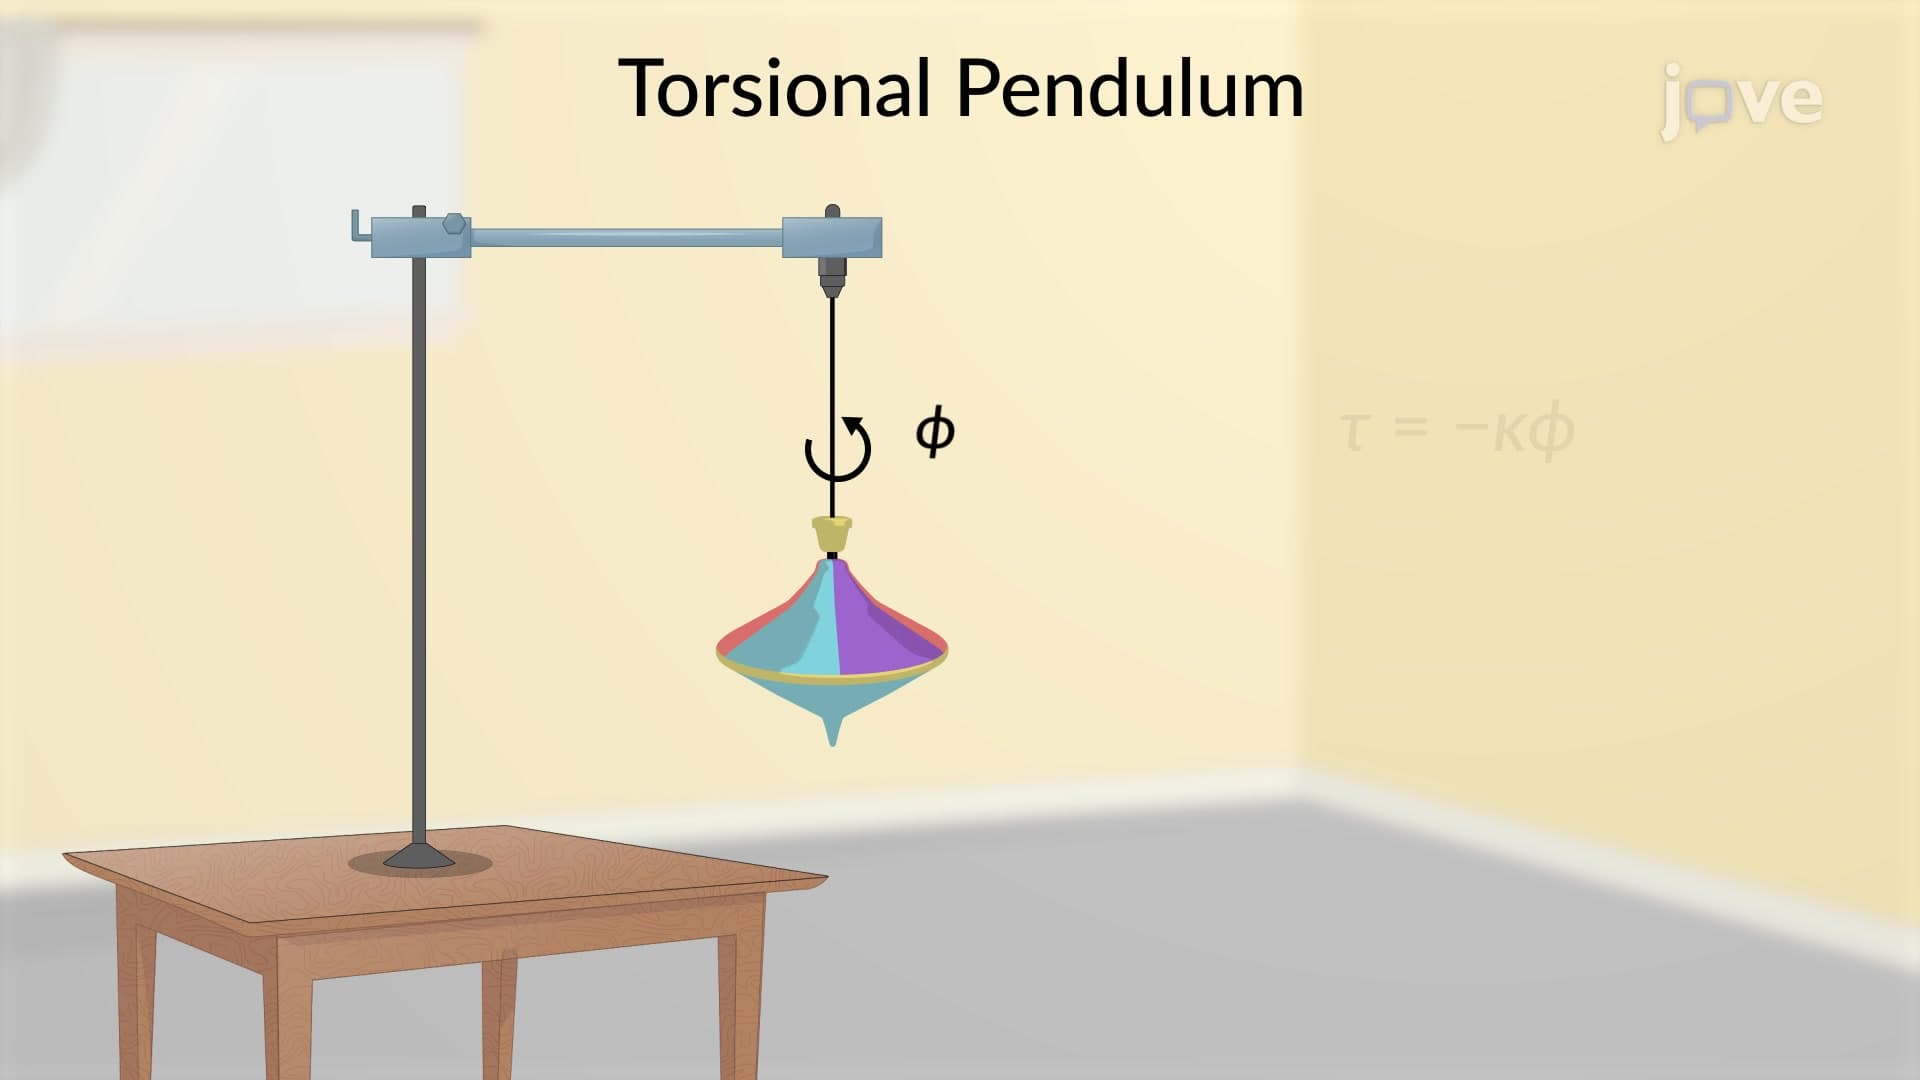
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...