Related Experiment Video
Updated: Nov 3, 2025


Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Reducing the metabolic energy of walking and running using an unpowered hip exoskeleton
Tiancheng Zhou1, Caihua Xiong2, Juanjuan Zhang3
1Institute of Rehabilitation and Medical Robotics, State Key Lab of Digital Manufacturing Equipment and Technology, Huazhong University of Science and Technology, Wuhan, 430074, Hubei, China.

Background:
Walking and running are the most common means of locomotion in human daily life. People have made advances in developing separate exoskeletons to reduce the metabolic rate of walking or running. However, the combined requirements of overcoming the fundamental biomechanical differences between the two gaits and minimizing the metabolic penalty of the exoskeleton mass make it challenging to develop an exoskeleton that can reduce the metabolic energy during both gaits. Here we show that the metabolic energy of both walking and running can be reduced by regulating the metabolic energy of hip flexion during the common energy consumption period of the two gaits using an unpowered hip exoskeleton.
Methods:
We analyzed the metabolic rates, muscle activities and spatiotemporal parameters of 9 healthy subjects (mean ± s.t.d; 24.9 ± 3.7 years, 66.9 ± 8.7 kg, 1.76 ± 0.05 m) walking on a treadmill at a speed of 1.5 m s-1 and running at a speed of 2.5 m s-1 with different spring stiffnesses. After obtaining the optimal spring stiffness, we recruited the participants to walk and run with the assistance from a spring with optimal stiffness at different speeds to demonstrate the generality of the proposed approach.
Results:
We found that the common optimal exoskeleton spring stiffness for walking and running was 83 Nm Rad-1, corresponding to 7.2% ± 1.2% (mean ± s.e.m, paired t-test p < 0.01) and 6.8% ± 1.0% (p < 0.01) metabolic reductions compared to walking and running without exoskeleton. The metabolic energy within the tested speed range can be reduced with the assistance except for low-speed walking (1.0 m s-1). Participants showed different changes in muscle activities with the assistance of the proposed exoskeleton.
Conclusions:
This paper first demonstrates that the metabolic cost of walking and running can be reduced using an unpowered hip exoskeleton to regulate the metabolic energy of hip flexion. The design method based on analyzing the common energy consumption characteristics between gaits may inspire future exoskeletons that assist multiple gaits. The results of different changes in muscle activities provide new insight into human response to the same assistive principle for different gaits (walking and running).
More Related Videos
 06:00
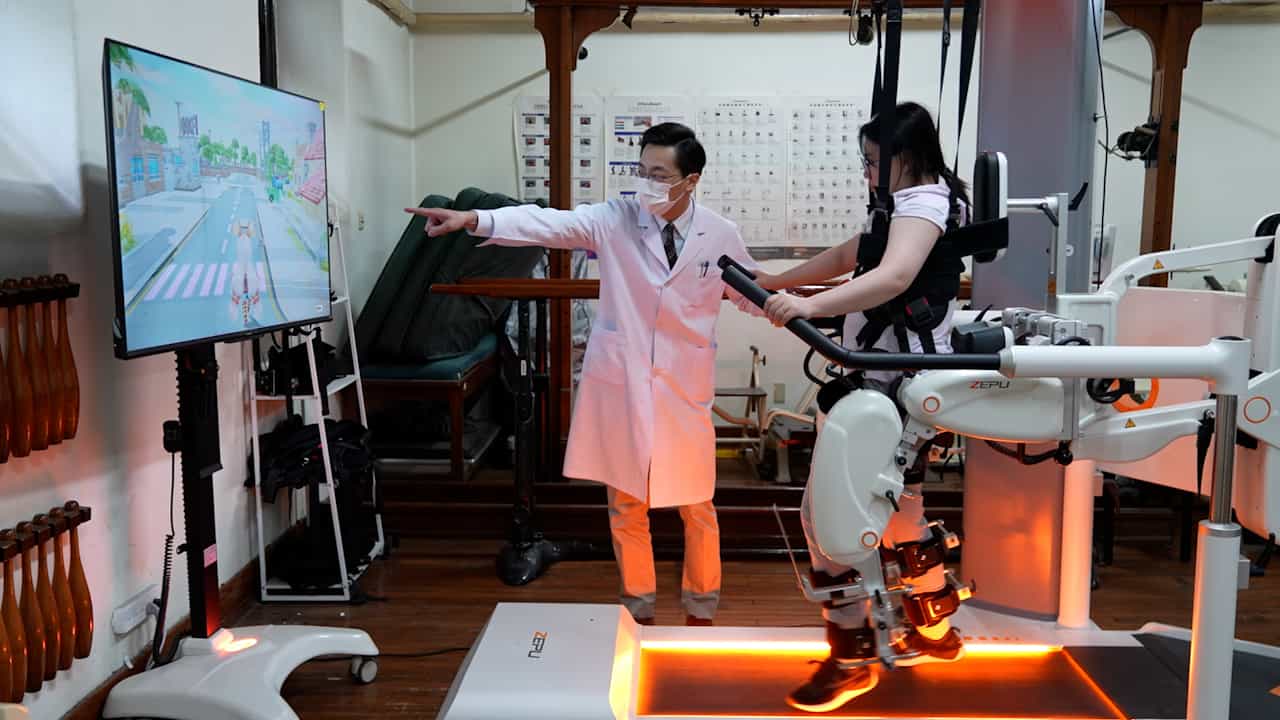
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014