Related Experiment Video
Updated: Nov 2, 2025
Flapping Soft Fin Deformation Modeling using Planar Laser-Induced Fluorescence Imaging
Published on: April 28, 2022
A Deep Learning Method for Vision Based Force Prediction of a Soft Fin Ray Gripper Using Simulation Data
Daniel De Barrie1,2, Manjari Pandya3, Harit Pandya2
1BioRobotics and Medical Technologies Laboratory, School of Engineering, University of Lincoln, Lincoln, United Kingdom.

Abstract:
Soft robotic grippers are increasingly desired in applications that involve grasping of complex and deformable objects. However, their flexible nature and non-linear dynamics makes the modelling and control difficult. Numerical techniques such as Finite Element Analysis (FEA) present an accurate way of modelling complex deformations. However, FEA approaches are computationally expensive and consequently challenging to employ for real-time control tasks. Existing analytical techniques simplify the modelling by approximating the deformed gripper geometry. Although this approach is less computationally demanding, it is limited in design scope and can lead to larger estimation errors. In this paper, we present a learning based framework that is able to predict contact forces as well as stress distribution from soft Fin Ray Effect (FRE) finger images in real-time. These images are used to learn internal representations for deformations using a deep neural encoder, which are further decoded to contact forces and stress maps using separate branches. The entire network is jointly learned in an end-to-end fashion. In order to address the challenge of having sufficient labelled data for training, we employ FEA to generate simulated images to supervise our framework. This leads to an accurate prediction, faster inference and availability of large and diverse data for better generalisability. Furthermore, our approach is able to predict a detailed stress distribution that can guide grasp planning, which would be particularly useful for delicate objects. Our proposed approach is validated by comparing the predicted contact forces to the computed ground-truth forces from FEA as well as real force sensor. We rigorously evaluate the performance of our approach under variations in contact point, object material, object shape, viewing angle, and level of occlusion.


Related Concept Videos
 01:30
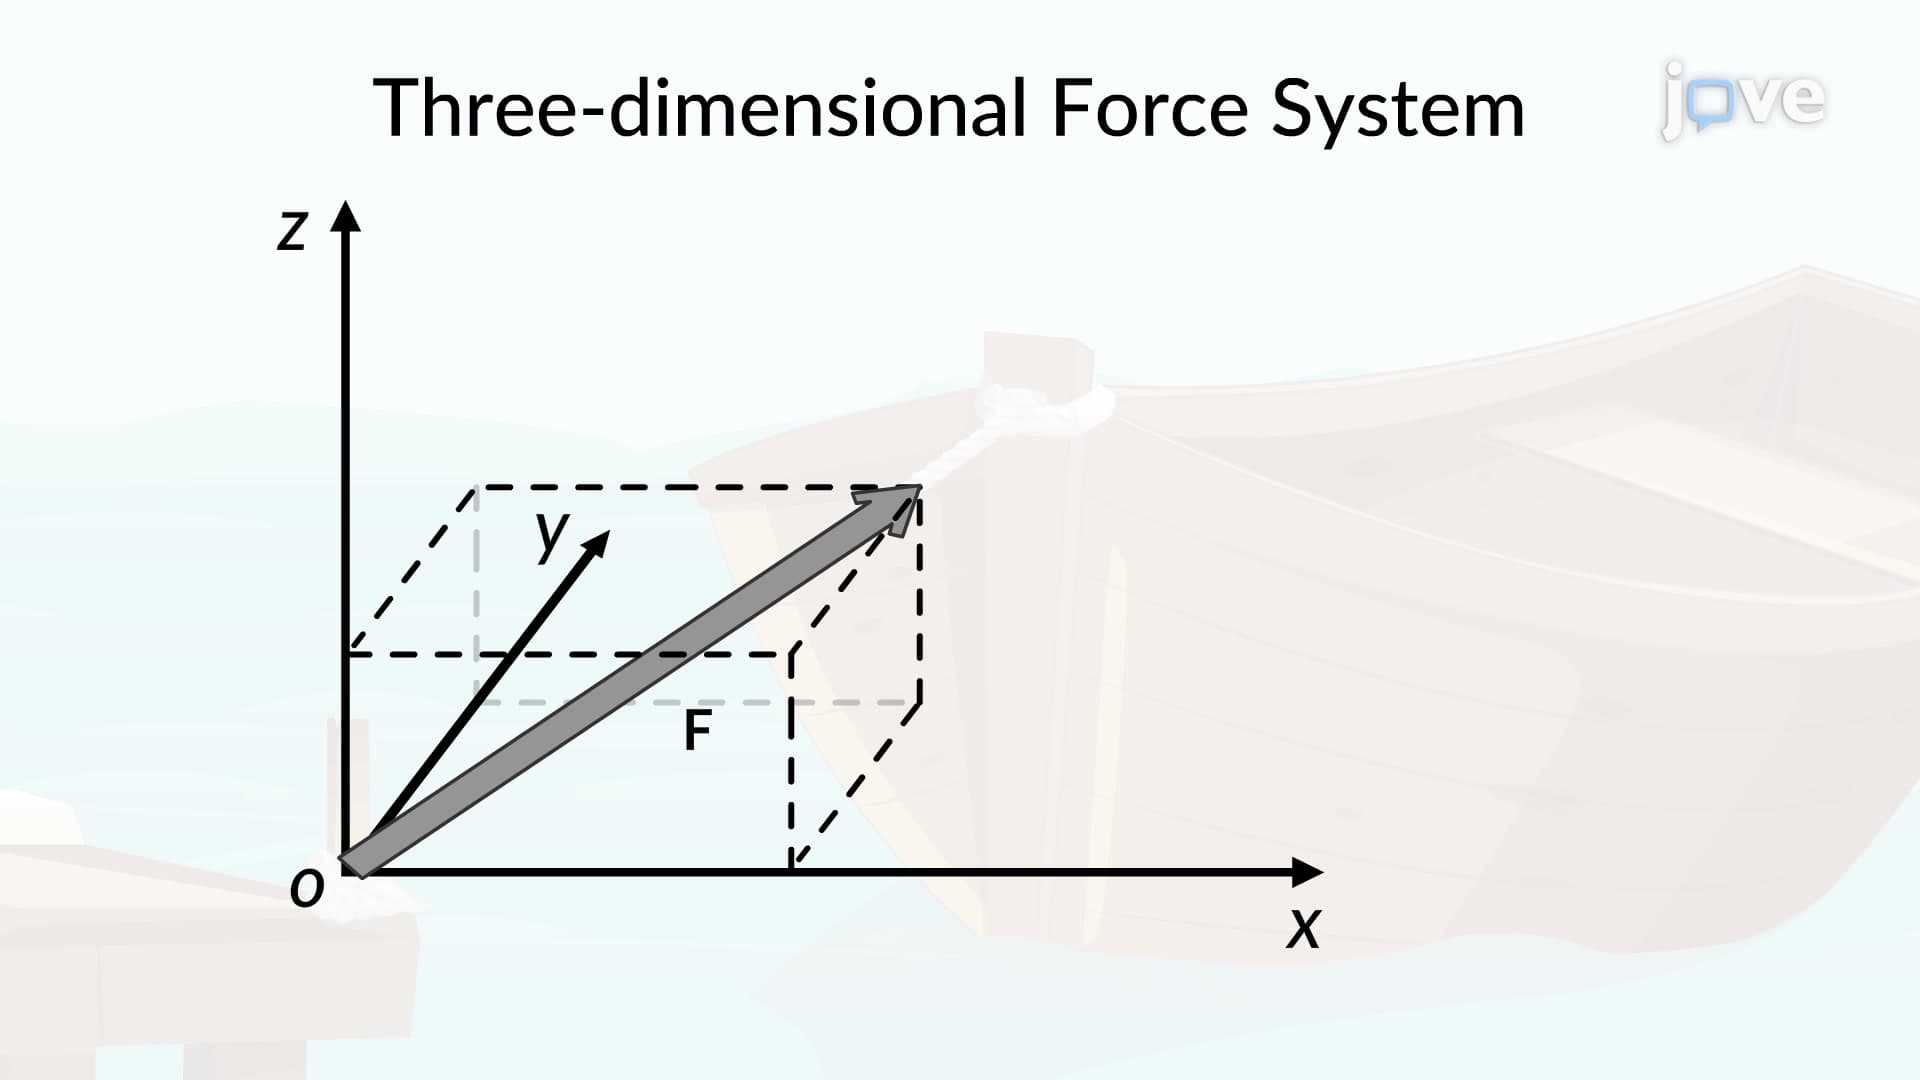
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Three-Dimensional Force System
 01:29
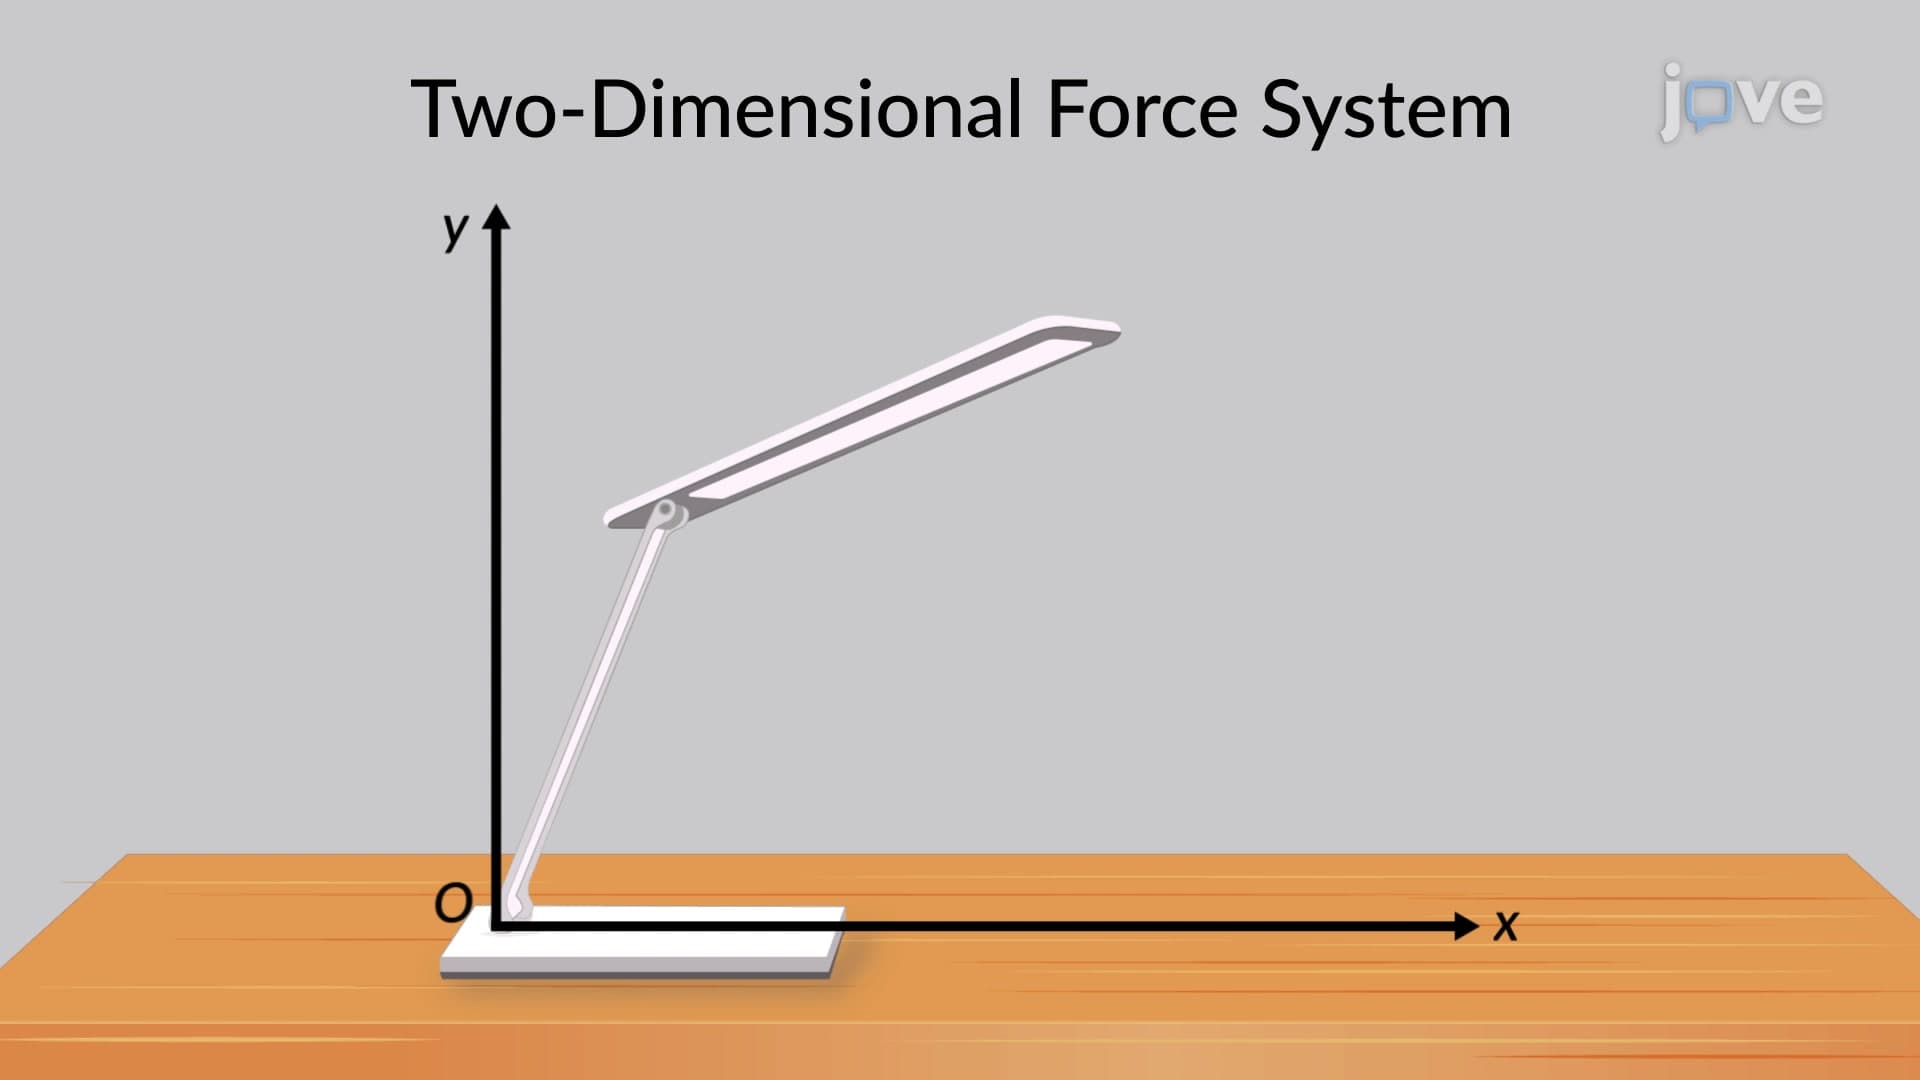
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:20
Two-Dimensional Force System
 01:05
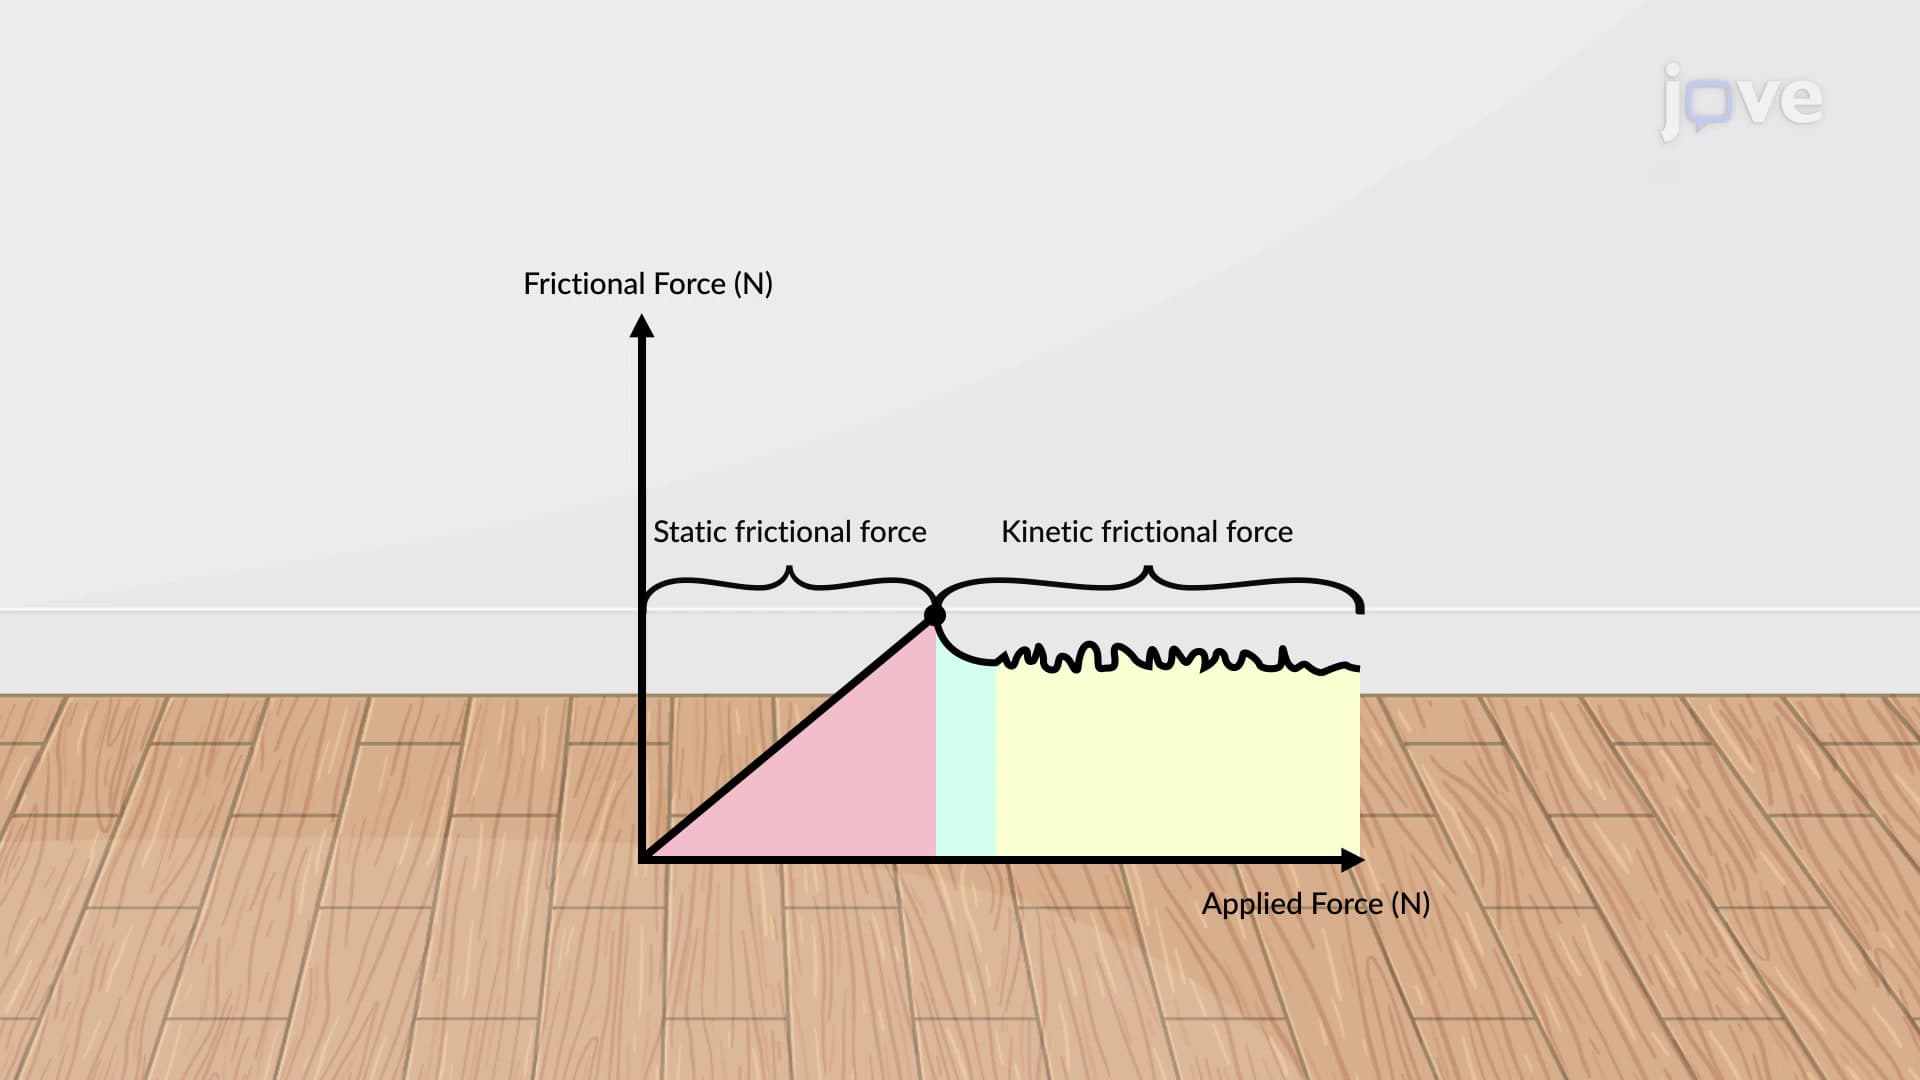
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...