Fixed-time consensus tracking control with connectivity preservation for strict-feedback nonlinear multi-agent systems
Related Experiment Video
Updated: Nov 1, 2025

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Ya Liu1, Fan Zhang1, Panfeng Huang1
1The Research Center for Intelligent Robotics, School of Astronautics, Northwestern Polytechnical University, Xi'an, Shaanxi 710072, China; The National Key Laboratory of Aerospace Flight Dynamics, Xi'an, Shaanxi 710072, China.

Abstract:
This paper deliberates fixed-time consensus tracking control for strict-feedback nonlinear multi-agent systems with limited communication/sensing range constraints. First, both potential function and coordinate error transformation surface are designed to make the constraints implicit. Next, based on the synthesis of neural network and adaptive technology, the fixed-time virtual variable is proposed without the upper bounds of estimation errors and disturbances. Then, a fixed-time distributed consensus tracking protocol is designed under backstepping method with a fixed-time differentiator to avoid singularity. Lyapunov stability analysis demonstrates that the closed-loop system under the designed control strategy can accomplish the convergence within fixed time, simultaneously connectivity preservation can be guaranteed. Finally, numerical emulation corroborates the availability of the designed control strategy.


Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
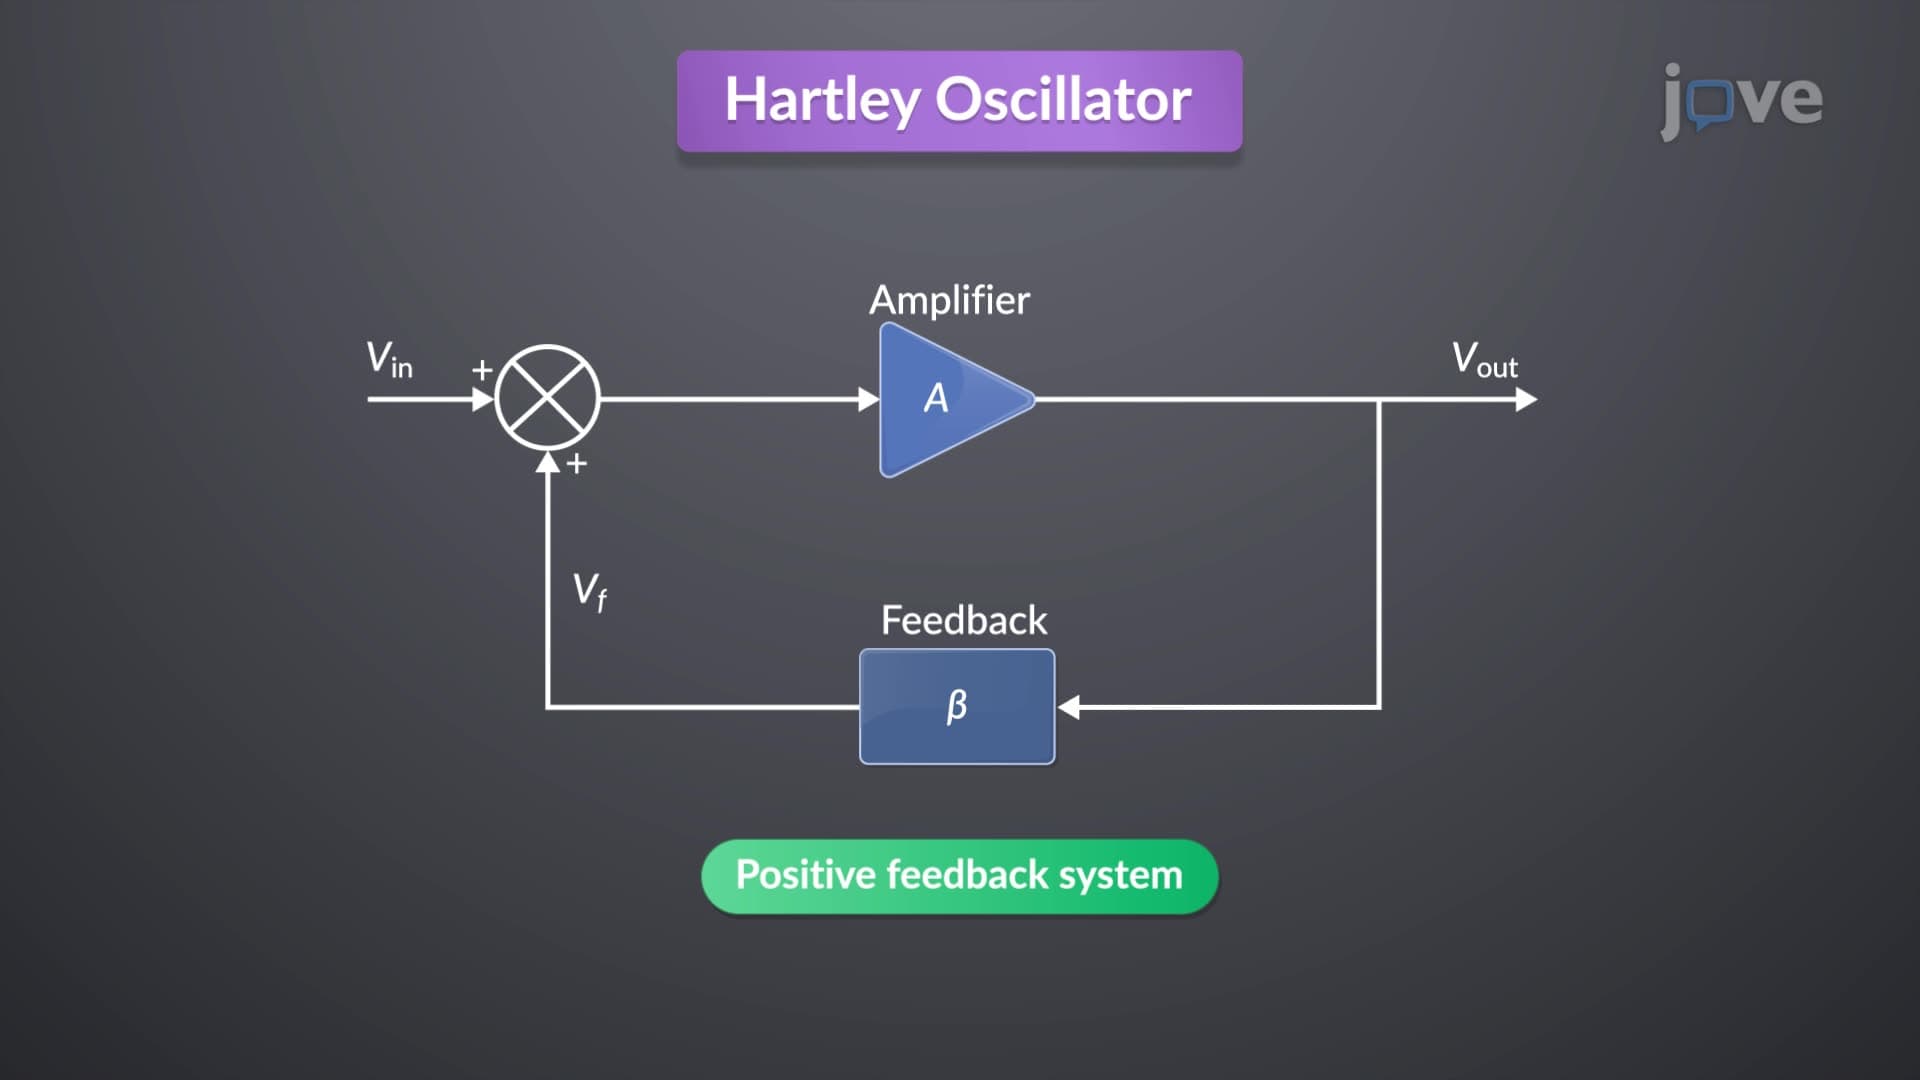 01:23
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:10
Control Systems
At the heart...