Related Experiment Video
Updated: Oct 30, 2025

Methods for Measuring the Orientation and Rotation Rate of 3D-printed Particles in Turbulence
Published on: June 24, 2016
Rapid computational cell-rotation around arbitrary axes in 3D with multi-core fiber
Jiawei Sun1,2, Nektarios Koukourakis1,2, Jochen Guck3,4
1Laboratory of Measurement and Sensor System Technique, TU Dresden, Helmholtzstrasse 18, 01069 Dresden, Germany.

Abstract:
Optical trapping is a vital tool in biology, allowing precise optical manipulation of nanoparticles, micro-robots, and cells. Due to the low risk of photodamage and high trap stiffness, fiber-based dual-beam traps are widely used for optical manipulation of large cells. Besides trapping, advanced applications like 3D refractive index tomography need a rotation of cells, which requires precise control of the forces, for example, the acting-point of the forces and the intensities in the region of interest (ROI). A precise rotation of large cells in 3D about arbitrary axes has not been reported yet in dual-beam traps. We introduce a novel dual-beam optical trap in which a multi-core fiber (MCF) is transformed to a phased array, using wavefront shaping and computationally programmable light. The light-field distribution in the trapping region is holographically controlled within 0.1 s, which determines the orientation and the rotation axis of the cell with small retardation. We demonstrate real-time controlled rotation of HL60 cells about all 3D axes with a very high degree of freedom by holographic controlled light through an MCF with a resolution close to the diffraction limit. For the first time, the orientation of the cell can be precisely controlled about all 3D axes in a dual-beam trap. MCFs provide much higher flexibility beyond the bulky optics, enabling lab-on-a-chip applications and can be easily integrated for applications like contactless cell surgery, refractive index tomography, cell-elasticity measurement, which require precise 3D manipulation of cells.
Related Concept Videos
 01:26
Rotational Motion about a Fixed Axis
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:18
Equation of Motion: Rotation About a Fixed Axis
The tangential component is dependent on the direction of the angular acceleration of the flywheel. The tangential component of the acceleration propels the flywheel along its path. On the other hand,...
 01:11
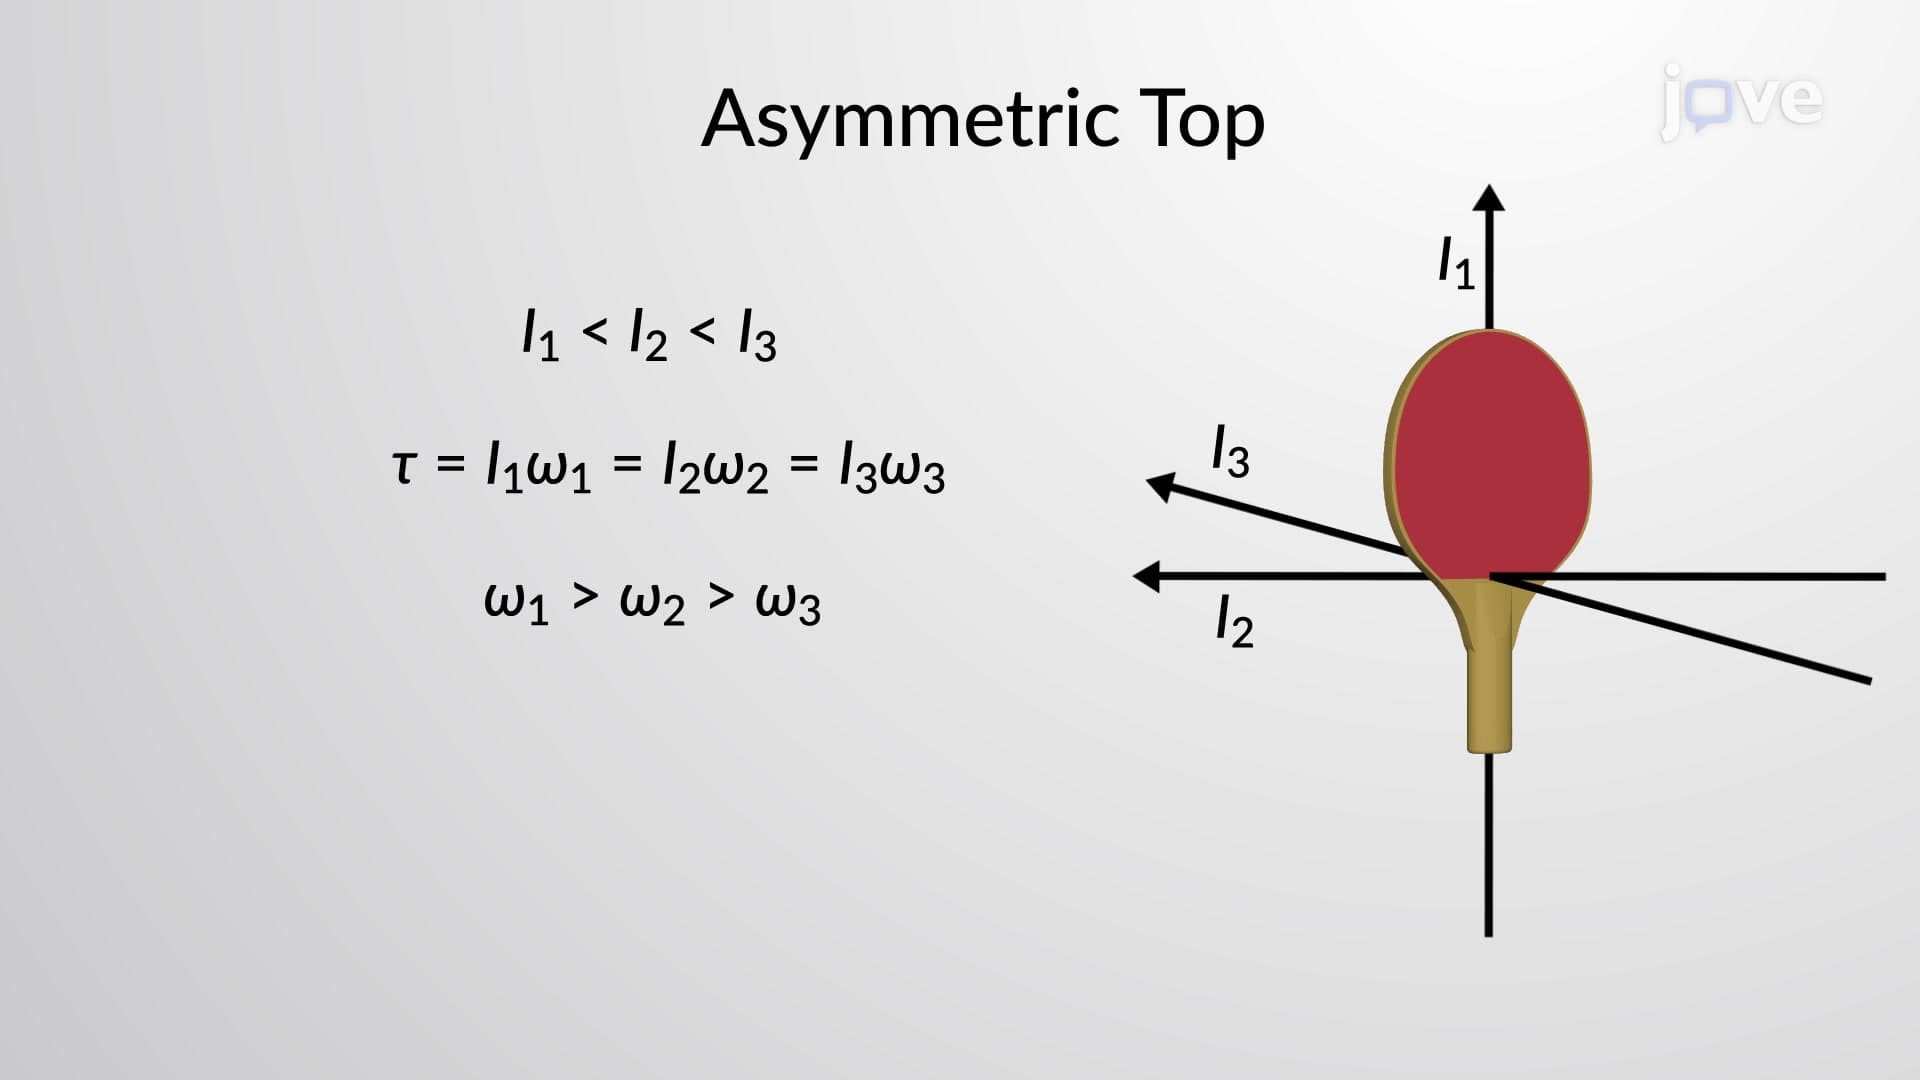
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...