Learning Then, Learning Now, and Every Second in Between: Lifelong Learning With a Simulated Humanoid Robot
Related Experiment Video
Updated: Oct 28, 2025
Designing and Implementing Nervous System Simulations on LEGO Robots
Published on: May 25, 2013
Aleksej Logacjov1, Matthias Kerzel1, Stefan Wermter1
1Department of Informatics, Research Group Knowledge Technology, Universität Hamburg, Hamburg, Germany.

Abstract:
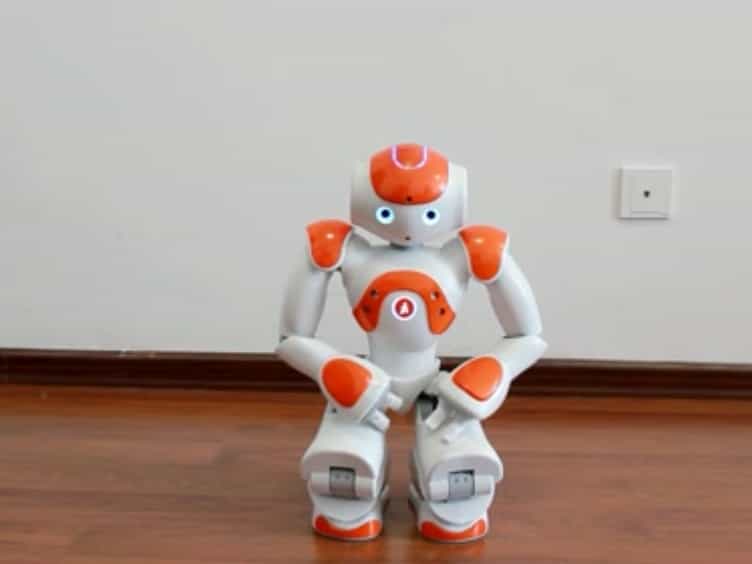
Long-term human-robot interaction requires the continuous acquisition of knowledge. This ability is referred to as lifelong learning (LL). LL is a long-standing challenge in machine learning due to catastrophic forgetting, which states that continuously learning from novel experiences leads to a decrease in the performance of previously acquired knowledge. Two recently published LL approaches are the Growing Dual-Memory (GDM) and the Self-organizing Incremental Neural Network+ (SOINN+). Both are growing neural networks that create new neurons in response to novel sensory experiences. The latter approach shows state-of-the-art clustering performance on sequentially available data with low memory requirements regarding the number of nodes. However, classification capabilities are not investigated. Two novel contributions are made in our research paper: (I) An extended SOINN+ approach, called associative SOINN+ (A-SOINN+), is proposed. It adopts two main properties of the GDM model to facilitate classification. (II) A new LL object recognition dataset (v-NICO-World-LL) is presented. It is recorded in a nearly photorealistic virtual environment, where a virtual humanoid robot manipulates 100 different objects belonging to 10 classes. Real-world and artificially created background images, grouped into four different complexity levels, are utilized. The A-SOINN+ reaches similar state-of-the-art classification accuracy results as the best GDM architecture of this work and consists of 30 to 350 times fewer neurons, evaluated on two LL object recognition datasets, the novel v-NICO-World-LL and the well-known CORe50. Furthermore, we observe an approximately 268 times lower training time. These reduced numbers result in lower memory and computational requirements, indicating higher suitability for autonomous social robots with low computational resources to facilitate a more efficient LL during long-term human-robot interactions.
Related Concept Videos
 01:22
Purposive Learning
 01:21
Cognitive Learning
E. C. Tolman's theory of purposive behavior emphasizes that much behavior is goal-directed. He argued that to understand behavior, we must look at the entire sequence of actions leading to a goal. For instance, high school students study hard, not just due to past reinforcement but also to achieve the goal of getting into a good college.
Tolman introduced the idea that behavior is influenced by...
 01:12
Observational Learning
 01:18
Introduction to Learning
In contrast to learned behaviors, unlearned behaviors such as crying, sexual...
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:30
Machines: Problem Solving II