Related Experiment Video
Updated: Oct 27, 2025

Rod-based Fabrication of Customizable Soft Robotic Pneumatic Gripper Devices for Delicate Tissue Manipulation
Published on: August 2, 2016
Dynamic Modeling of Cable Driven Elongated Surgical Instruments for Sensorless Grip Force Estimation
Yangming Li1, Muneaki Miyasaka2, Mohammad Haghighipanah1
1Department of Electrical Engineering, University of Washington, Seattle, WA, USA 98195.

Abstract:
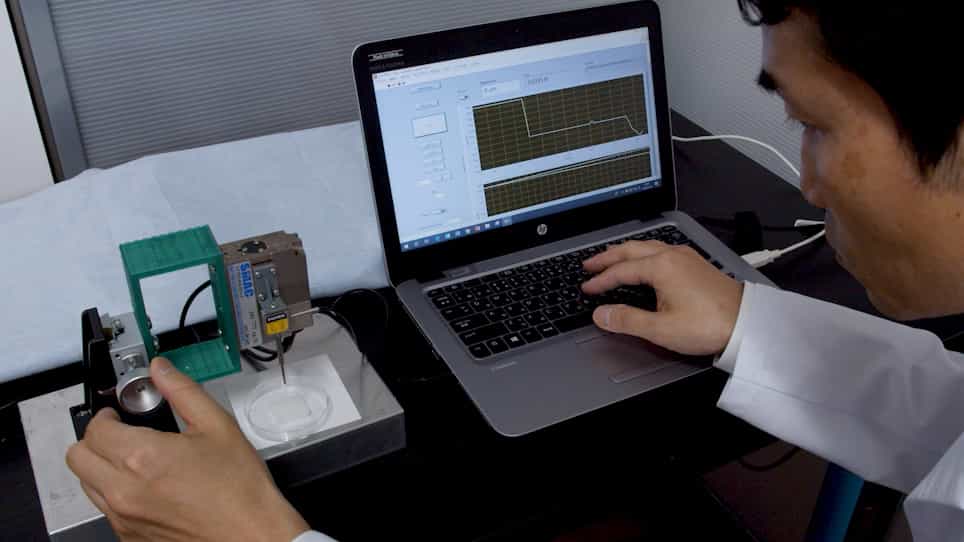
Haptic feedback plays a key role in surgeries, but it is still a missing component in robotic Minimally Invasive Surgeries. This paper proposes a dynamic model-based sensorless grip force estimation method to address the haptic perception problem for commonly used elongated cable-driven surgical instruments. Cable and cable-pulley properties are studied for dynamic modeling; grip forces, along with driven motor and gripper jaw positions and velocities are jointly estimated with Unscented Kalman Filter and only motor encoder readings and motor output torques are assumed to be known. A bounding filter is used to compensate for model inaccuracy and to improve method robustness. The proposed method was validated on a 10mm gripper which is driven by a Raven-II surgical robot. The gripper was equipped with 1-dimensional force sensors which served as ground truth data. The experimental results showed that the proposed method provides sufficiently good grip force estimation, while only motor encoder and the motor torques are used as observations.

Related Concept Videos
 01:30
Machines: Problem Solving II
 01:29
Cable: Problem Solving
 01:24
Cable Subjected to a Distributed Load
 01:22
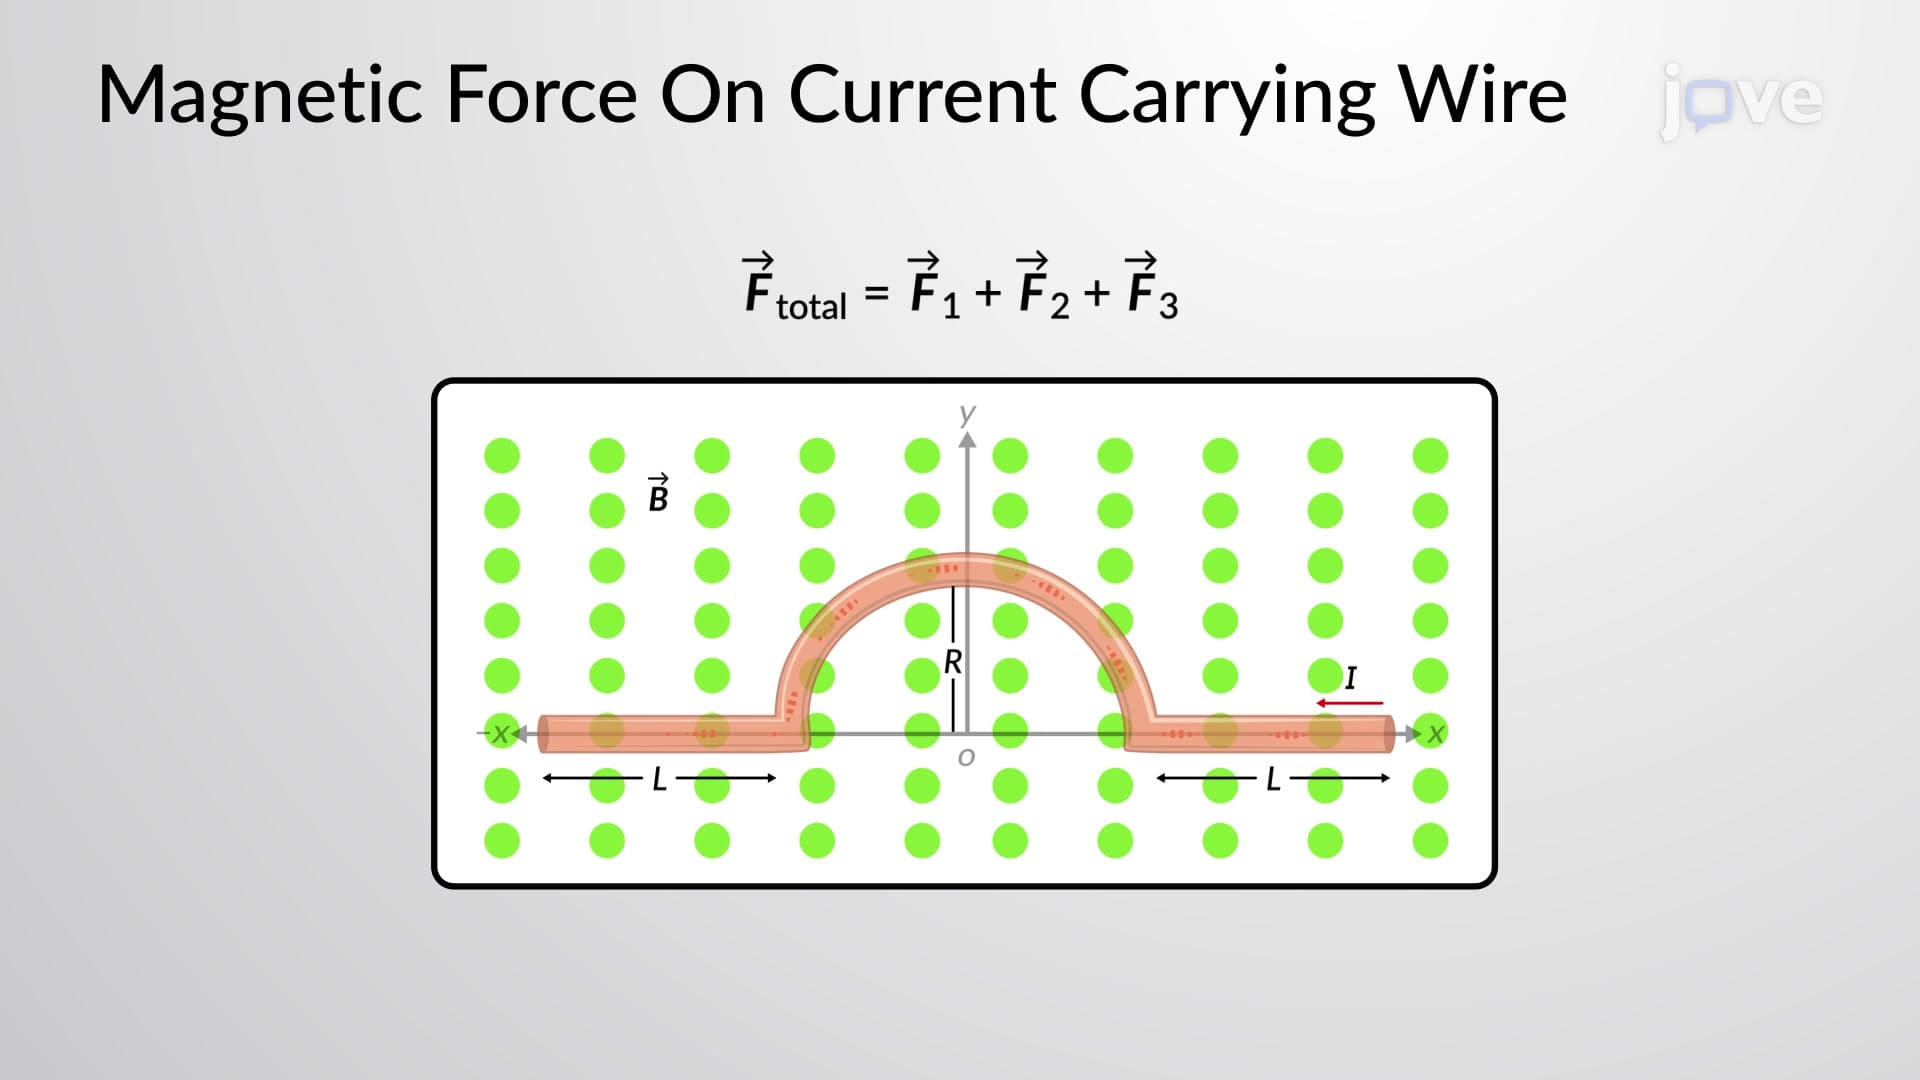
Magnetic Force On Current-Carrying Wires: Example
 01:13
Cable Subjected to Its Own Weight
A generalized loading function is employed to analyze a cable subjected to its own weight. This function considers the force acting along the cable's arc length rather than its projected length, providing a more accurate...