Related Experiment Video
Updated: Oct 26, 2025

Experimental Investigation of the Flow Structure over a Delta Wing Via Flow Visualization Methods
Published on: April 23, 2018
State-space aerodynamic model reveals high force control authority and predictability in flapping flight
1Mechanical Engineering Department, The Pennsylvania State University, University Park, PA 16801, USA.

Abstract:
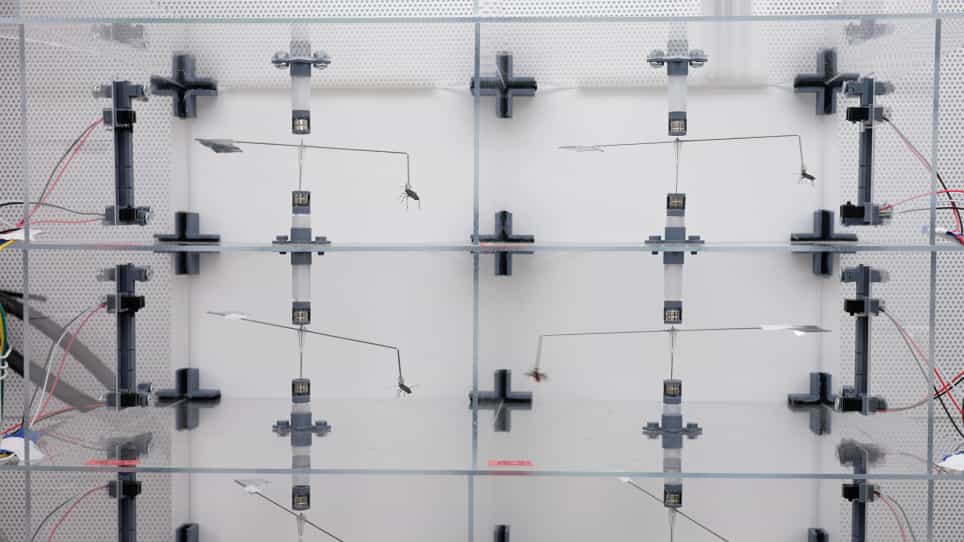
Flying animals resort to fast, large-degree-of-freedom motion of flapping wings, a key feature that distinguishes them from rotary or fixed-winged robotic fliers with limited motion of aerodynamic surfaces. However, flapping-wing aerodynamics are characterized by highly unsteady and three-dimensional flows difficult to model or control, and accurate aerodynamic force predictions often rely on expensive computational or experimental methods. Here, we developed a computationally efficient and data-driven state-space model to dynamically map wing kinematics to aerodynamic forces/moments. This model was trained and tested with a total of 548 different flapping-wing motions and surpassed the accuracy and generality of the existing quasi-steady models. This model used 12 states to capture the unsteady and nonlinear fluid effects pertinent to force generation without explicit information of fluid flows. We also provided a comprehensive assessment of the control authority of key wing kinematic variables and found that instantaneous aerodynamic forces/moments were largely predictable by the wing motion history within a half-stroke cycle. Furthermore, the angle of attack, normal acceleration and pitching motion had the strongest effects on the aerodynamic force/moment generation. Our results show that flapping flight inherently offers high force control authority and predictability, which can be key to developing agile and stable aerial fliers.
Related Concept Videos
 01:23
Lift
 01:23
Plane Potential Flows
Uniform...
 01:04
Hydrostatic Pressure Force on a Plane Surface
 01:30
Typical Model Studies
 01:26
General External Flow Characteristics
 01:18
Boundary Layer Characteristics