Related Experiment Video
Updated: Oct 25, 2025


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Control System Design of an Underactuated Dynamic Body Weight Support System Using Its Stability
Grzegorz Gembalczyk1, Piotr Gierlak2, Slawomir Duda1
1Department of Theoretical and Applied Mechanics, Faculty of Mechanical Engineering, Silesian University of Technology, Akademicka 2A, 44-100 Gliwice, Poland.

Abstract:
This paper discusses the stability of systems controlling patient body weight support systems which are used in gait re-education. These devices belong to the class of underactuated mechanical systems. This is due to the application of elastic shock-absorbing connections between the active part of the system and the passive part which impacts the patient. The model takes into account properties of the system, such as inertia, attenuation and susceptibility to the elements. Stability is an essential property of the system due to human-device interaction. In order to demonstrate stability, Lyapunov's theory of stability, which is based on the model of system dynamics, was applied. The stability of the control system based on a model that requires knowledge of the structure and parameters of the equations of motion was demonstrated. Due to inaccuracies in the modeling of the rope (one of the basic elements of the device), an adaptive control system was introduced and its stability was also proved. The authors conducted simulation and experimental tests that illustrate the functionality of the analyzed control systems.

Related Concept Videos
 01:14
Stability of structures
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
Rigid Body Equilibrium Problems - I
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:04
Applications of Stress
The...
 01:28
Stability
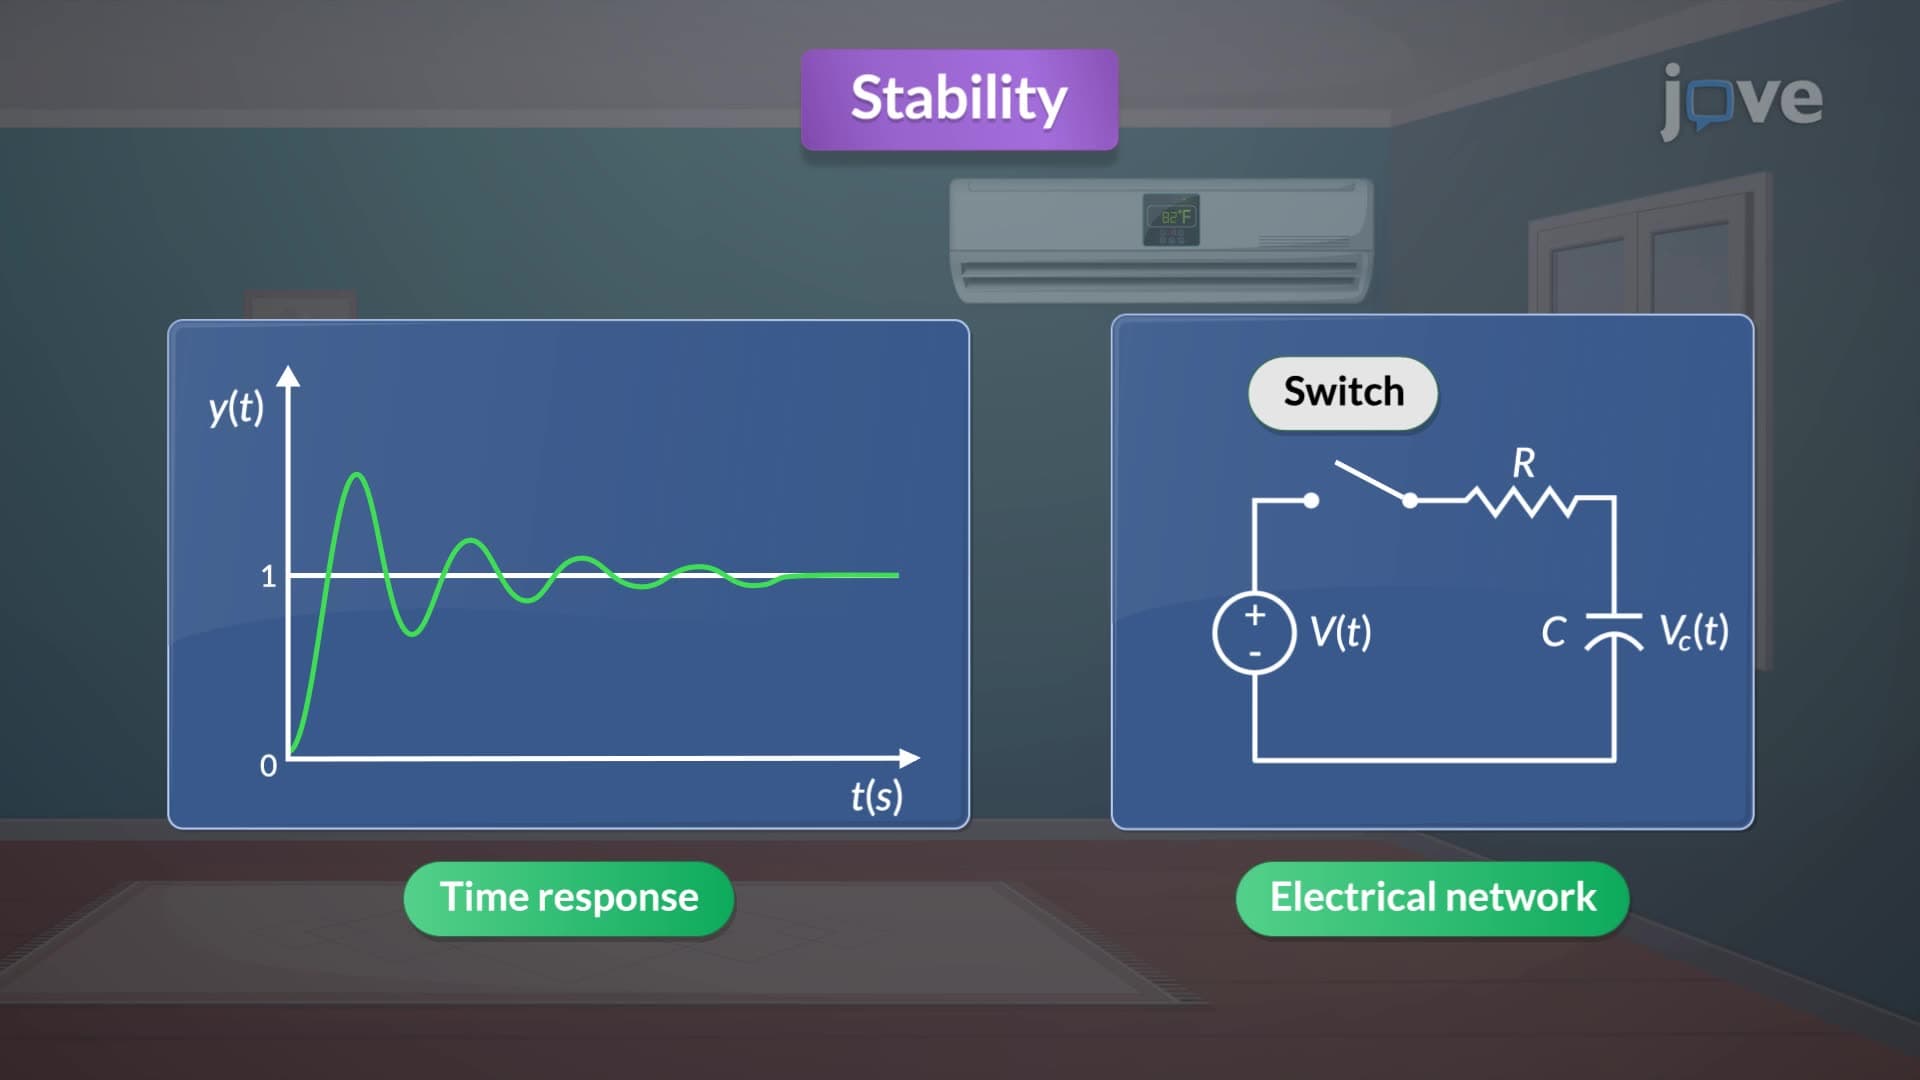
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...