Passivity-based coupling control for underactuated three-dimensional overhead cranes
Related Experiment Video
Updated: Oct 25, 2025

Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Shengzeng Zhang1, Haiyue Zhu2, Xiongxiong He3
1State Key Laboratory of Industrial Control Technology, Institute of Cyber-Systems and Control, Zhejiang University, Hangzhou 310027, China; Adaptive Robotics and Mechatronics Group, Singapore Institute of Manufacturing Technology, A*STAR, 138634, Singapore.

Abstract:
This paper develops a novel Lyapunov function candidate for control of the three-dimensional (3-D) overhead crane, which yields a nonlinear controller to inject active damping. Different from the existing passivity-based controls that employ either the angular displacement or its integral as passive elements, the proposed controller incorporates both of them in a new coupled-dissipation signal, thus significantly enhancing the closed-loop passivity. Owing to the improved passivity, the proposed controller ensures the effective suppression of payload oscillations and robustness. Moreover, the control design is extended with the hyperbolic tangent function to prevent overdriving the trolley. The asymptotic stability is guaranteed by LaSalle's invariance principle. The transit performance of the closed-loop system, including robustness, is validated by numerical simulations.
More Related Videos


Related Concept Videos
 01:24
Frames: Problem Solving I
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:30
Machines: Problem Solving II
 01:30
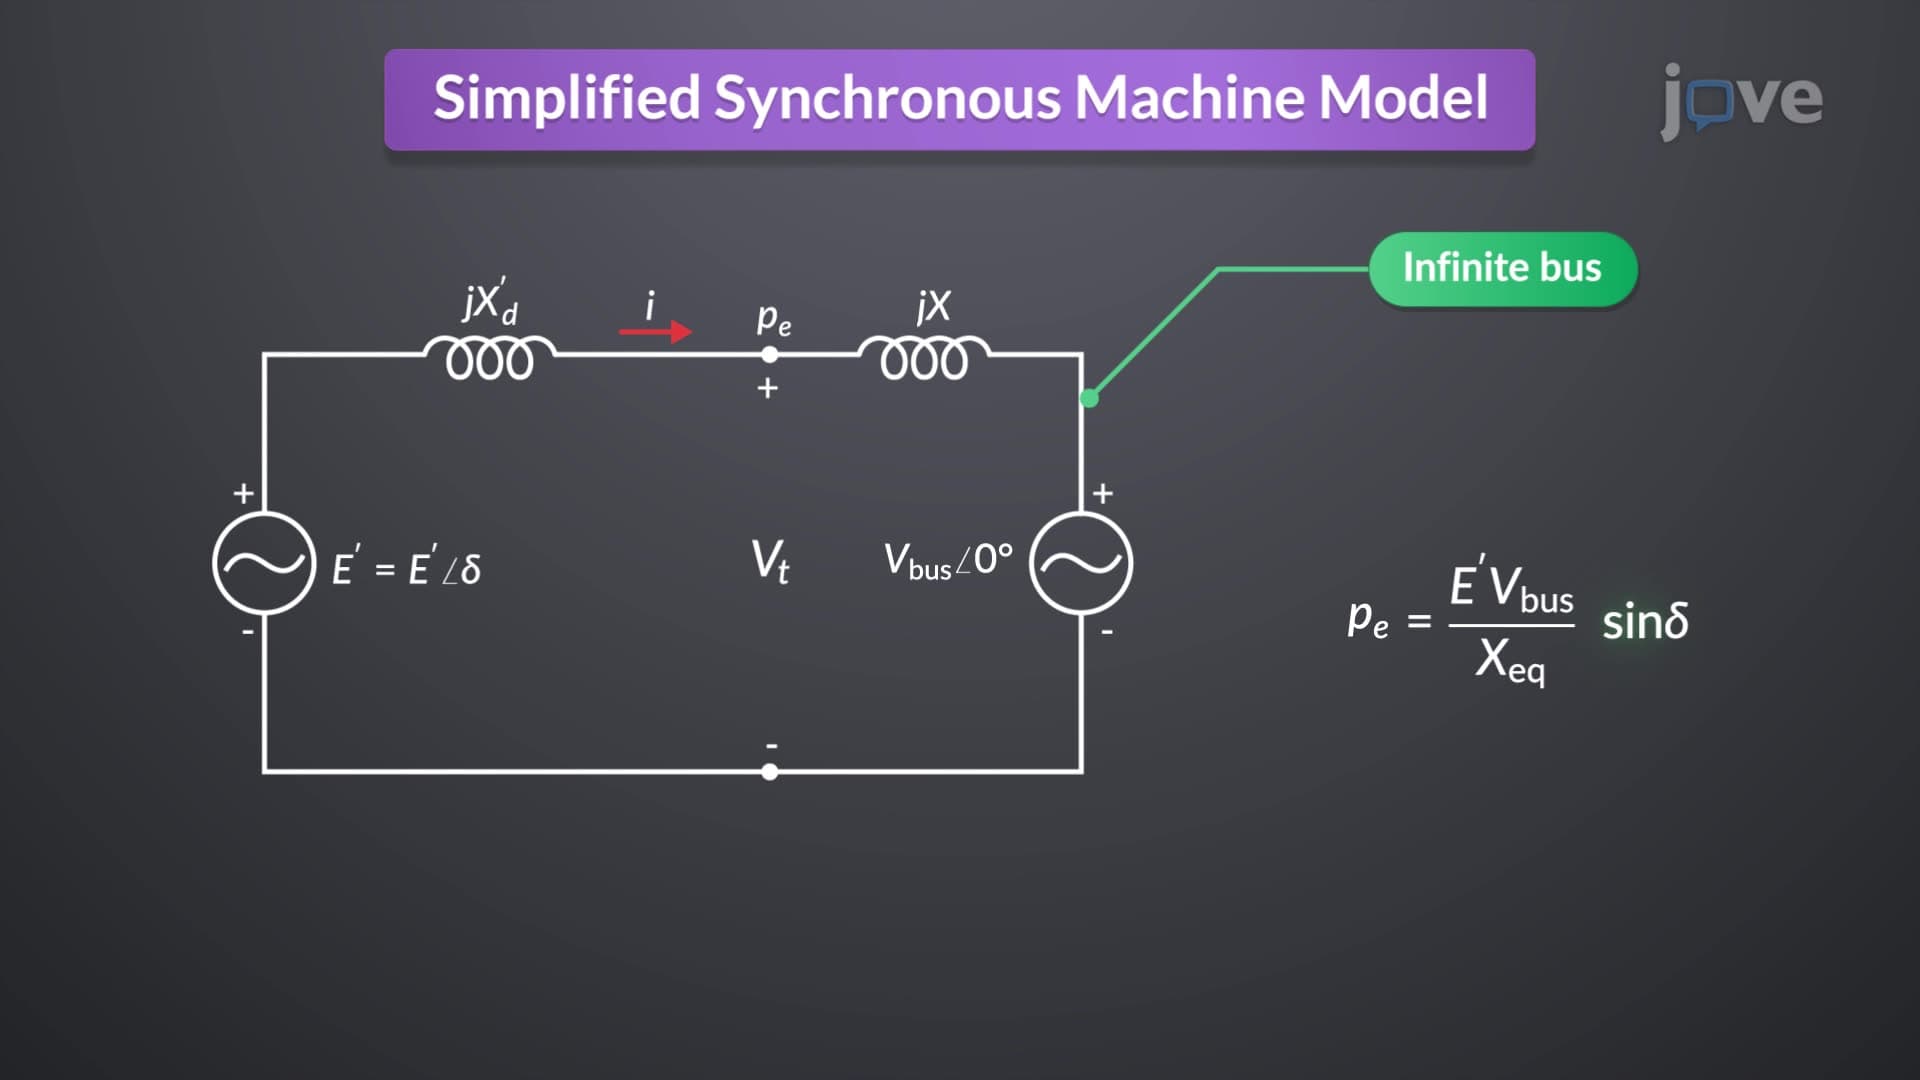
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...