Asymptotic Tracking Control for Uncertain MIMO Systems: A Biologically Inspired ESN Approach
Related Experiment Video
Updated: Oct 24, 2025

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020

Abstract:
In this study, a biologically inspired echo state network (ESN)-based method is established for the asymptotic tracking control of a class of uncertain multi-input multi-output (MIMO) systems. By mimicking the characters of real biological systems, a diversified multiclustered echo state network (DMCESN) is proposed in this work and then it is applied to deal with the modeling uncertainties and coupling nonlinearities in the control systems. Different from the most existing neural network (NN)-based control methods that only ensure the uniform ultimate boundedness result, the proposed method can allow the tracking error to achieve asymptotic convergence through rigorous theoretical analysis. The effectiveness of the proposed method is also confirmed by numerical simulation by comparing with multilayer feedforward network-based control scheme and traditional ESN-based control, admitting better tracking performance of the proposed control.

Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:21
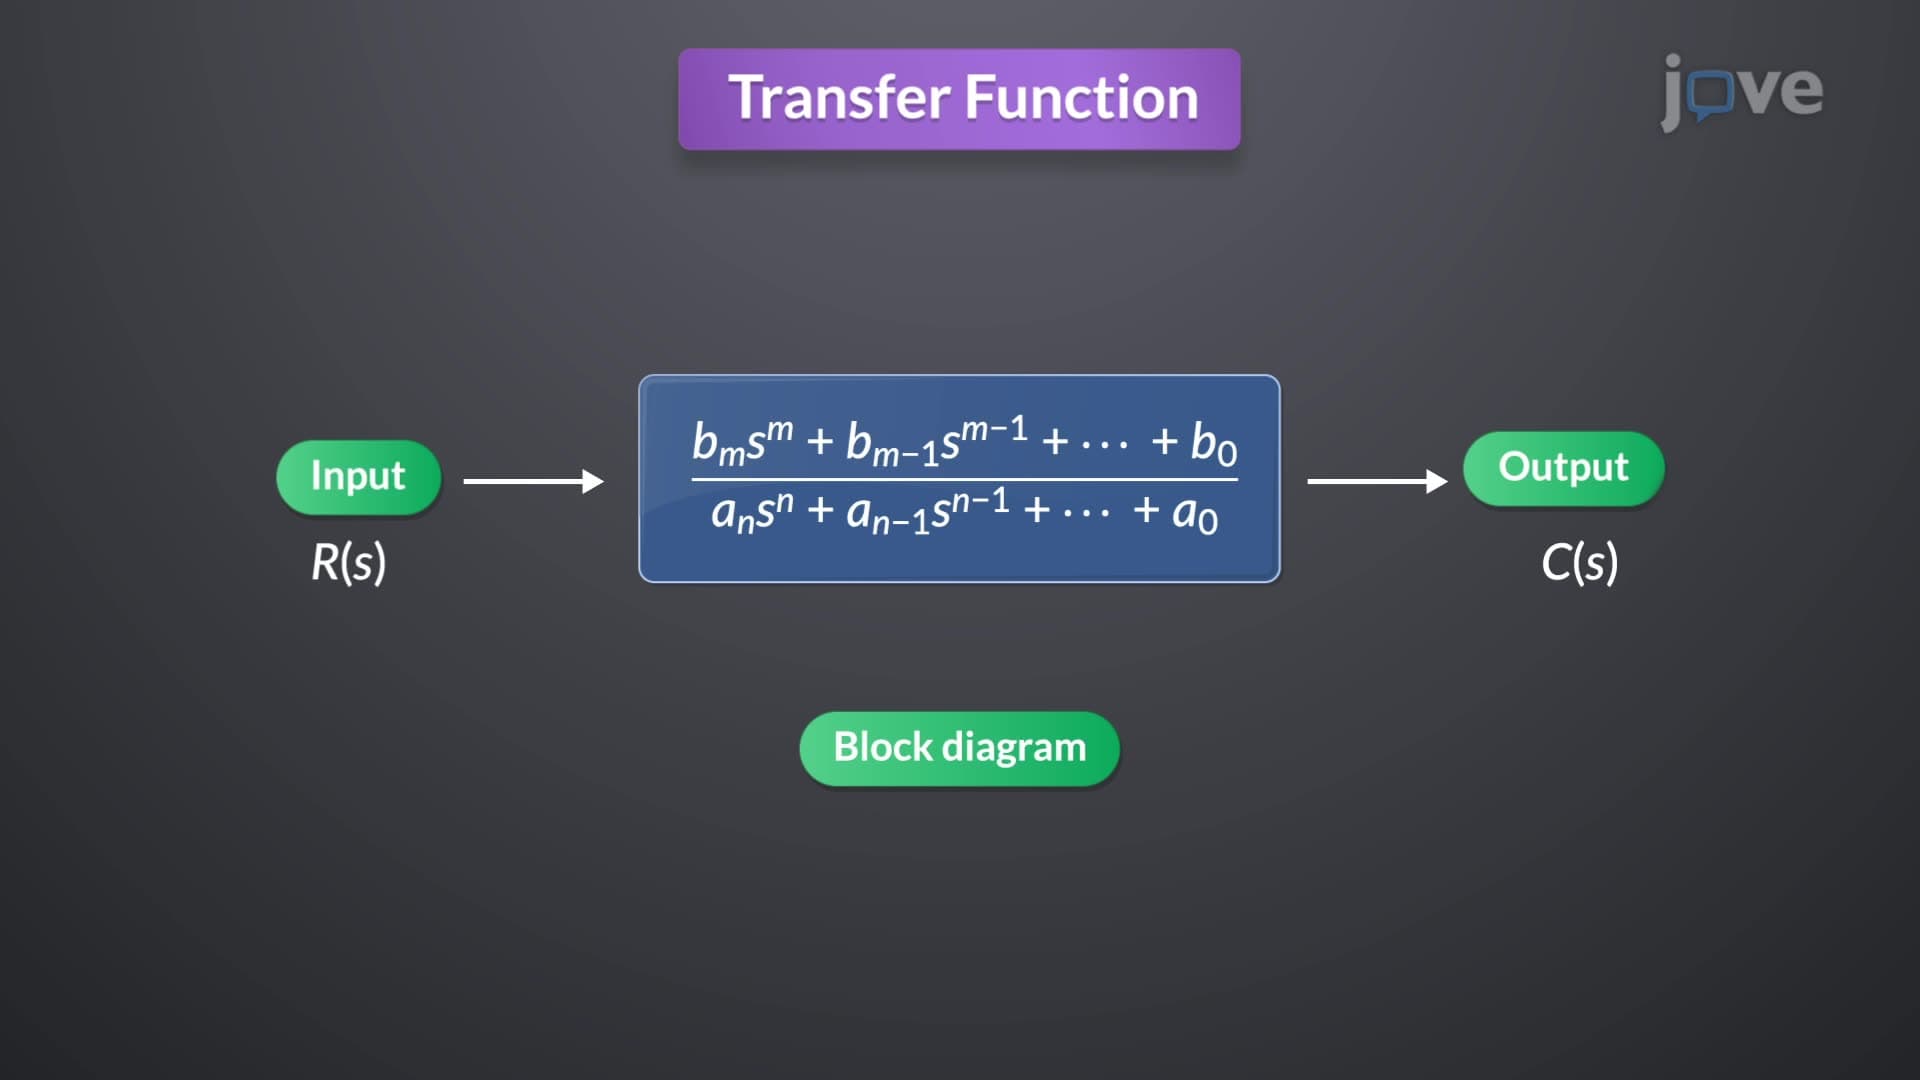
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:10
Propagation of Uncertainty from Systematic Error
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...