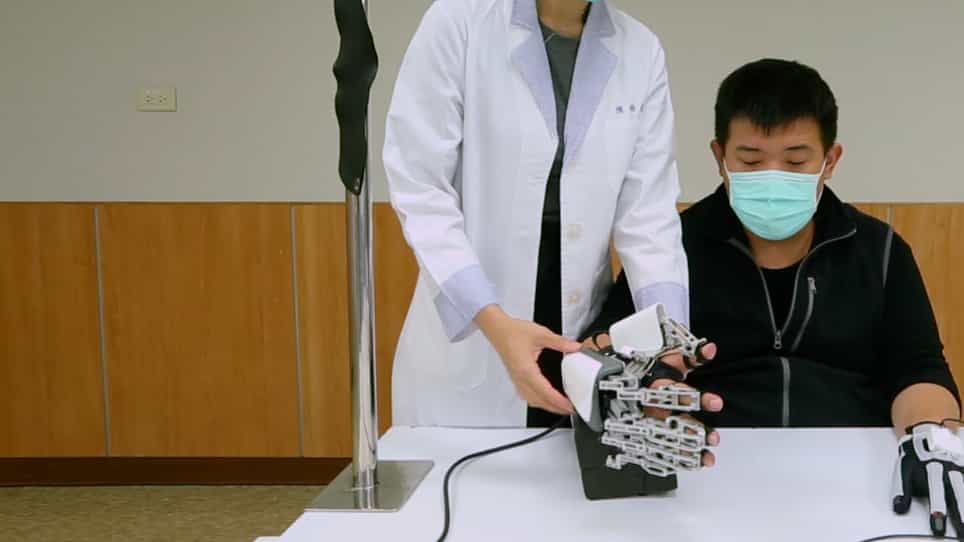
Related Experiment Video
Updated: Oct 24, 2025

Author Spotlight: Enhancing Grasping Abilities for Hemiplegic Patients with Flexible Robotic Limbs
Published on: October 27, 2023
Development and feasibility of a soft pneumatic-robotic glove to assist impaired hand function in quadriplegia
Zahra Jiryaei1, Amin Asgharzadeh Alvar2, Monireh Ahmadi Bani3
1Department of Orthotics and Prosthetics, School of Rehabilitation, Iran University of Medical Science, Tehran, Iran.

Abstract:
One of the common disorders in people with quadriplegia is having a weak grip strength that can affect activities of daily living (ADL). This study presents the design of a soft robotic glove via pneumatic actuators and feasibility according to a range of motion (ROM) of proximal interphalangeal (PIP) joint and user friendly. The soft robotic glove includes a neoprene cockup, two pumps, a controller that adjusts the pressure of the pumps, two-direction parts, and two silicone tubes placed on an index and middle fingers. A total of seven subjects (2healthy, 5quadriplegia patients) participated in this project. Performance of the device was verified through assessment in healthy participants first and then spinal cord injury (SCI) participants. The device evaluated the range of motion (ROM) of a proximal interphalangeal (PIP) joint. Then, subjects completed a satisfaction questionnaire. Results showed the ROM of the PIP joint (p value = 0.042) increased by using the robotic glove. The average score of the satisfaction questionnaire was 4.24 which was beyond the desirable threshold. In conclusion, the glove obtained ROM requirements to the grip usual objects and underlined the potential for assisting SCI participants in ADLs. Providing motion in all fingers should be investigated and developed in the future.