Related Experiment Video
Updated: Oct 23, 2025

Chemotactic Response of Marine Micro-Organisms to Micro-Scale Nutrient Layers
Published on: May 28, 2007
Control and controllability of microswimmers by a shearing flow
Clément Moreau1, Kenta Ishimoto1, Eamonn A Gaffney2
1Research Institute for Mathematical Sciences, Kyoto University, Kyoto, 606-8502, Japan.

Abstract:
With the continuing rapid development of artificial microrobots and active particles, questions of microswimmer guidance and control are becoming ever more relevant and prevalent. In both the applications and theoretical study of such microscale swimmers, control is often mediated by an engineered property of the swimmer, such as in the case of magnetically propelled microrobots. In this work, we will consider a modality of control that is applicable in more generality, effecting guidance via modulation of a background fluid flow. Here, considering a model swimmer in a commonplace flow and simple geometry, we analyse and subsequently establish the efficacy of flow-mediated microswimmer positional control, later touching upon a question of optimal control. Moving beyond idealized notions of controllability and towards considerations of practical utility, we then evaluate the robustness of this control modality to sources of variation that may be present in applications, examining in particular the effects of measurement inaccuracy and rotational noise. This exploration gives rise to a number of cautionary observations, which, overall, demonstrate the need for the careful assessment of both policy and behavioural robustness when designing control schemes for use in practice.
Related Concept Videos
 01:30
Typical Model Studies
 01:16
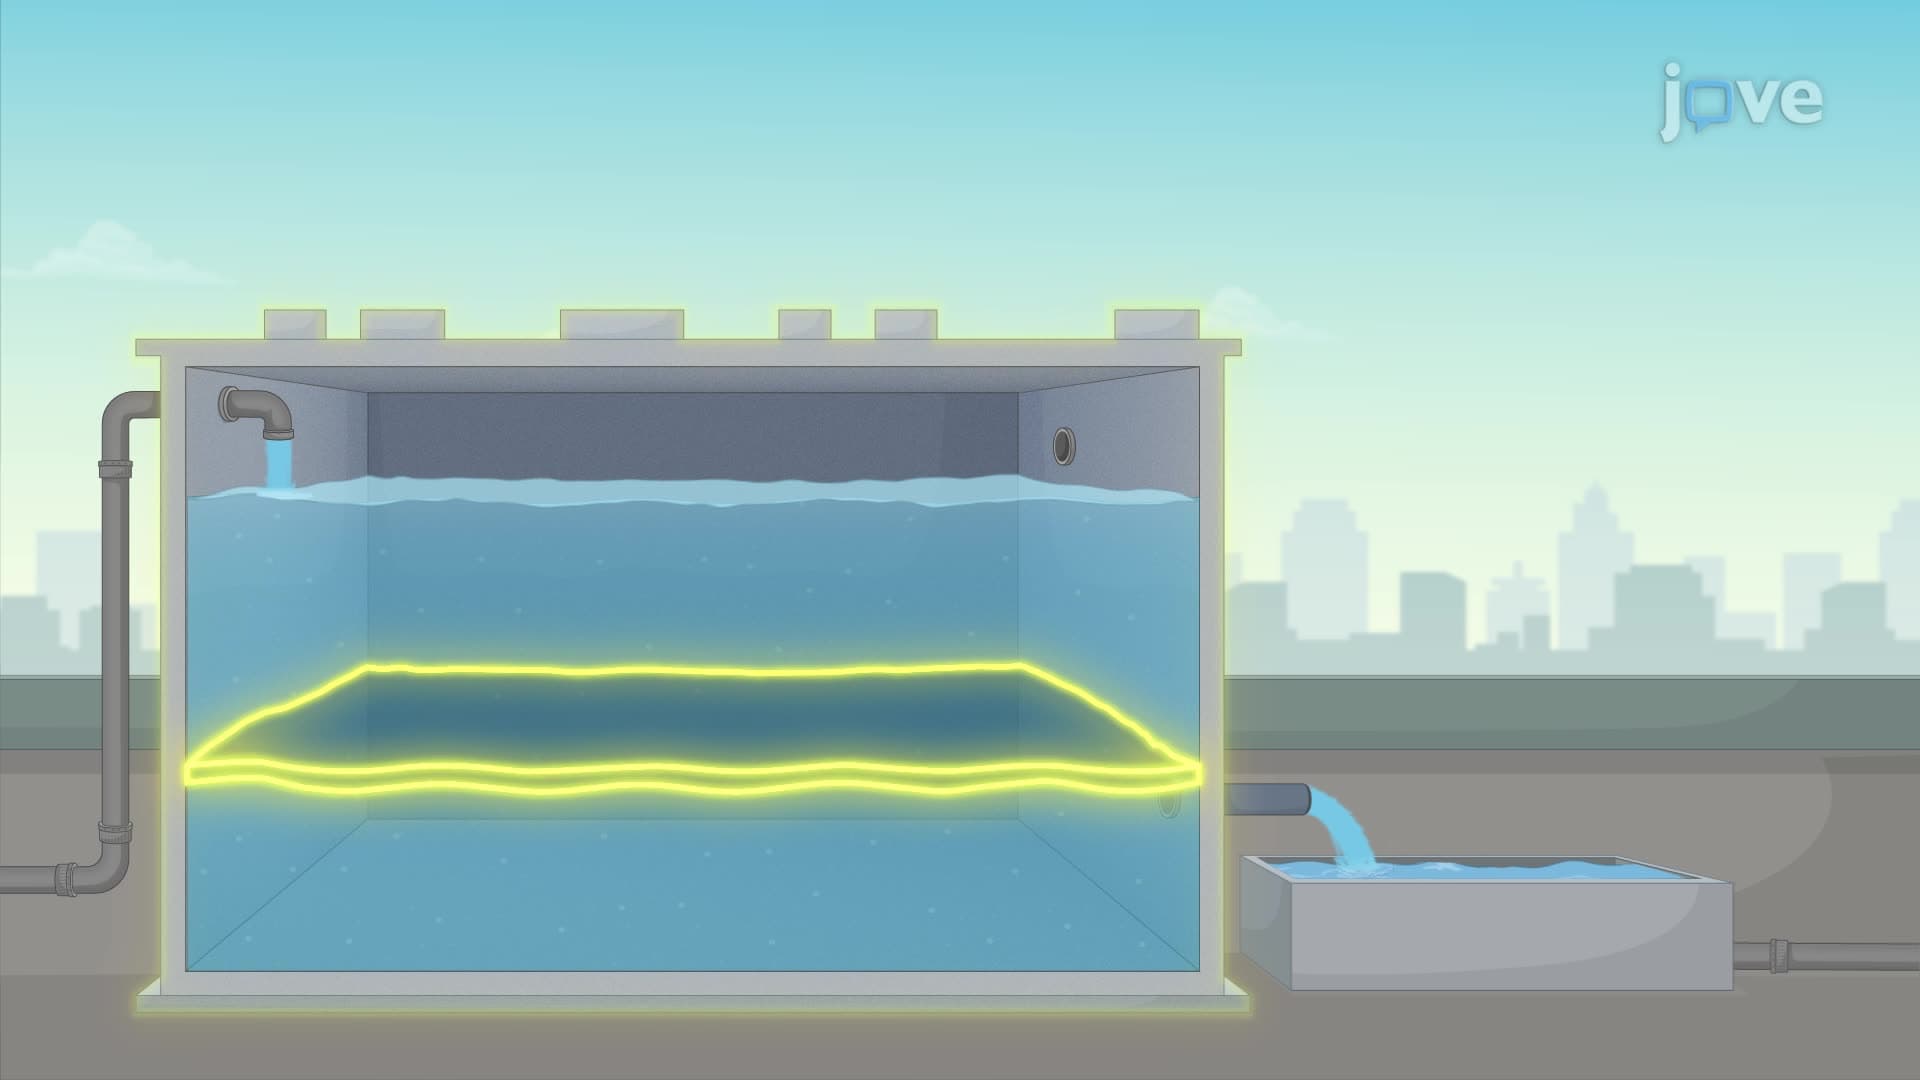
Control Volume and System Representations
The control volume approach considers a stationary region in space through which fluid flows. This region is bounded by a control surface. For instance, in the case of water...
 01:17
Steady, Laminar Flow Between Parallel Plates
 01:29
Gradually Varying Flow