Related Experiment Video
Updated: Oct 22, 2025
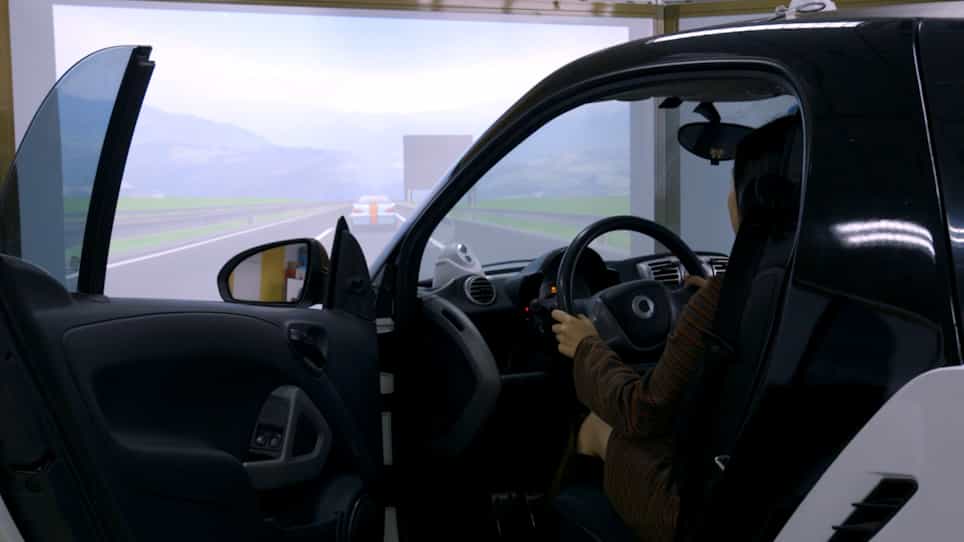
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Modeling and prediction of driving performance measures based on multi-output convolutional Gaussian process
Pranaykumar Kasarla1, Chao Wang1, Timothy L Brown2
1Department of Industrial and Systems Engineering, The University of Iowa, Iowa City, IA 52242, United States.

Abstract:
Driving performance measures (DPMs) are important indices for driving and personal safety in vehicle operation. The DPMs are collected under various controlled driving conditions to demonstrate different driving behaviors so that mitigating technology interventions can be studied and designed. However, significant costs are involved in the DPM acquisition, and there are a very limited number of controlled driving condition data. Thus, the modeling and prediction of the DPMs under unobserved driving conditions are critical, and many methods have been developed. However, existing literature in this area suffer a common limitation: The interactions among different DPMs are not fully considered (each DPM is modeled individually), although the existence of such interactions is widely reported. This paper proposes a novel DPM modeling and prediction method, i.e., multi-output convolutional Gaussian process (MCGP), that incorporates the interactions among different DPMs. The method features the modeling flexibility for different DPMs and the interpretable modeling structure for integrating the DPM interactions. The method is compared with three benchmark methods on the DPM data set under four different settings, and the results demonstrate the superiorities of the method. Discussions and interpretations of the results are also provided.
Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:07
End Point Prediction: Gran Plot
For potentiometric titration, the Gran plot is created by plotting...
 01:14
Multicompartment Models: Overview
These models offer a more comprehensive representation of drug behavior in the body than one-compartment models. They accommodate the complexity of drug distribution,...
 01:20
Calibration Curves: Linear Least Squares
For data that follow a straight line, the standard method for fitting is the linear...
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:25
Multiple Regression
Farmers can use multiple regression to determine the crop yield based on more than one factor, such as water availability, fertilizer, soil properties, etc. Here, the crop yield is the response or dependent variable as it depends on the other independent variables. The analysis requires the construction of a scatter plot...