Related Experiment Video
Updated: Oct 22, 2025


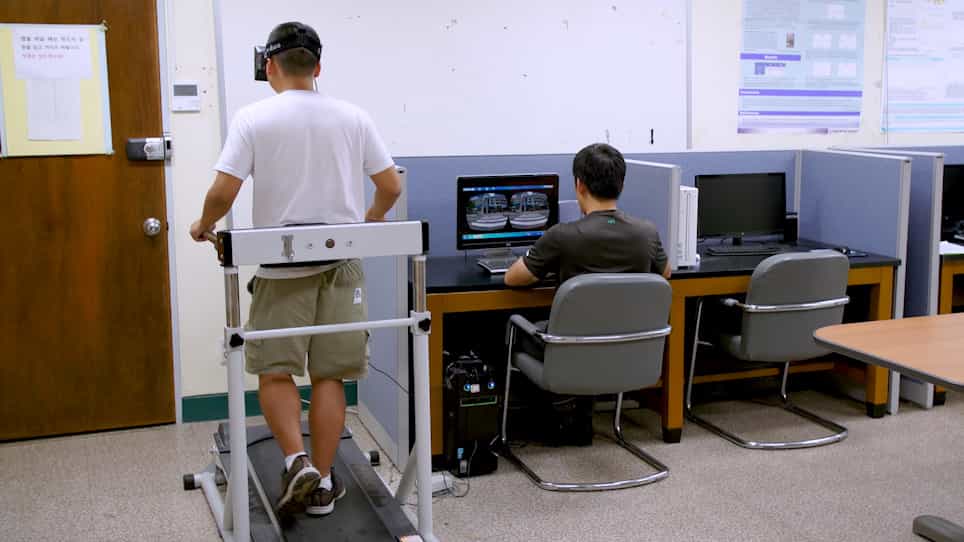
Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
Modeling pedestrian behavior in pedestrian-vehicle near misses: A continuous Gaussian Process Inverse Reinforcement
Payam Nasernejad1, Tarek Sayed1, Rushdi Alsaleh1
1Department of Civil Engineering, University of British Columbia, Vancouver, Canada.

Abstract:
Using simulation models to conduct safety assessments can have several advantages as it enables the evaluation of the safety of various design and traffic management options before actually making changes. However, limited studies have developed microsimulation models for the safety evaluation of active road users such as pedestrians. This can be attributed to the limited ability of simulation models to capture the heterogeneity in pedestrian behavior and their complex collision avoidance mechanisms. Therefore, the objective of this study is to develop an agent-based framework to realistically model pedestrian behavior in near misses and to improve the understanding of pedestrian evasive action mechanisms in interactions with vehicles. Pedestrian-vehicle conflicts are modeled using the Markov Decision Process (MDP) framework. A continuous Gaussian Process Inverse Reinforcement Learning (GP-IRL) approach is implemented to retrieve pedestrians' reward functions and infer their collision avoidance mechanisms in conflict situations. Video data from a congested intersection in Shanghai, China is used as a case study. Trajectories of pedestrians and vehicles involved in traffic conflicts were extracted with computer vision algorithms. A Deep Reinforcement Learning (DRL) model is used to estimate optimal pedestrian policies in traffic conflicts. Results show that the developed model predicted pedestrian trajectories and their evasive action mechanisms (i.e., swerving maneuver and speed changing) in conflict situations with high accuracy. As well, the model provided predictions of the post encroachment time (PET) conflict indicator that strongly correlated with the corresponding values of the field-measured conflicts. This study is a crucial step in developing a safety-oriented microsimulation tool for pedestrians in mixed traffic conditions.

Related Concept Videos
 01:12
Observational Learning
 01:17
Rolling Resistance: Problem Solving
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:06
Model Approaches for Pharmacokinetic Data: Distributed Parameter Models
The distributed parameter models are specifically designed to account for variations and differences in some drug classes. This model is particularly useful for assessing regional concentrations of anticancer or...
 01:14
Steps in the Modeling Process
Attention is the first necessary component for observational learning. It involves focusing on what the model is doing and saying. For example, if you decide to take a drawing class to enhance your skills, you need to pay close attention to the instructor's words and hand movements. The characteristics of the model significantly...
 01:15
Elastic Collisions: Case Study