Related Experiment Video
Updated: Oct 22, 2025

Folding and Characterization of a Bio-responsive Robot from DNA Origami
Published on: December 3, 2015
Stretchable origami robotic arm with omnidirectional bending and twisting

Abstract:
Inspired by the embodied intelligence observed in octopus arms, we introduce magnetically controlled origami robotic arms based on Kresling patterns for multimodal deformations, including stretching, folding, omnidirectional bending, and twisting. The highly integrated motion of the robotic arms is attributed to inherent features of the reconfigurable Kresling unit, whose controllable bistable deploying/folding and omnidirectional bending are achieved through precise magnetic actuation. We investigate single- and multiple-unit robotic systems, the latter exhibiting higher biomimetic resemblance to octopus' arms. We start from the single Kresling unit to delineate the working mechanism of the magnetic actuation for deploying/folding and bending. The two-unit Kresling assembly demonstrates the basic integrated motion that combines omnidirectional bending with deploying. The four-unit Kresling assembly constitutes a robotic arm with a larger omnidirectional bending angle and stretchability. With the foundation of the basic integrated motion, scalability of Kresling assemblies is demonstrated through distributed magnetic actuation of double-digit number of units, which enables robotic arms with sophisticated motions, such as continuous stretching and contracting, reconfigurable bending, and multiaxis twisting. Such complex motions allow for functions mimicking octopus arms that grasp and manipulate objects. The Kresling robotic arm with noncontact actuation provides a distinctive mechanism for applications that require synergistic robotic motions for navigation, sensing, and interaction with objects in environments with limited or constrained access. Based on small-scale Kresling robotic arms, miniaturized medical devices, such as tubes and catheters, can be developed in conjunction with endoscopy, intubation, and catheterization procedures using functionalities of object manipulation and motion under remote control.

Related Concept Videos
 01:18
Unsymmetric Bending
 01:20
Bending and Torsional Moments
The reaction developed in a structural element when subjected to an external force causes the element to bend. When a structural element bends upwards, it creates compressive normal forces on the top and tensile normal forces on the bottom, resulting in a couple that determines the bending...
 01:15
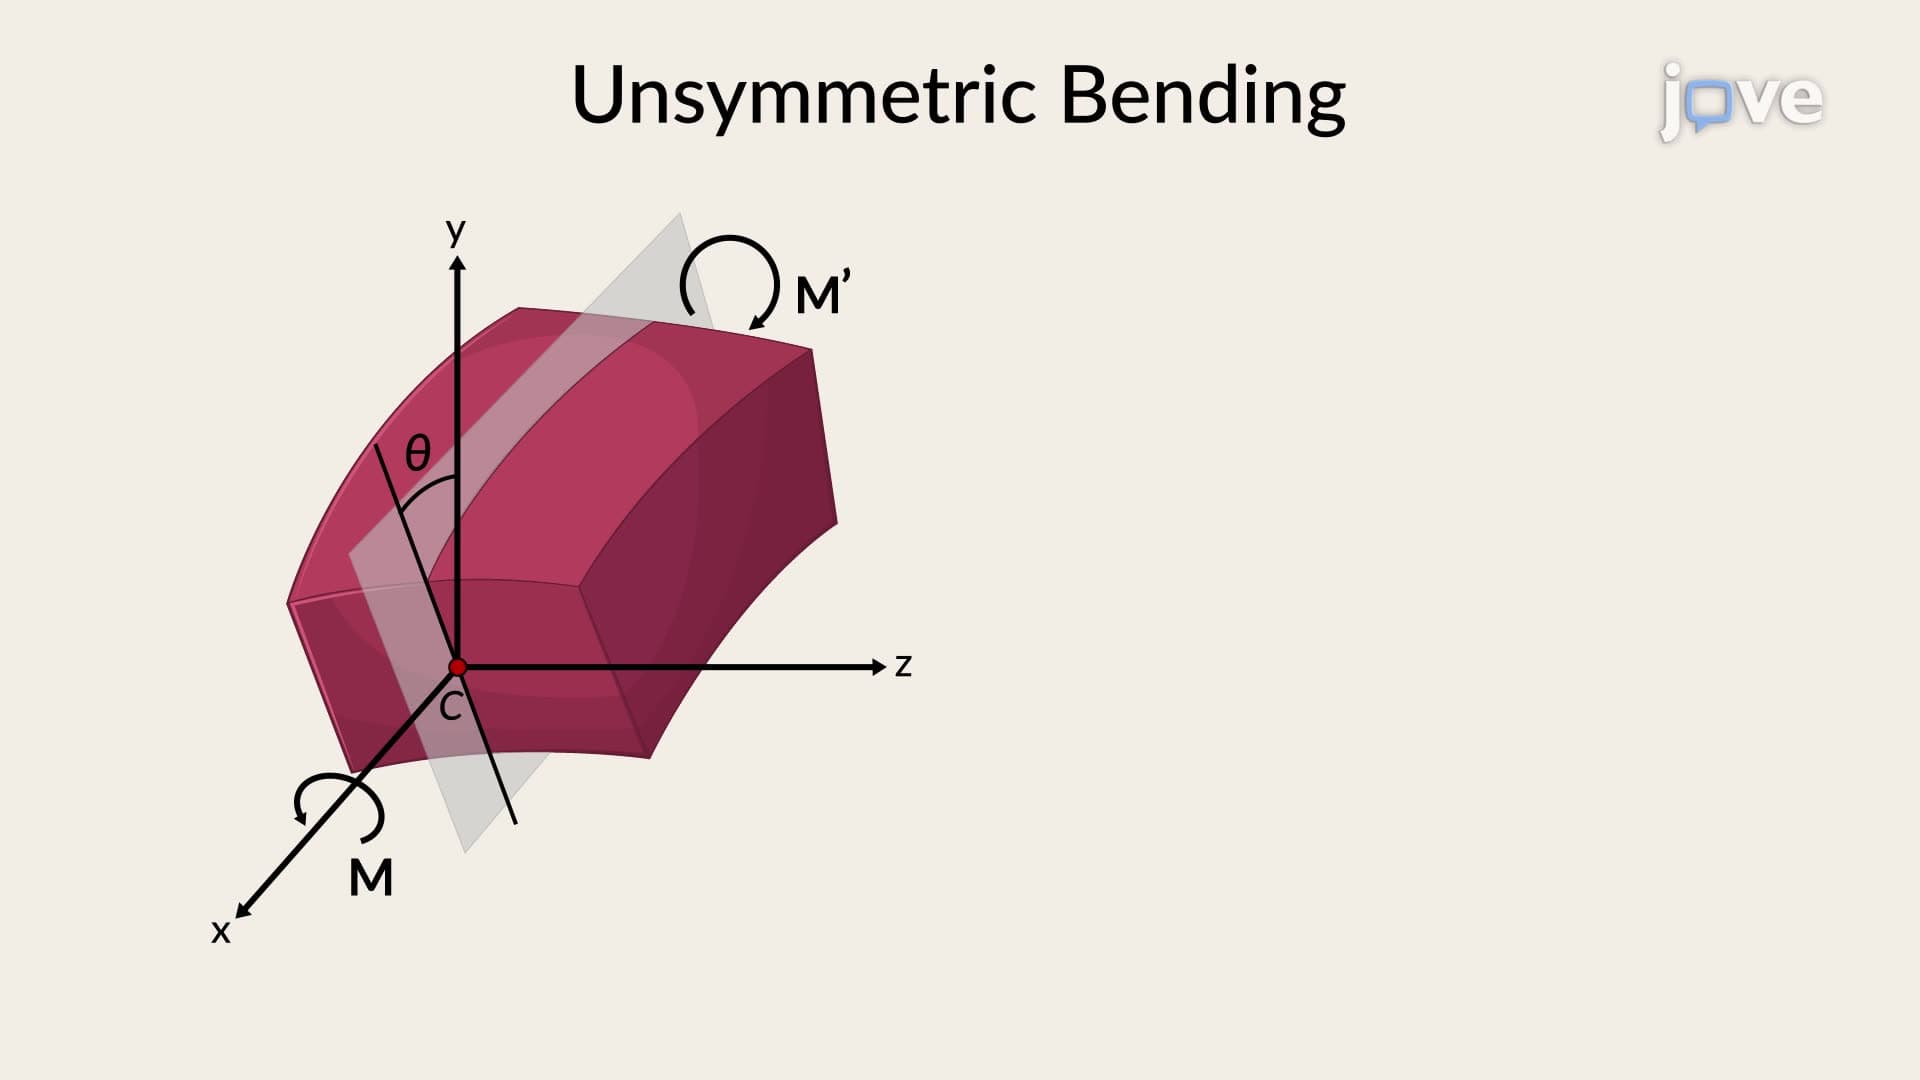
Unsymmetric Bending - Angle of Neutral Axis
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal...
 01:13
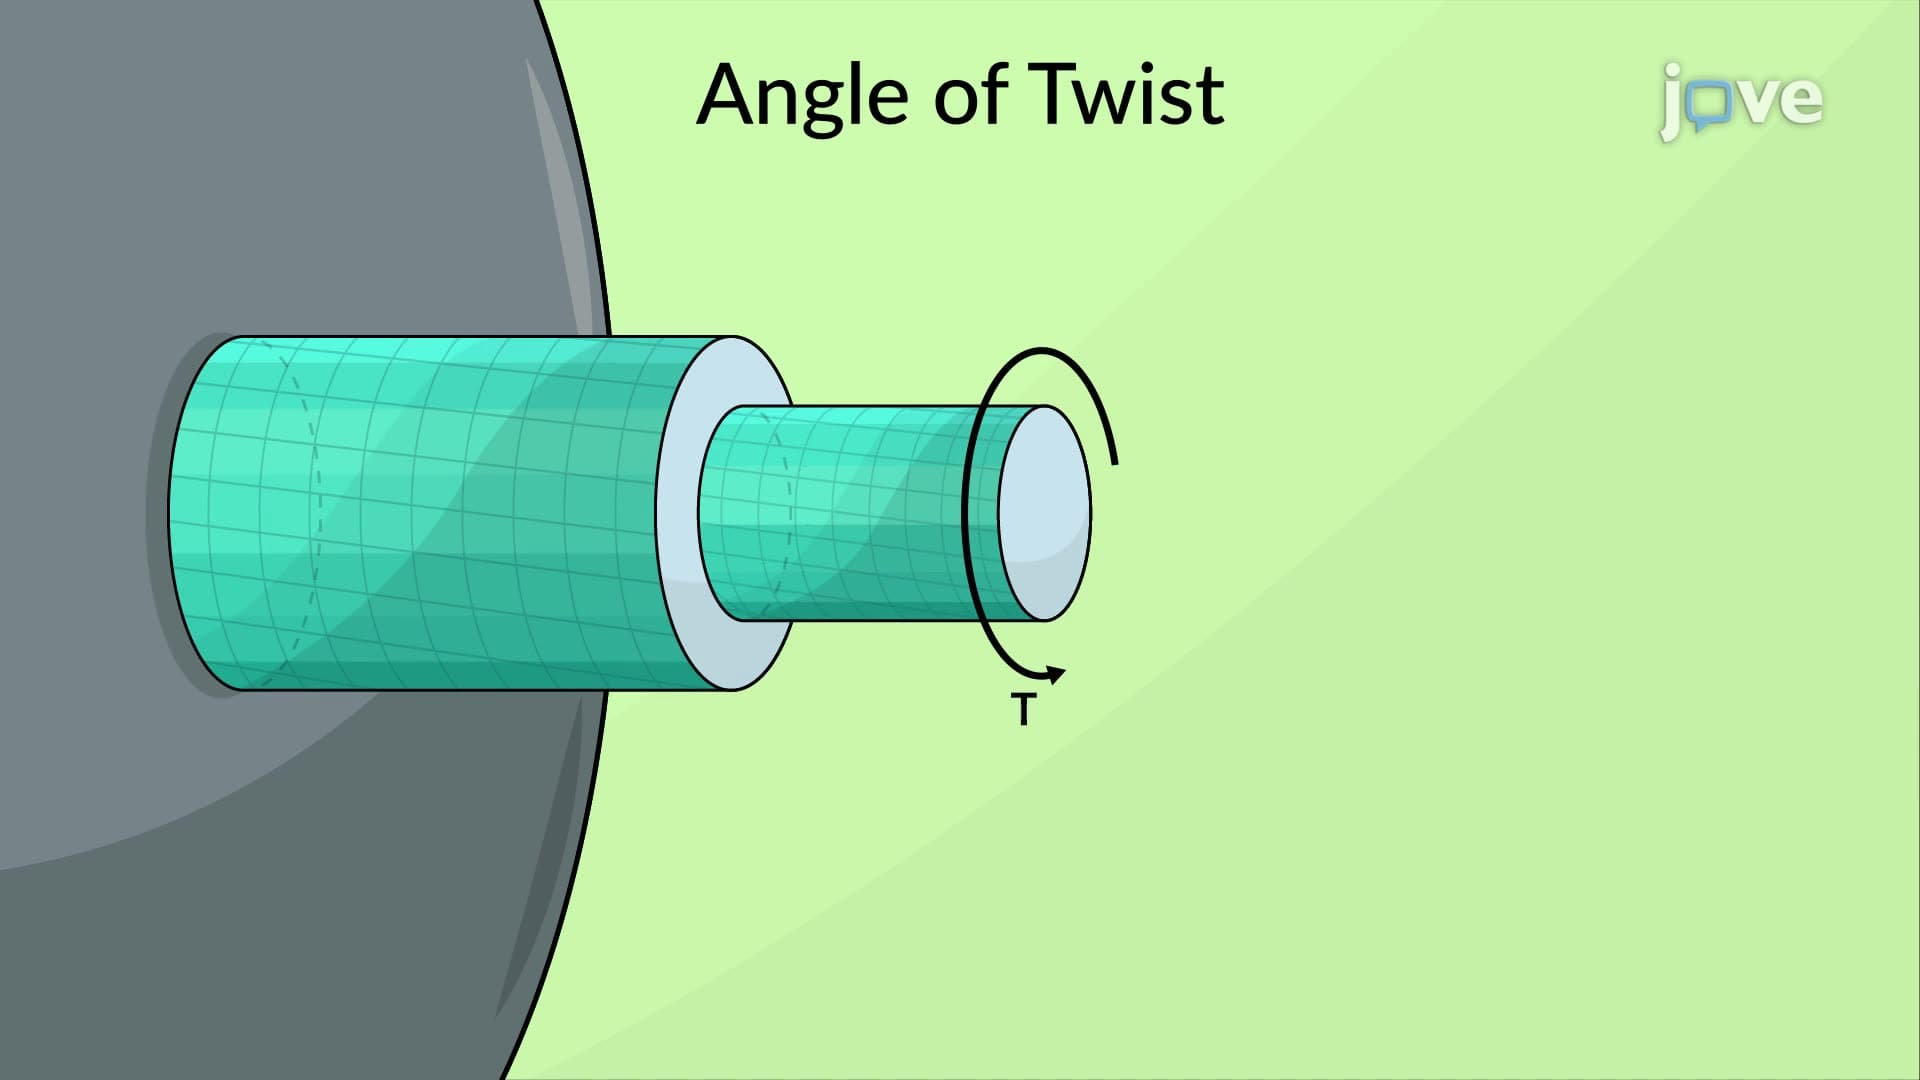
Angle of Twist - Elastic Range
 01:08
Bending of Members Made of Several Materials
Hooke's Law determines stress in each material, stating that stress is proportional to strain but varies due to each...
 01:09
Bending of Material: Problem Solving