Related Experiment Video
Updated: Oct 21, 2025
05:02

Using Unidirectional Rotations to Improve Vestibular System Asymmetry in Patients with Vestibular Dysfunction
Published on: August 30, 2019
7.4K
Shifting Gears Toward the 2021-2022 ERAS Application Cycle: Implications of a Single Away Rotation
Paige K Dekker1, Areeg A Abu El Hawa1, Kenneth L Fan2
1Georgetown University School of Medicine, Washington, D.C.
Plastic and Reconstructive Surgery. Global Open
|September 3, 2021

Abstract
No abstract available in PubMed .
Related Concept Videos
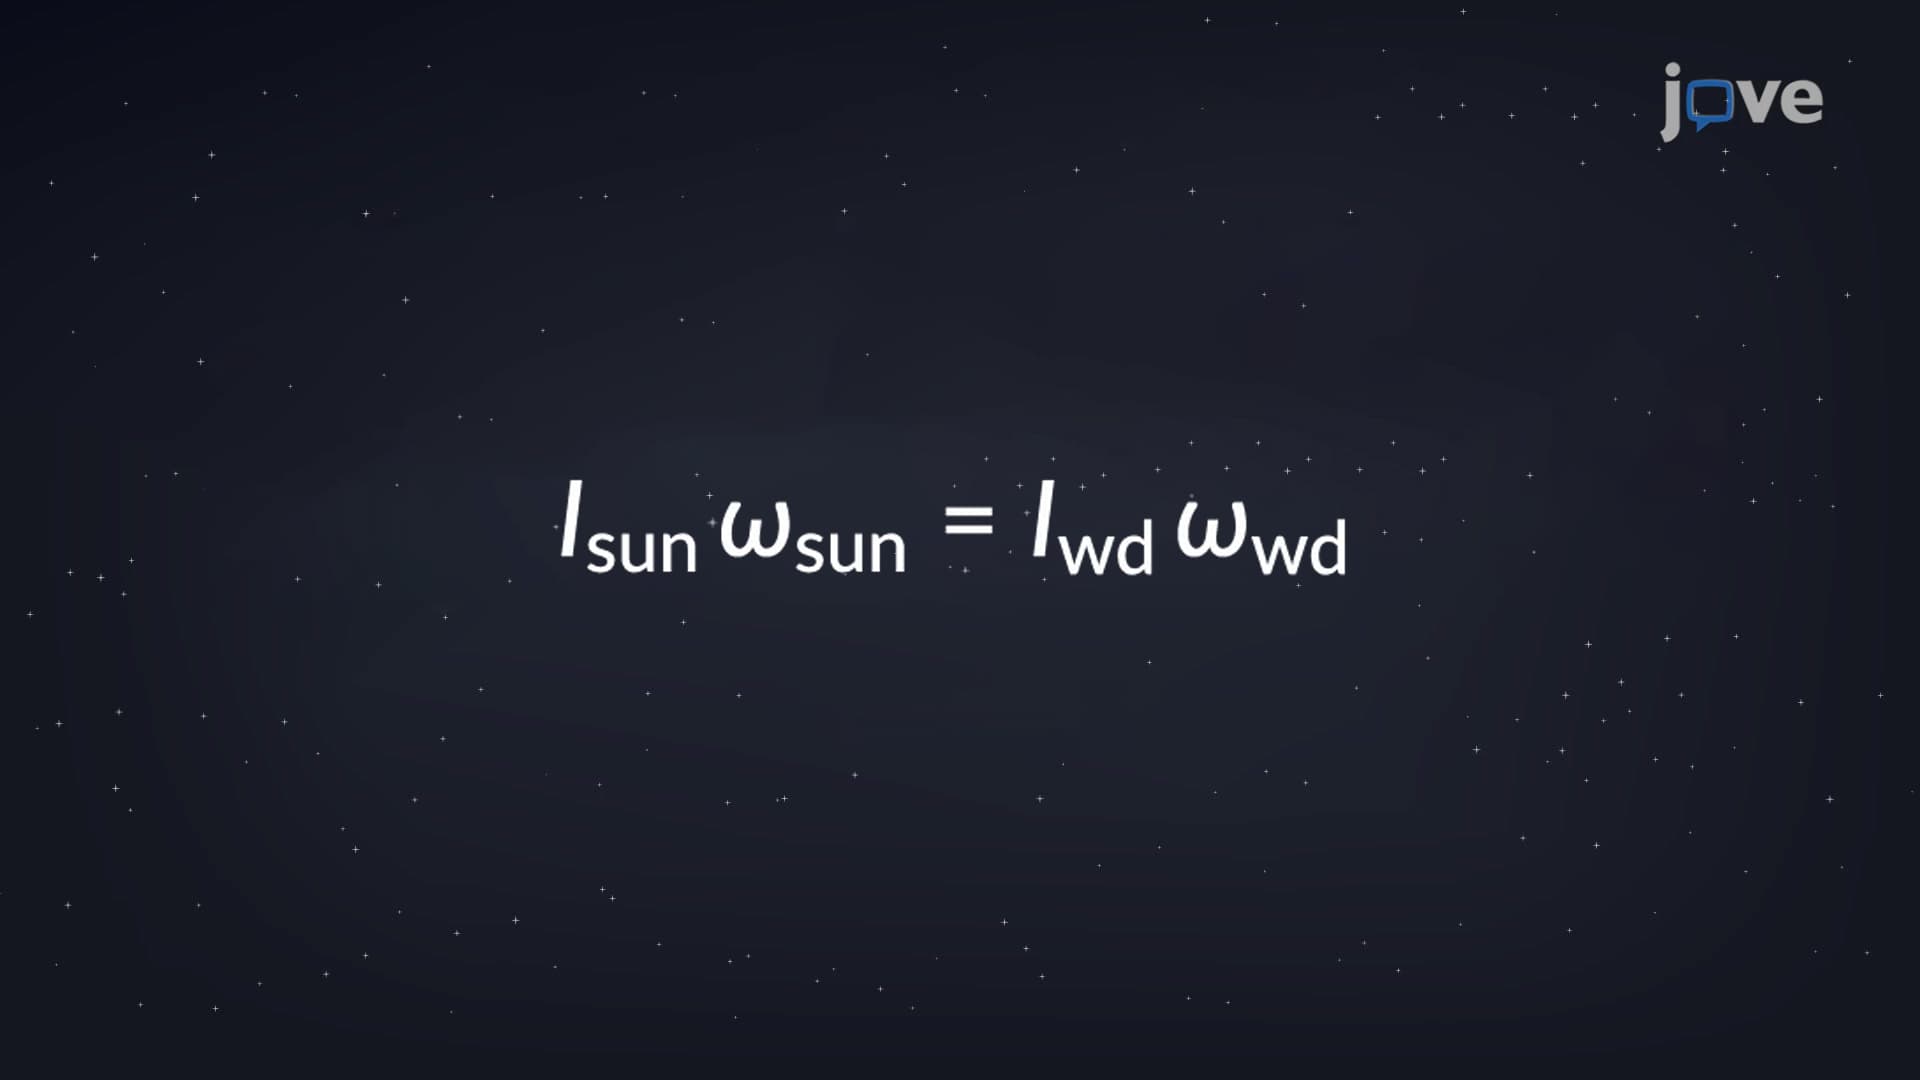 01:18
Conservation of Angular Momentum: Application
11.5K
A system's total angular momentum remains constant if the net external torque acting on the system is zero. Examples of such systems include a freely spinning bicycle tire that slows over time due to torque arising from friction, or the slowing of Earth's rotation over millions of years due to frictional forces exerted on tidal deformations. However in the absence of a net external torque, the angular momentum remains conserved. The conservation of angular momentum principle requires a...
11.5K
 01:26
Rotational Motion about a Fixed Axis
870
A rigid body's rotation around a fixed axis makes every point within it trace a circular path around a specific line or point. The term given to this type of spinning is defined by the angular position, symbolized by the angle θ. This angle is gauged from a static reference line to the revolving object. From this angular position, any variation is referred to as angular displacement, denoted by dθ. The extent of this displacement can be calculated in degrees, radians, or...
870
 01:11
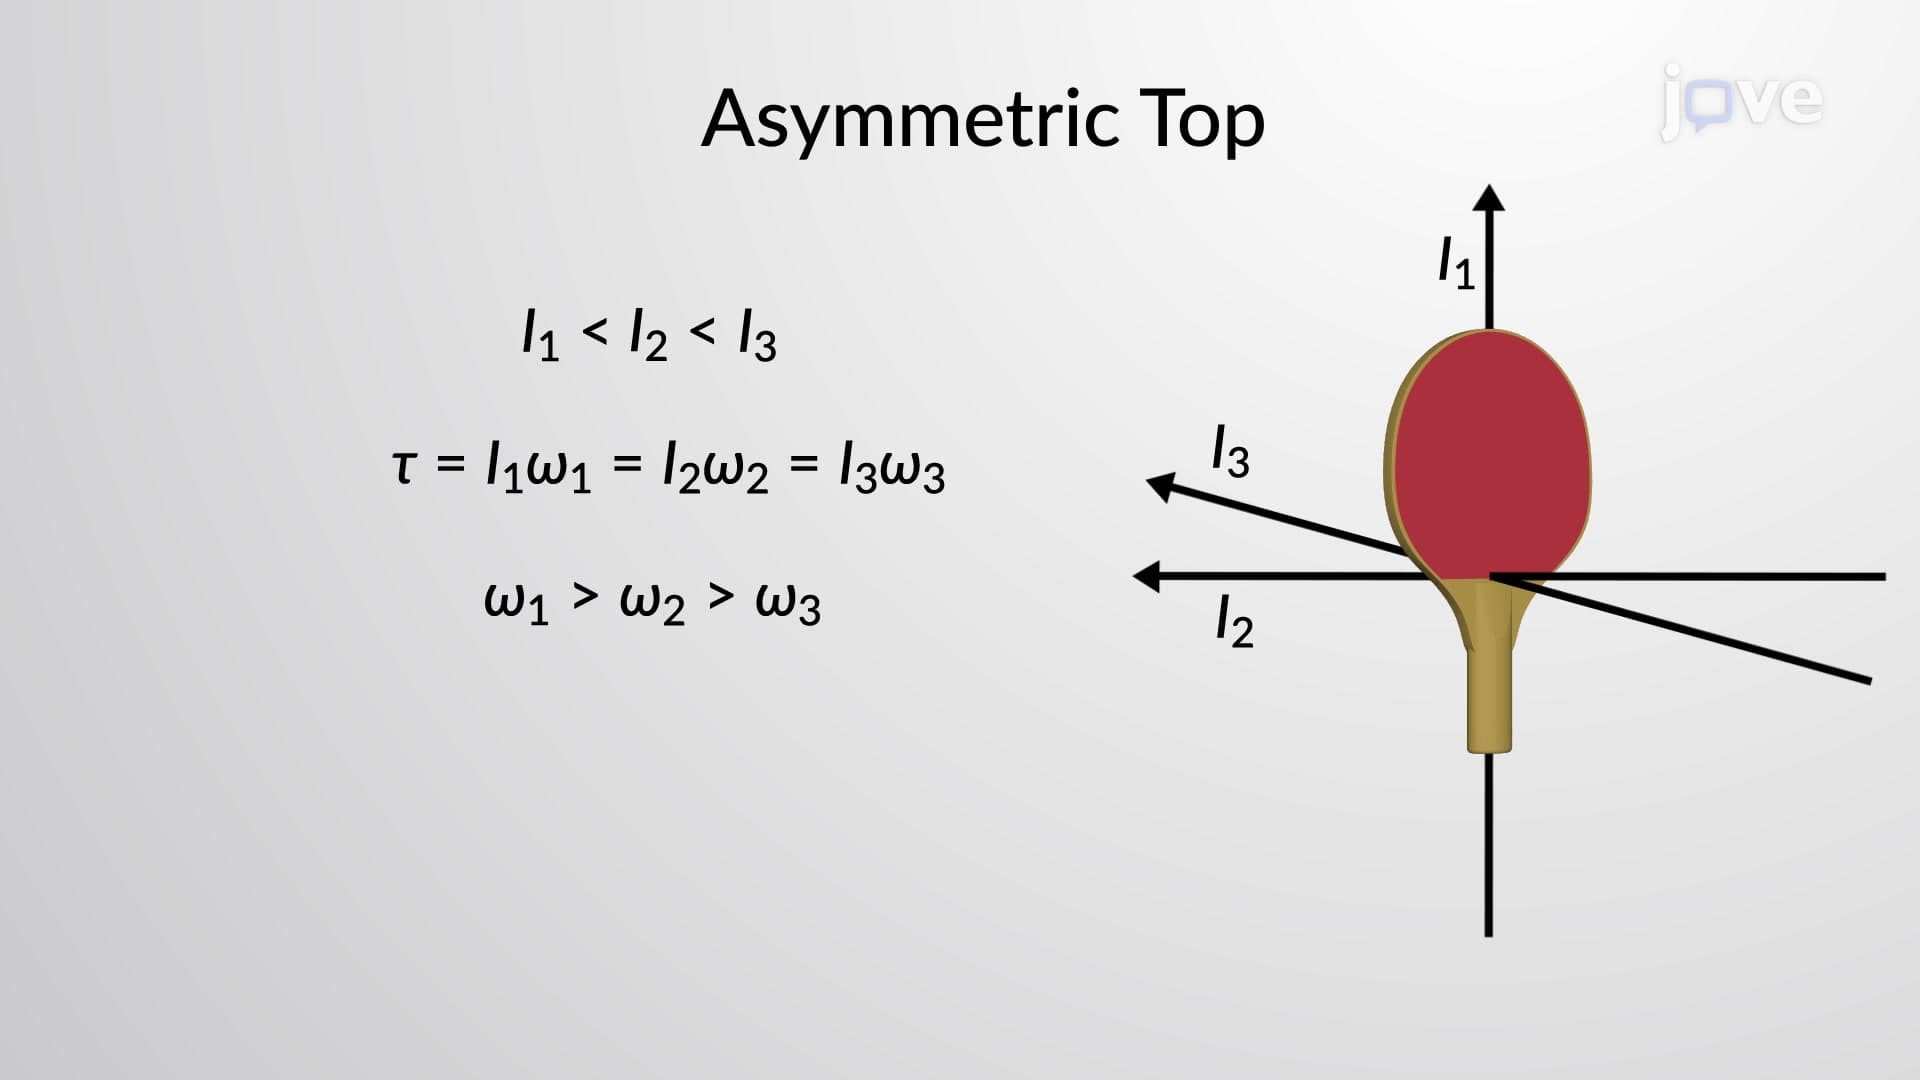
Rotation of Asymmetric Top
1.1K
By definition, a spherically symmetric body has the same moment of inertia about any axis passing through its center of mass. This situation changes if there is no spherical symmetry. Since most rigid bodies are not spherically symmetric, these require special treatment.
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
1.1K
 01:27
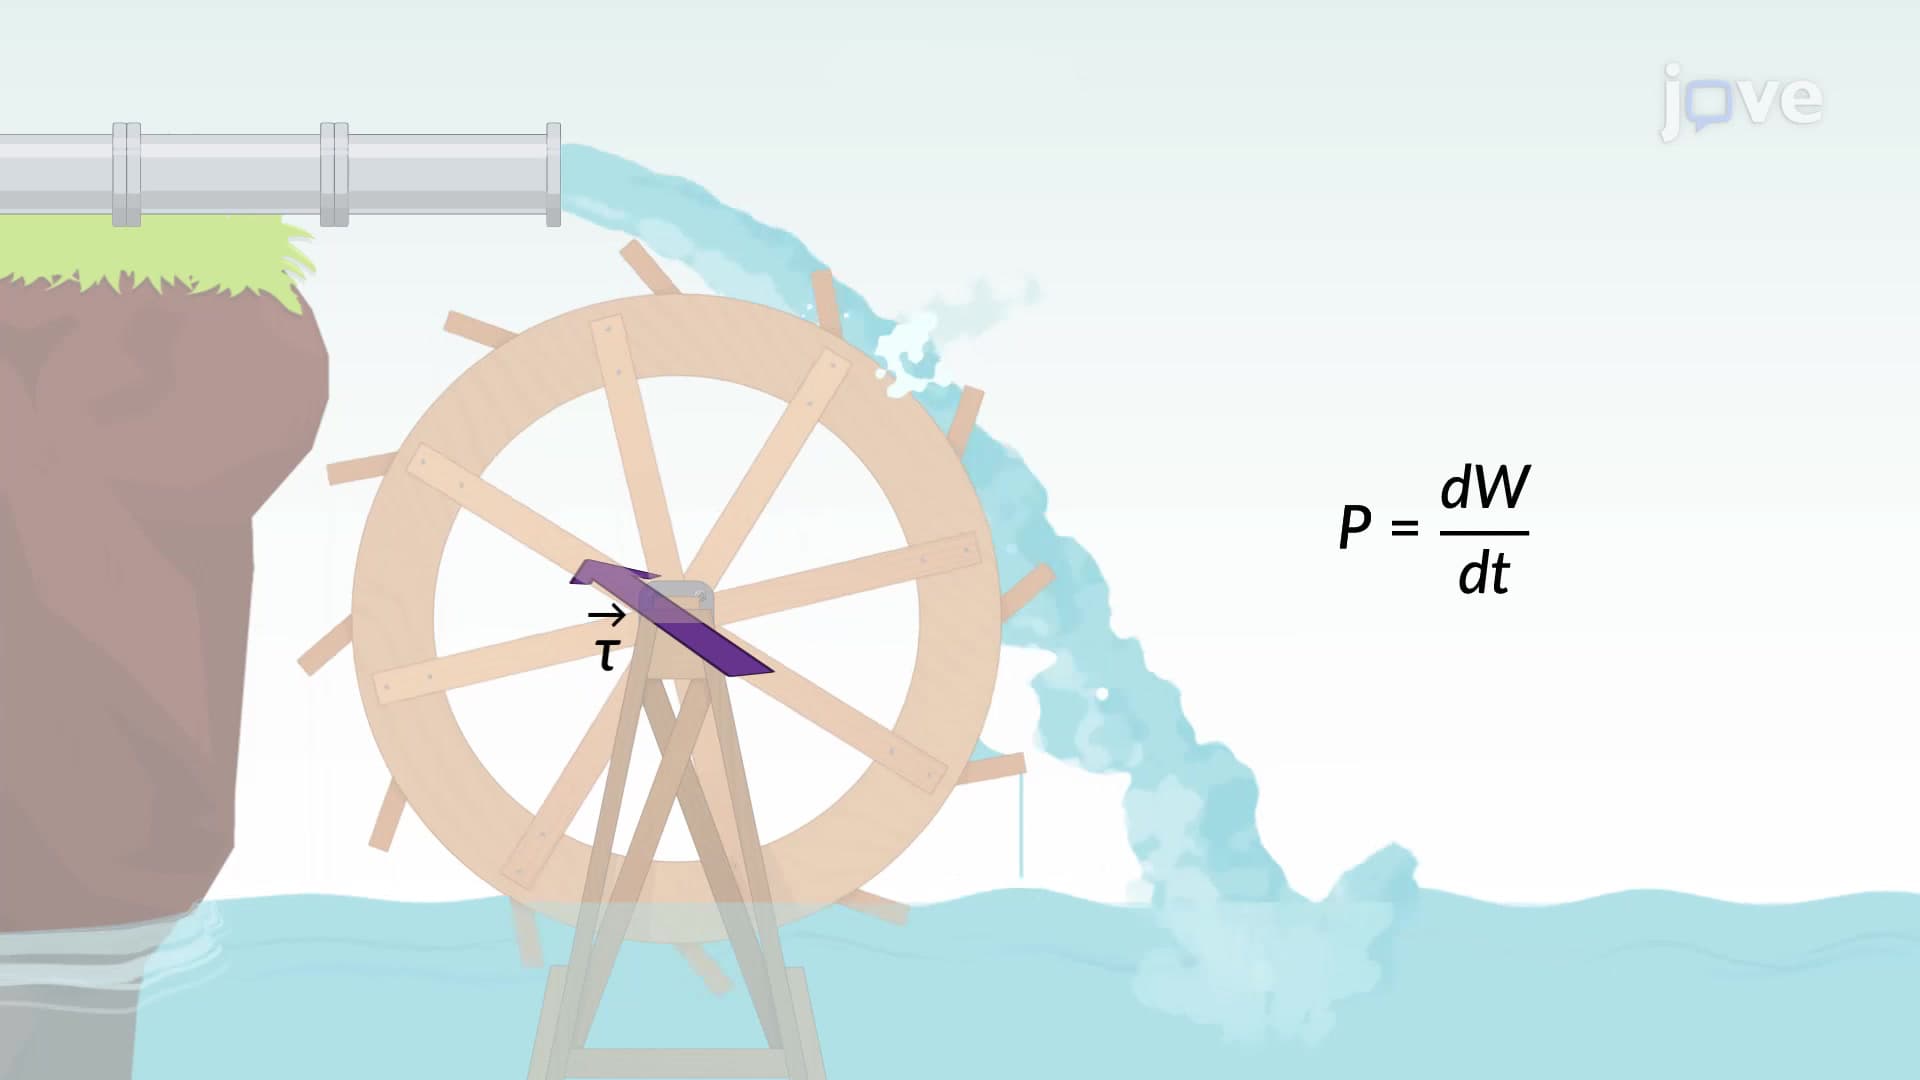
Work and Power for Rotational Motion
5.8K
Work and power in rotational motion are completely analogous to work and power in translational motion. The total work done to rotate a rigid body through an angle 'θ' about a fixed axis is the sum of the torques integrated over the angular displacement. Hence, torque and angular displacement in rotational motion are analogous to force and linear displacement in translational motion, respectively.
Similarly, the power delivered to a system that is rotating about a fixed axis...
Similarly, the power delivered to a system that is rotating about a fixed axis...
5.8K
 01:25
Relative Motion Analysis using Rotating Axes
605
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
605
 01:20
Instantaneous Center of Zero Velocity
581
General plane motion, often observed in a rolling wheel, refers to a type of movement where the wheel is simultaneously rotating and translating. This complex motion can be understood by breaking it down into individual components.
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
581