Related Experiment Video
Updated: Oct 21, 2025

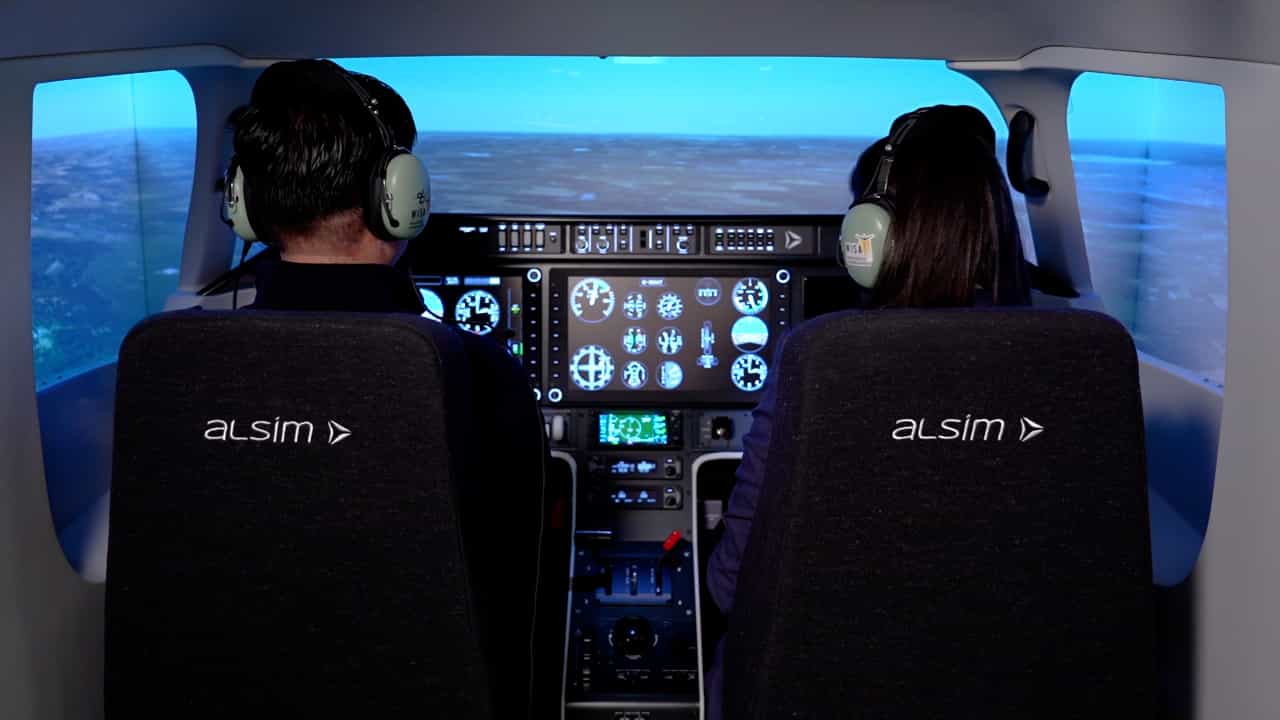
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
A model for naturalistic glance behavior around Tesla Autopilot disengagements
Alberto Morando1, Pnina Gershon1, Bruce Mehler1
1MIT Agelab, Massachusetts Institute of Technology, 1 Amherst Street, Cambridge, MA 02142, USA.

Objective:
We present a model for visual behavior that can simulate the glance pattern observed around driver-initiated, non-critical disengagements of Tesla's Autopilot (AP) in naturalistic highway driving.
Background:
Drivers may become inattentive when using partially-automated driving systems. The safety effects associated with inattention are unknown until we have a quantitative reference on how visual behavior changes with automation.
Methods:
The model is based on glance data from 290 human initiated AP disengagement epochs. Glance duration and transition were modelled with Bayesian Generalized Linear Mixed models.
Results:
The model replicates the observed glance pattern across drivers. The model's components show that off-road glances were longer with AP active than without and that their frequency characteristics changed. Driving-related off-road glances were less frequent with AP active than in manual driving, while non-driving related glances to the down/center-stack areas were the most frequent and the longest (22% of the glances exceeded 2 s). Little difference was found in on-road glance duration.
Conclusion:
Visual behavior patterns change before and after AP disengagement. Before disengagement, drivers looked less on road and focused more on non-driving related areas compared to after the transition to manual driving. The higher proportion of off-road glances before disengagement to manual driving were not compensated by longer glances ahead.
Application:
The model can be used as a reference for safety assessment or to formulate design targets for driver management systems.
More Related Videos
Related Concept Videos
 02:30
Naturalistic Observations
 01:28
Automatic Processing and Automatic Social Behavior
 02:16
Stereotype Content Model
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...
 01:12
Observational Learning
 02:09
Bystander Effect