An explicit robust stability condition for uncertain time-varying first-order plus dead-time systems
Related Experiment Video
Updated: Oct 21, 2025
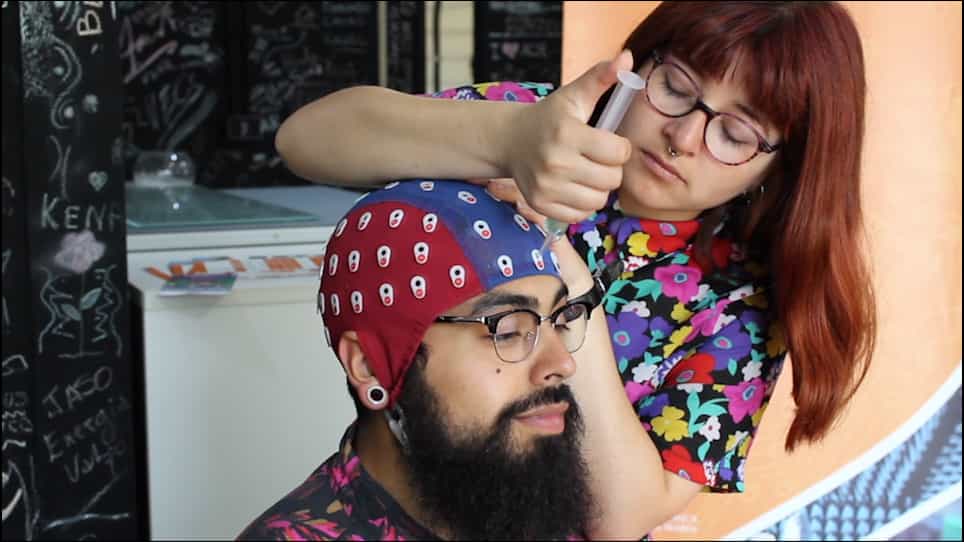
A Method for Tracking the Time Evolution of Steady-State Evoked Potentials
Published on: May 25, 2019
Saeed Salavati1, Karolos Grigoriadis1, Matthew Franchek1
1Department of Mechanical Engineering, University of Houston, Houston, TX, 77204, USA.

Abstract:
First-order plus dead-time (FOPDT) models are broadly used in process control to represent damped dynamic processes with time delays. An explicit condition for parameter- and delay-dependent robust stability of FOPDT systems with varying uncertain parameters and delay is derived in this paper. An internal model control (IMC) approach is proposed to parameterize stabilizing controllers that satisfy the output tracking objective in time-varying FOPDT systems represented by an uncertain first-order dynamic model with a time-varying delay in the control input. The small-gain theorem is used to derive an explicit necessary and sufficient parameter-dependent robust stability condition as a function of the nominal system gain, nominal varying delay, nominal time constant, and the bounds of the parameter uncertainties. An equivalent proportional-integral-derivative (PID) controller is then extracted to facilitate the implementation of the proposed IMC-based robust control. The application of the proposed explicit robust stability condition is studied in the context of air-fuel ratio (AFR) control in lean-burn spark ignition (SI) engines with a large time-varying transport delay in the control loop due to the placement of the universal exhaust gas oxygen (UEGO) sensor downstream the catalytic converter.

Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:18
Second Order systems II
 01:31
Classification of Systems-II
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:21
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...