Weak Stabilization of Boolean Networks Under State-Flipped Control
Related Experiment Video
Updated: Oct 21, 2025
A New Toolkit for Evaluating Gene Functions using Conditional Cas9 Stabilization
Published on: September 2, 2021

Abstract:
In this brief, stabilization of Boolean networks (BNs) by flipping a subset of nodes is considered, here we call such action state-flipped control. The state-flipped control implies that the logical variables of certain nodes are flipped from 1 to 0 or 0 to 1 as time flows. Under state-flipped control on certain nodes, a state-flipped-transition matrix is defined to describe the impact on the state transition space. Weak stabilization is first defined and then some criteria are presented to judge the same. An algorithm is proposed to find a stabilizing kernel such that BNs can achieve weak stabilization to the desired state with in-degree more than 0. By defining a reachable set, another approach is proposed to verify weak stabilization, and an algorithm is given to obtain a flip sequence steering an initial state to a given target state. Subsequently, the issue of finding flip sequences to steer BNs from weak stabilization to global stabilization is addressed. In addition, a model-free reinforcement algorithm, namely the Q -learning ( [Formula: see text]) algorithm, is developed to find flip sequences to achieve global stabilization. Finally, several numerical examples are given to illustrate the obtained theoretical results.
More Related Videos
 10:51
An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
 10:44
Inherent Dynamics Visualizer, an Interactive Application for Evaluating and Visualizing Outputs from a Gene Regulatory Network Inference Pipeline
Published on: December 7, 2021
Related Concept Videos
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:14
Stability of structures
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:21
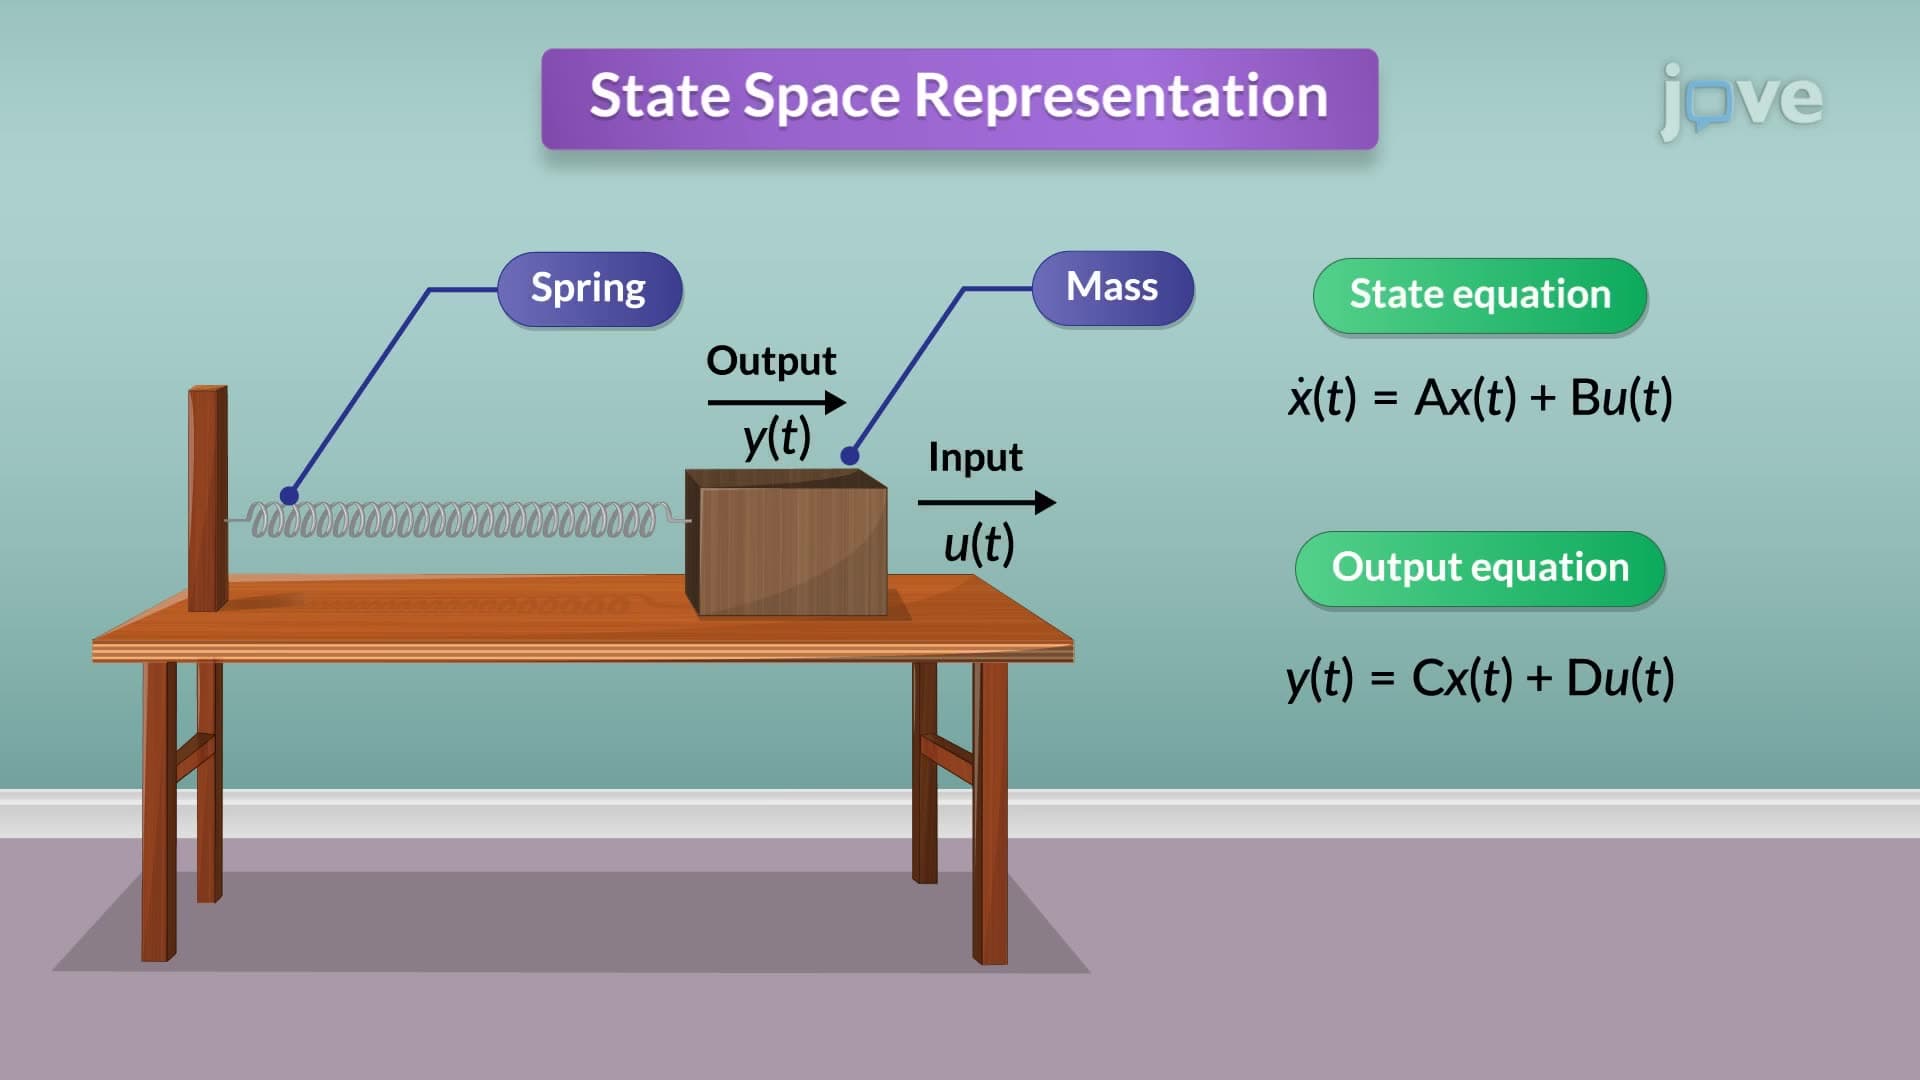
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as: