Related Experiment Video
Updated: Oct 20, 2025


An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
Real-Time Identification of Wrist Kinematics via Sparsity-Promoting Extended Kalman Filter Based on Ellipsoidal Joint

Objective:
This paper proposes a novel method for real-time wrist kinematics identification.
Method:
We design the wrist kinematics regression model following a novel ellipsoidal joint formulation, which features a quaternion-based rotation constraint and 2-dimensional Fourier linear combiners (FLC) to approximate the coupled rotations and translational displacements of the wrist. Extended Kalman Filter (EKF) is then implemented to update the model in real-time. However, unlike previous studies, here we introduce a sparsity-promoting feature in the model regression through the optimality of EKF by designing a smooth l1-minimization observation function. This is done to ensure the best identification of key parameters, and to improve the robustness of regression under noisy conditions.
Results:
Simulations employ multiple reference models to evaluate the performance of the proposed approach. Experiments are later carried out on motion data collected by a lab-developed wrist kinematics measurement tool. Both simulation and experiment show that the proposed approach can robustly identify the wrist kinematics in real-time.
Conclusion:
The findings confirm that the proposed regression model combined with the sparsity-promoting EKF is reliable in the real-time modeling of wrist kinematics.
Significance:
The proposed method can be applied to generic wrist kinematics modeling problems, and utilized in the control system of wearable wrist exoskeletons. The framework of the proposed method may also be applied to real-time identification of other joints for exoskeleton control.
Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:15
Kinematic Equations: Problem Solving
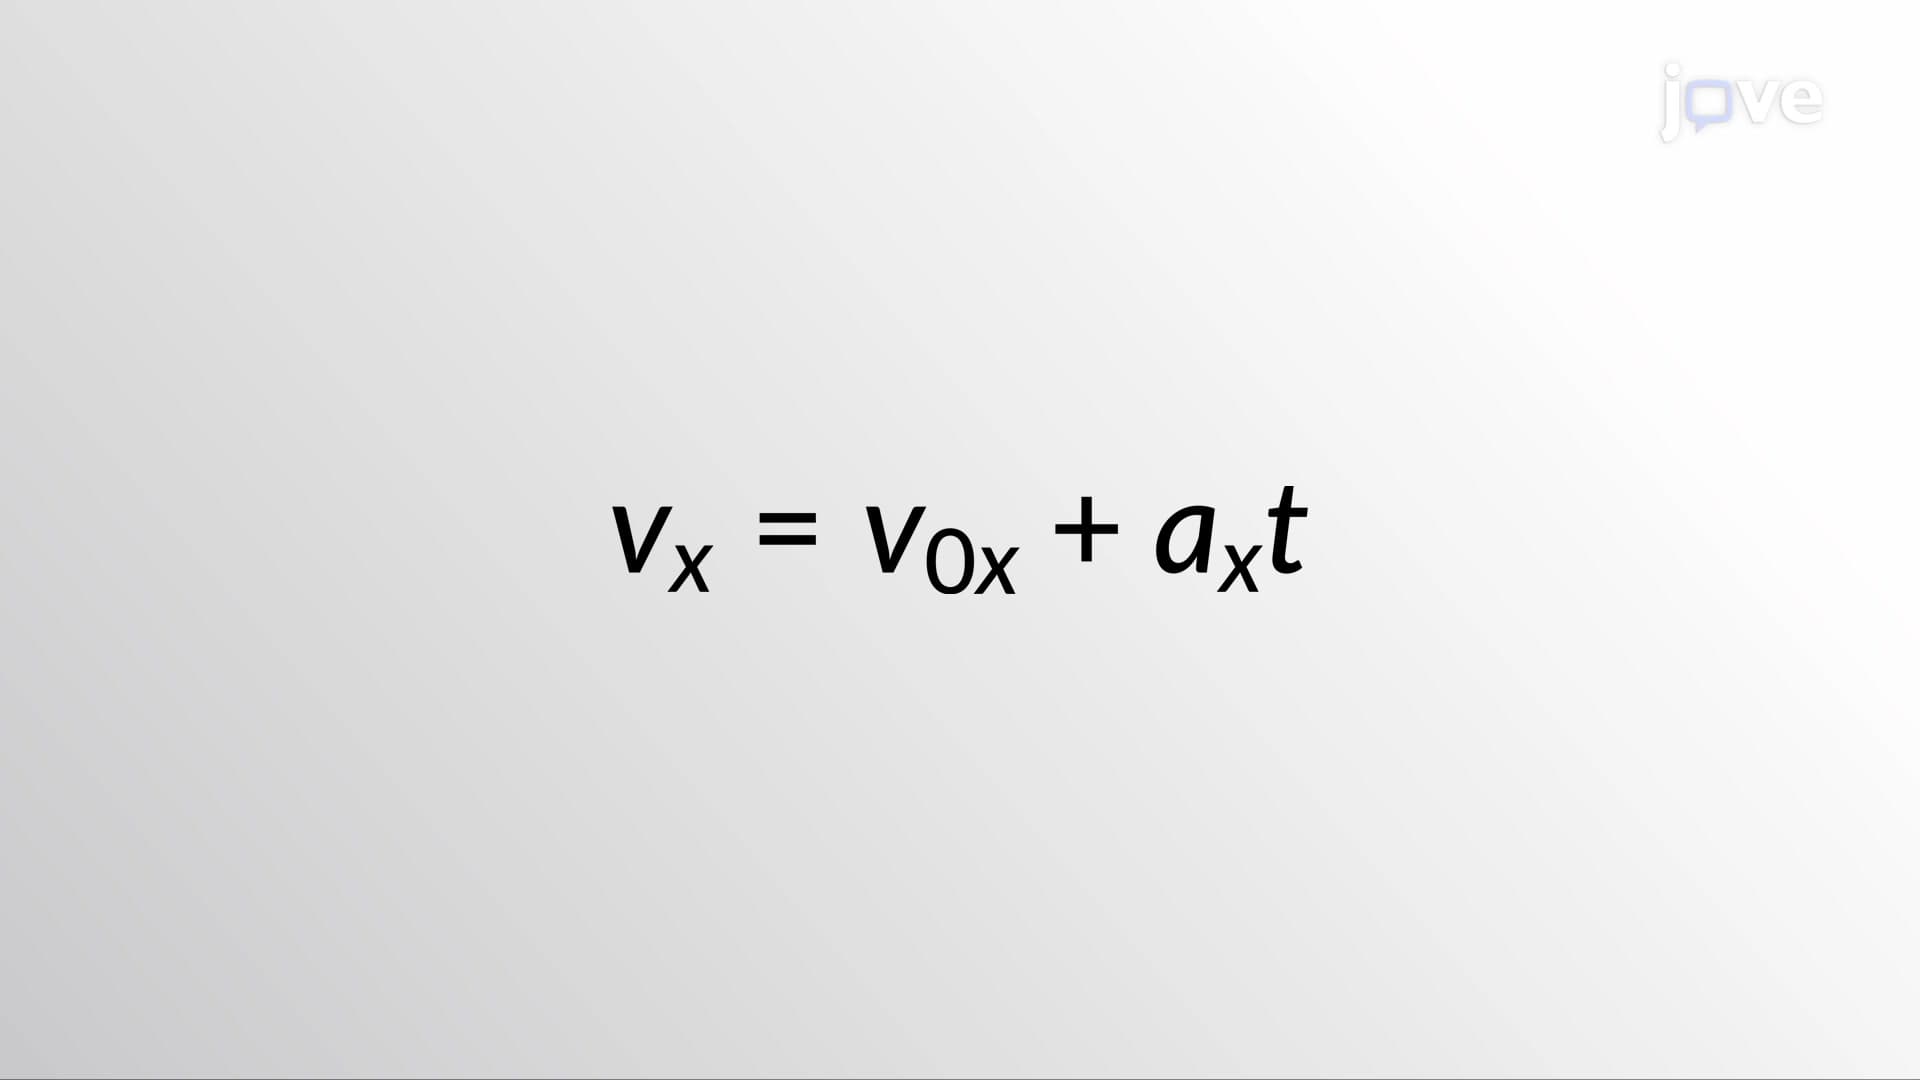 01:26
Kinematic Equations - I
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...