Related Experiment Video
Updated: Oct 20, 2025


The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
Study on Magnetic Control Systems of Micro-Robots
Youjia Shao1,2, Ashraf Fahmy3,4, Ming Li1
1School of Automation and Electronic Engineering, Qingdao University of Science and Technology, Qingdao, China.

Abstract:
Magnetic control systems of micro-robots have recently blossomed as one of the most thrilling areas in the field of medical treatment. For the sake of learning how to apply relevant technologies in medical services, we systematically review pioneering works published in the past and divide magnetic control systems into three categories: stationary electromagnet control systems, permanent magnet control systems and mobile electromagnet control systems. Based on this, we ulteriorly analyze and illustrate their respective strengths and weaknesses. Furthermore, aiming at surmounting the instability of magnetic control system, we utilize SolidWorks2020 software to partially modify the SAMM system to make its final overall thickness attain 111 mm, which is capable to control and observe the motion of the micro-robot under the microscope system in an even better fashion. Ultimately, we emphasize the challenges and open problems that urgently need to be settled, and summarize the direction of development in this field, which plays a momentous role in the wide and safe application of magnetic control systems of micro-robots in clinic.
Related Concept Videos
 01:13
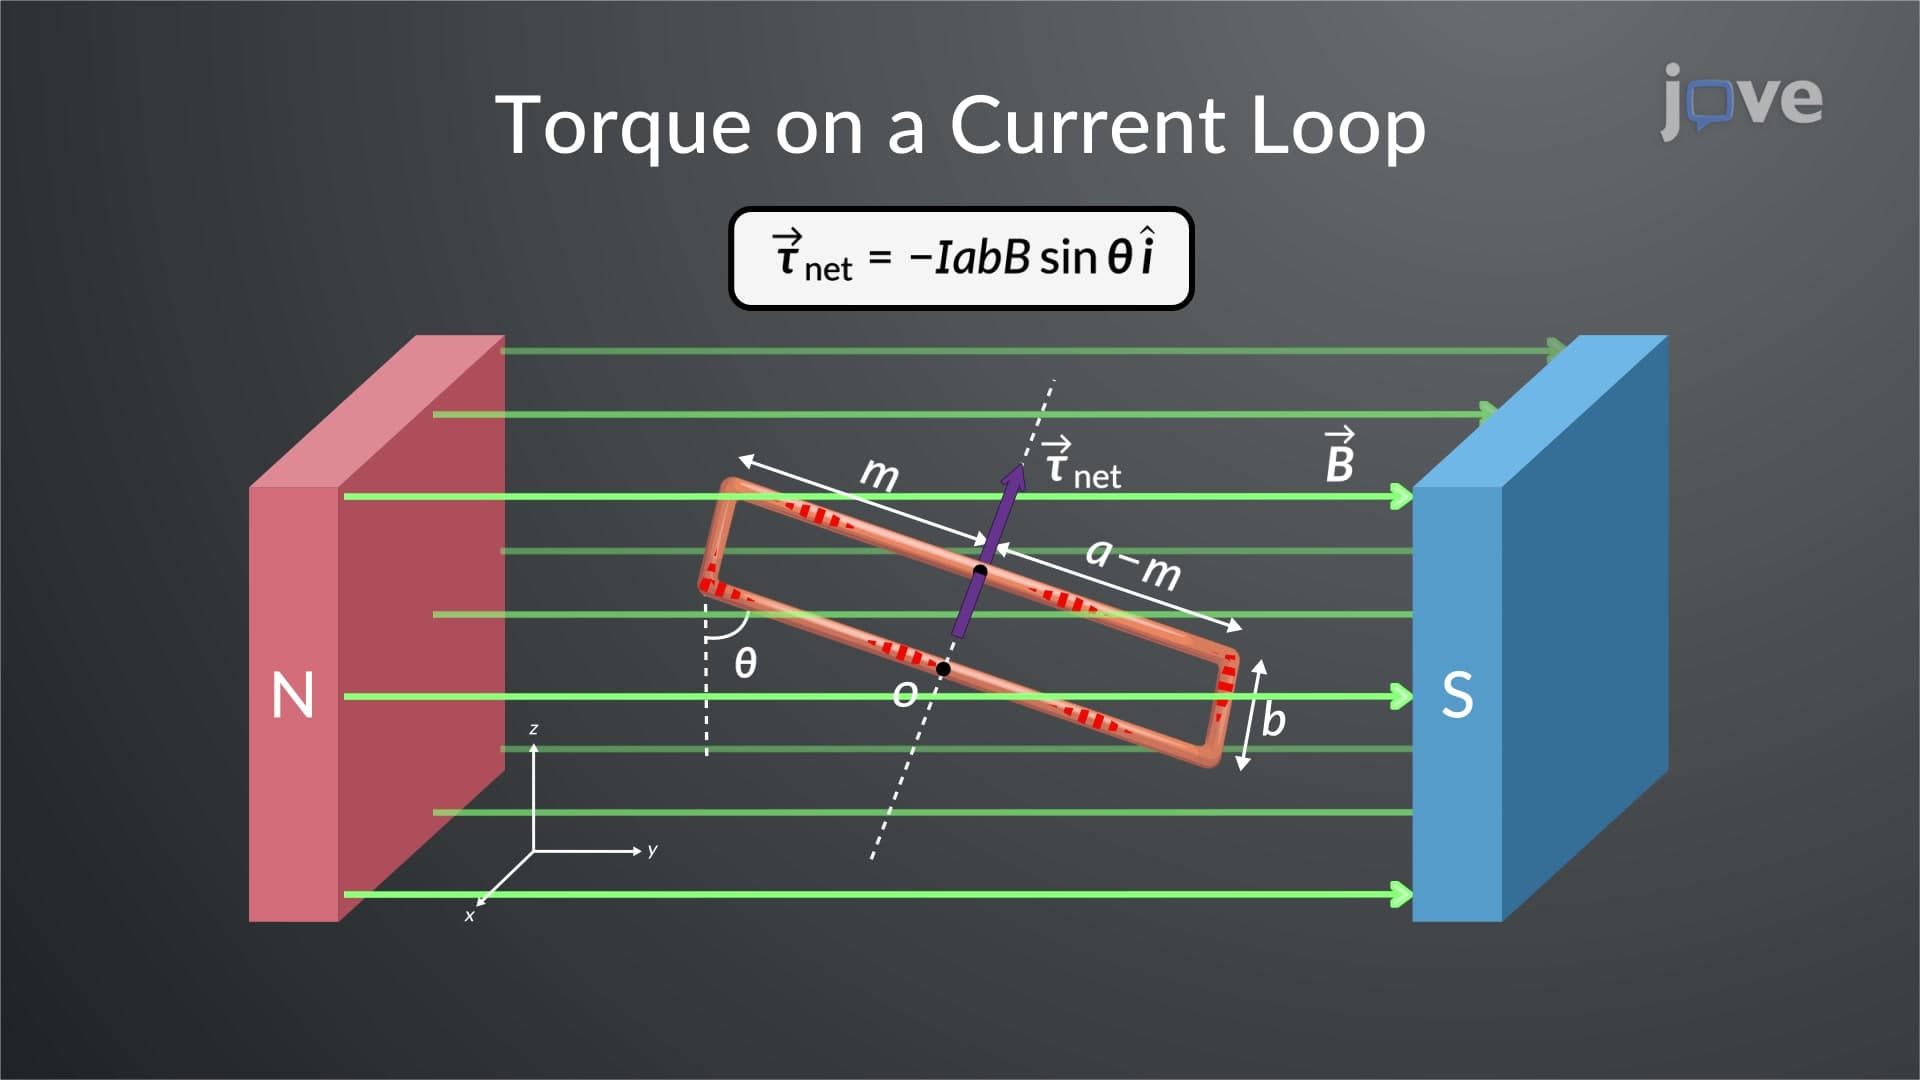
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:17
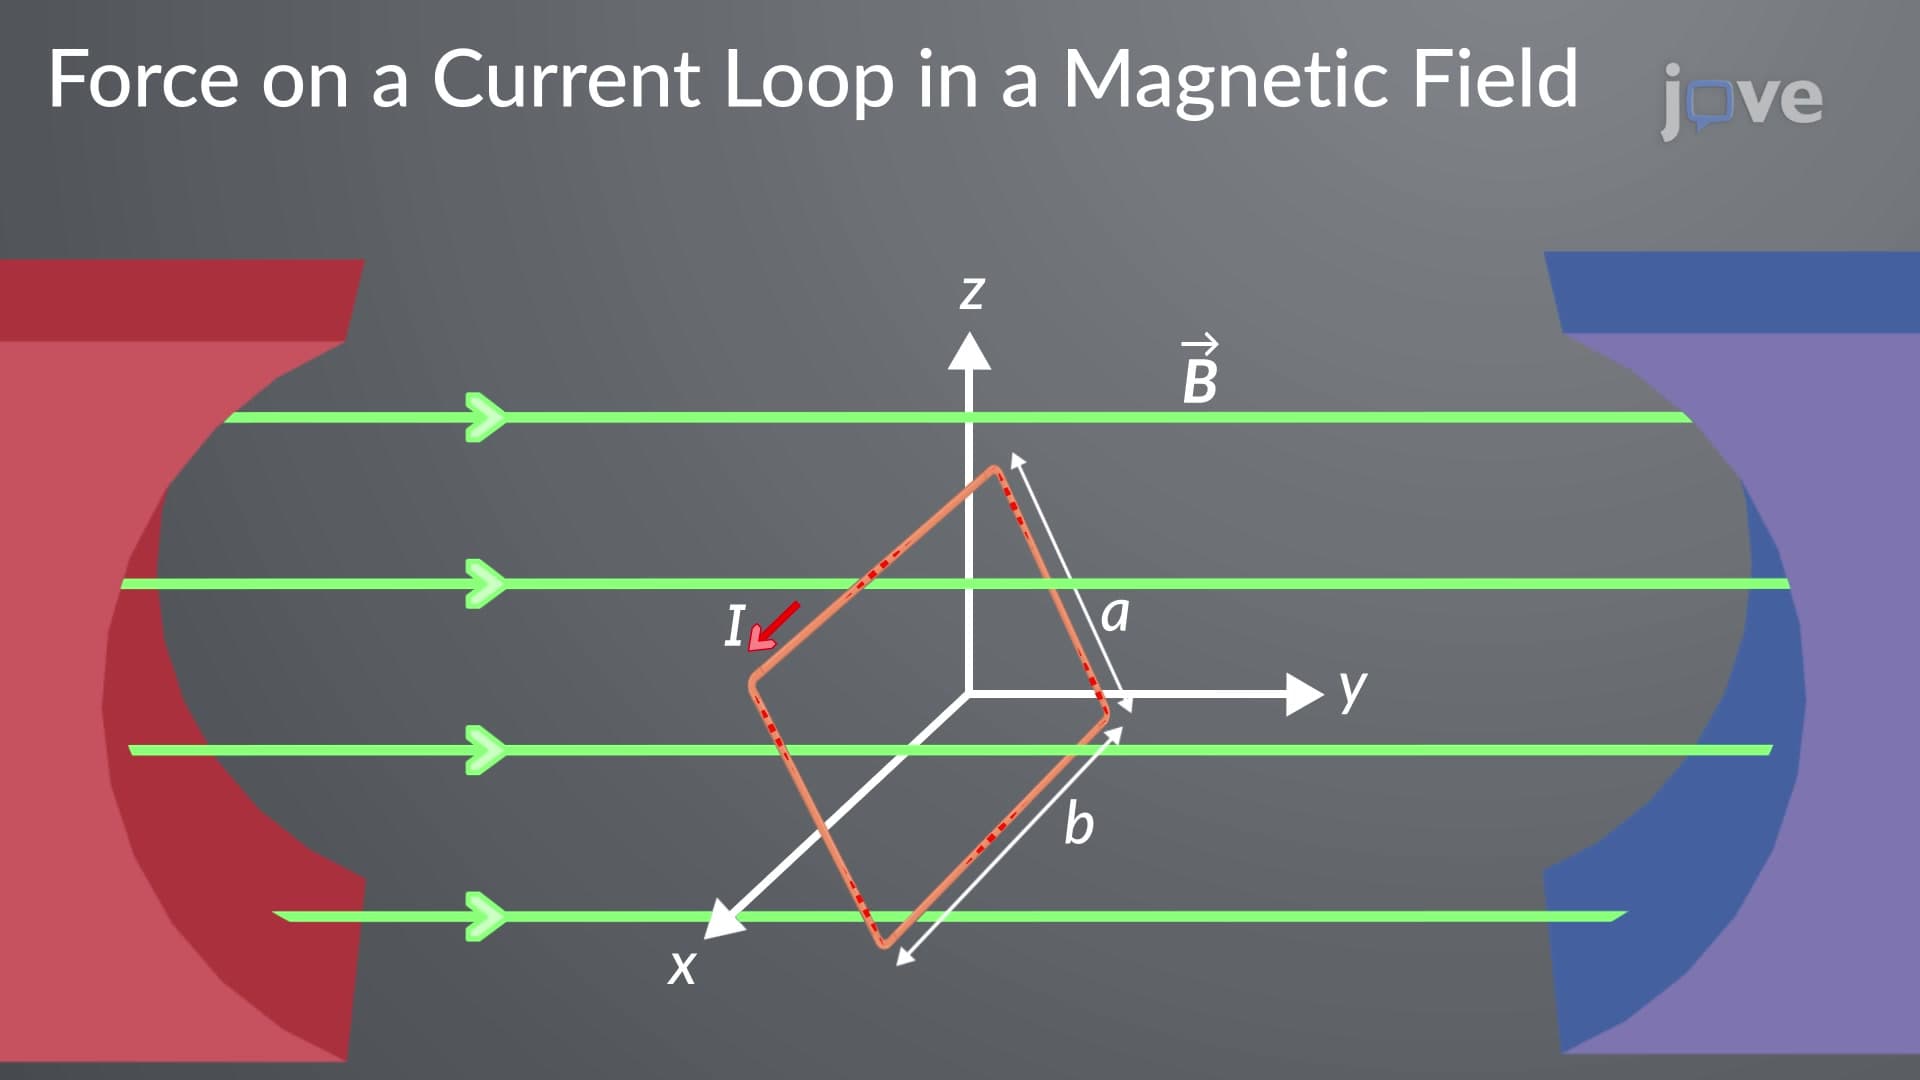
Force On A Current Loop In A Magnetic Field