Related Experiment Video
Updated: Oct 20, 2025

Cardiac Muscle-cell Based Actuator and Self-stabilizing Biorobot - PART 1
Published on: July 11, 2017
Robust Jumping Actuator with a Shrimp-Shell Architecture
Kaiqing Yu1, Xiaozhou Ji2, Tianyu Yuan2
1State Key Laboratory of Medicinal Chemical Biology, Key Laboratory of Functional Polymer Materials, College of Chemistry, Nankai University, Tianjin, 300071, China.

Abstract:
It is highly desirable to develop compact- and robust-film jumping robots that can withstand severe conditions. Besides, the demands for strong actuation force, large bending curvature in a short response time, and good environmental tolerance are significant challenges to the material design. To address these challenges, this paper reports the fabrication of a thin-film jumping actuator, which exhibits a shrimp-shell architecture, from a conjugated ladder polymer (cLP) that is connected by carbon nanotube (CNT) sheets. The hierarchical porous structure ensures the fast absorption and desorption of organic vapor, thereby achieving a high response rate. The actuator does not exhibit shape distortion at temperatures of up to 225 °C and in concentrated sulfuric acid, as well as when immersed in many organic solvents. This work avails a new design strategy for high-performance actuators that function under harsh and complicated conditions.

Related Concept Videos
 01:16
Hydraulic Jump: Problem Solving
 01:29
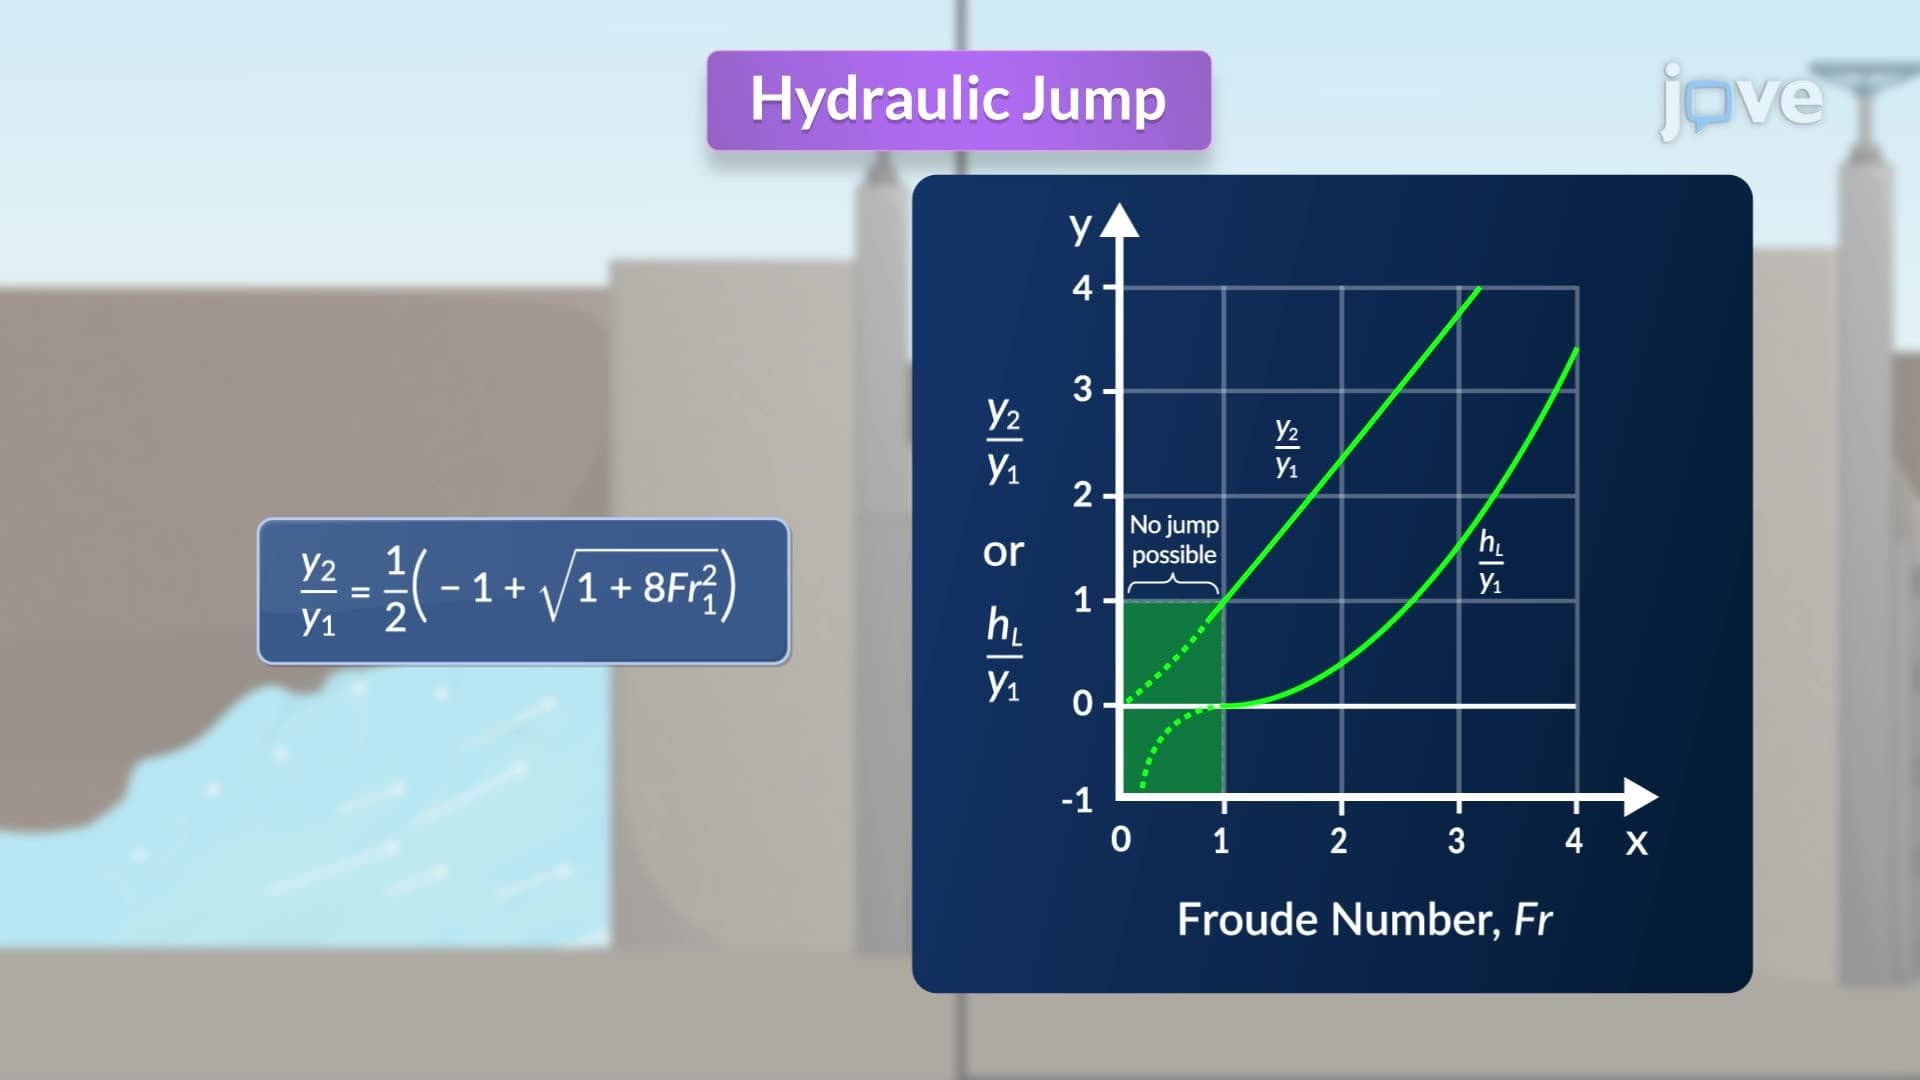
Hydraulic Jump
 01:14
Design Example: Frog Muscle Response
When the switch connecting the RL circuit is closed, a brief muscle contraction is observed. This is because, at a steady state, the inductor acts like a short...
 01:13
Archimedes' Principle
 01:11
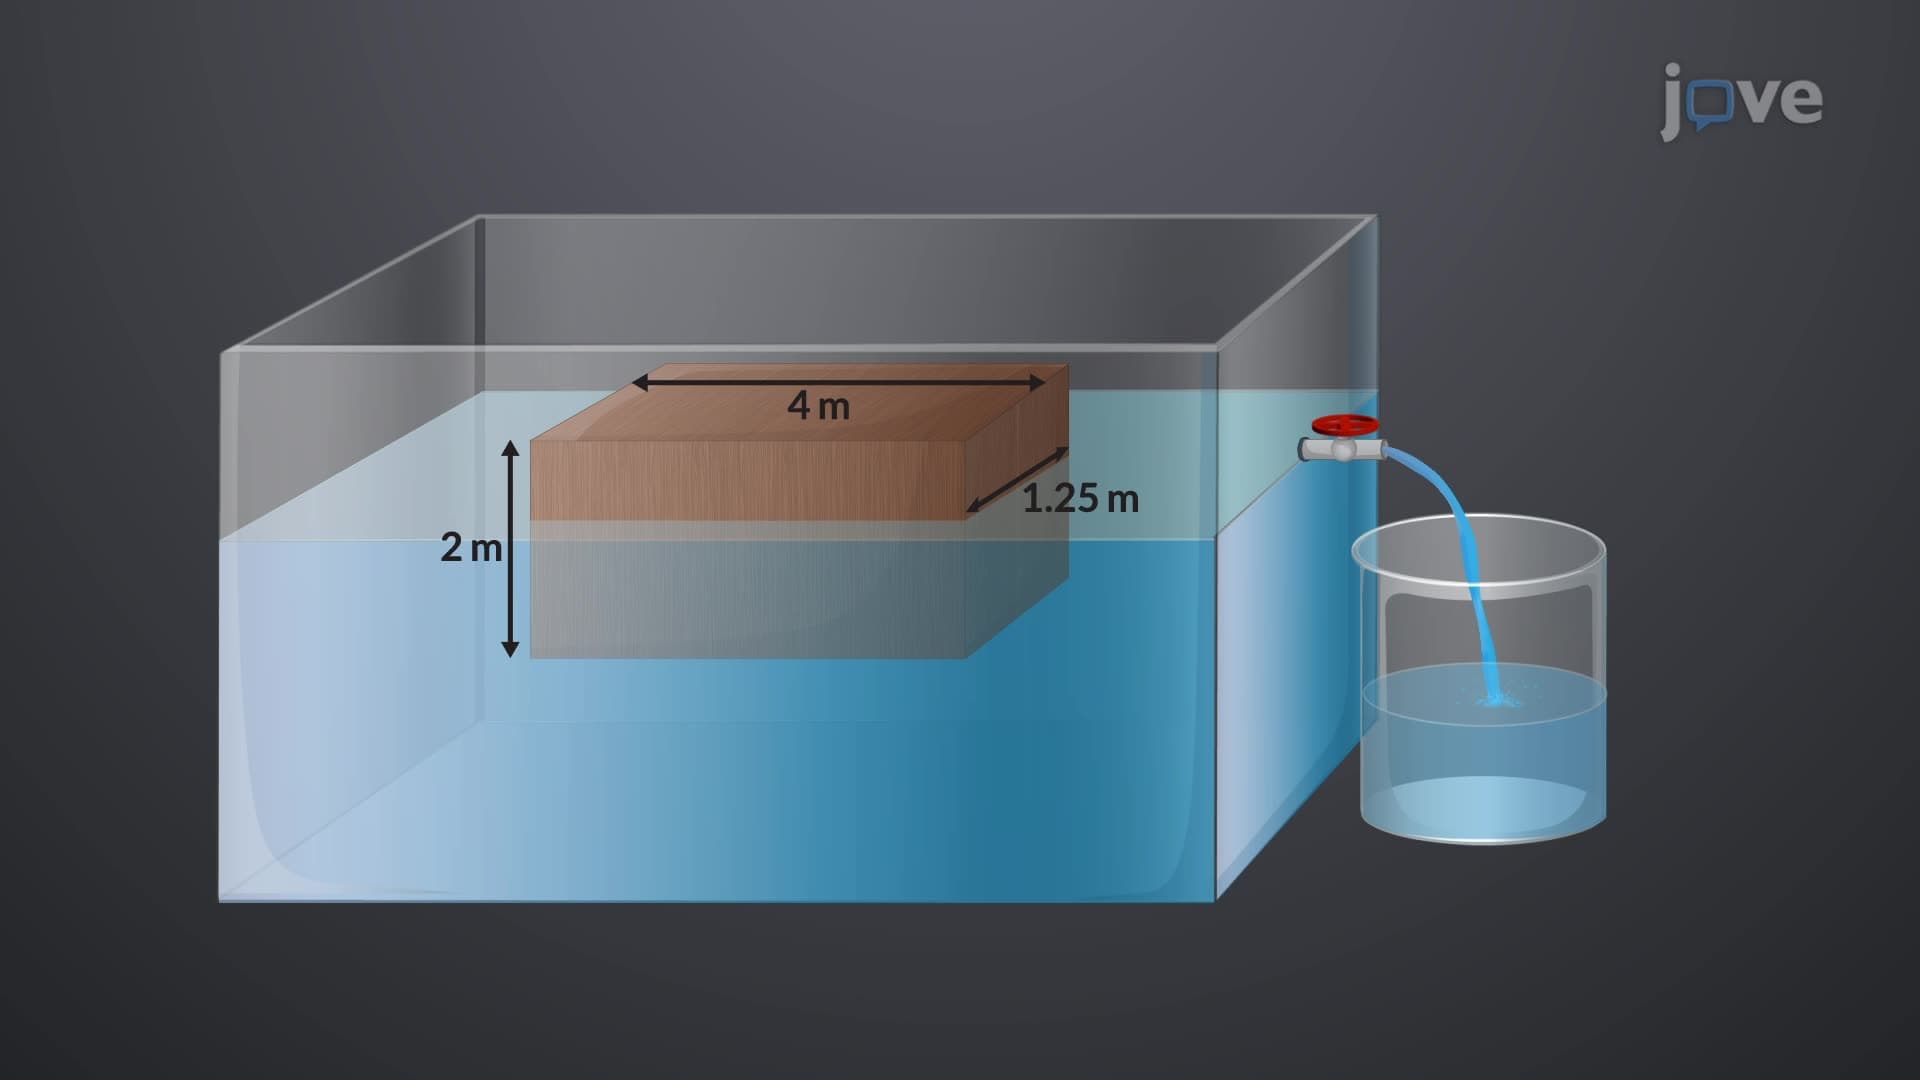
Design Example: Application of Archimedes' Principle
The volume of seawater displaced by the block is determined by first calculating the block's weight. This is done by multiplying the...
 01:11
Buoyancy and Stability for Submerged and Floating Bodies