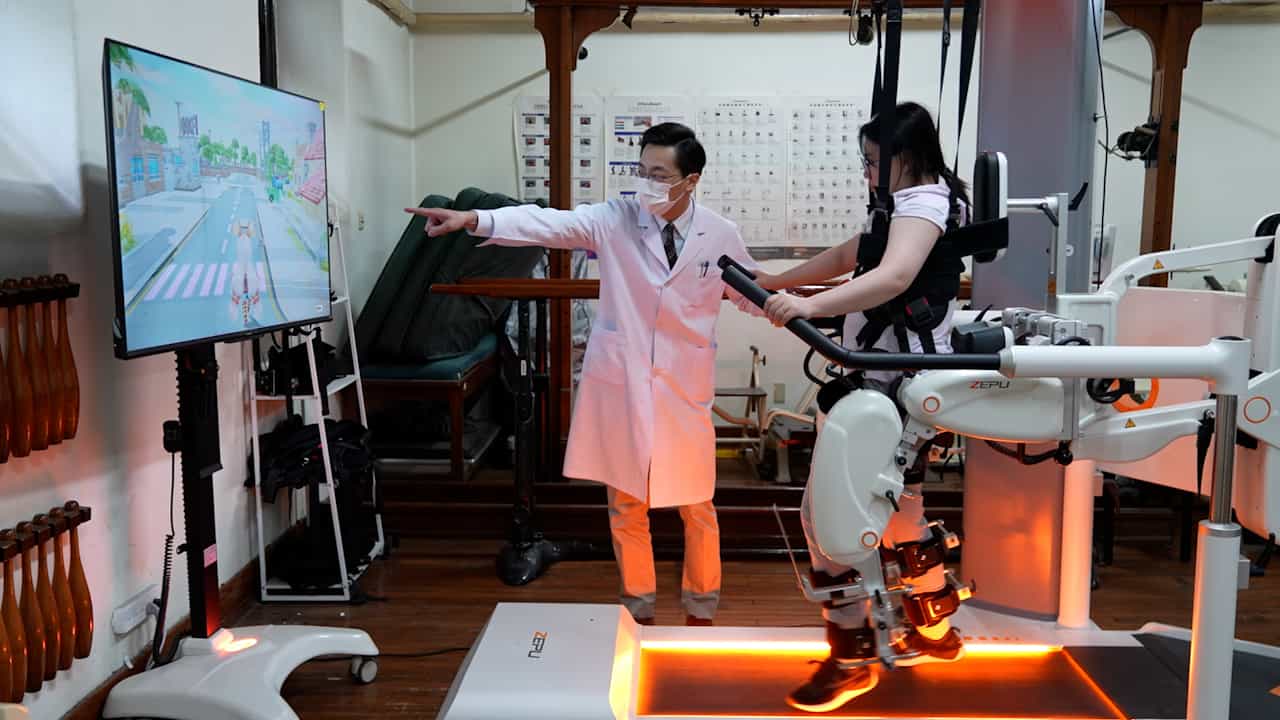
Related Experiment Video
Updated: Oct 19, 2025


Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Walking with and without a robotic exoskeleton in people with incomplete spinal cord injury compared to a typical
Sattam Almutairi1, Chad Swank2, Sharon Wang-Price3
1Department of Physical Therapy, College of Medical Rehabilitation, Qassim University, Buraydah, Saudi Arabia.

Background:
Robotic exoskeleton (RE) enables individuals with lower extremity weakness or paralysis to stand and walk in a stereotypical pattern.
Objective:
Examine whether people with chronic incomplete spinal cord injury (SCI) demonstrate a more typical gait pattern when walking overground in a RE than when walking without.
Methods:
Motion analysis system synchronized with a surface electromyographic (EMG) was used to obtain temporospatial gait parameters, lower extremity kinematics, and muscle activity in ambulatory individuals with SCI and healthy adults.
Results:
Temporospatial parameters and kinematics for participants with SCI (n = 12; age 41.4±12.5 years) with and without RE were significantly different than a typical gait (healthy adults: n = 15; age 26.2±8.3 years). EMG amplitudes during the stance phase of a typical gait were similar to those with SCI with and without RE, except the right rectus femoris (p = 0.005) and left gluteus medius (p = 0.014) when participants with SCI walked with RE. EMG amplitudes of participants with SCI during the swing phase were significantly greater compared to those of a typical gait, except for left medial hamstring with (p = 0.025) and without (p = 0.196) RE.
Conclusions:
First-time walking in a RE does not appear to produce a typical gait pattern in people with incomplete SCI.