Related Experiment Video
Updated: Oct 18, 2025
Design and Analysis for Fall Detection System Simplification
Published on: April 6, 2020
State Observer for Linear Systems with Explicit Constraints: Orthogonal Decomposition Method
Sergei Savin1, Oleg Balakhnov1, Ramil Khusainov1
1Center for Technologies in Robotics and Mechatronics Components, Innopolis University, Innopolis 420500, Russia.

Abstract:
In this paper, an orthogonal decomposition-based state observer for systems with explicit constraints is proposed. State observers have been an integral part of robotic systems, reflecting the practicality and effectiveness of the dynamic state feedback control, but the same methods are lacking for the systems with explicit mechanical constraints, where observer designs have been proposed only for special cases of such systems, with relatively restrictive assumptions. This work aims to provide an observer design framework for a general case linear time-invariant system with explicit constraints, by finding lower-dimensional subspaces in the state space, where the system is observable while giving sufficient information for both feedback and feed-forward control. We show that the proposed formulation recovers minimal coordinate representation when it is sufficient for the control law generation and retains non-minimal coordinates when those are required for the feed-forward control law. The proposed observer is tested on a flywheel inverted pendulum and on a quadruped robot Unitree A1.
More Related Videos

Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:26
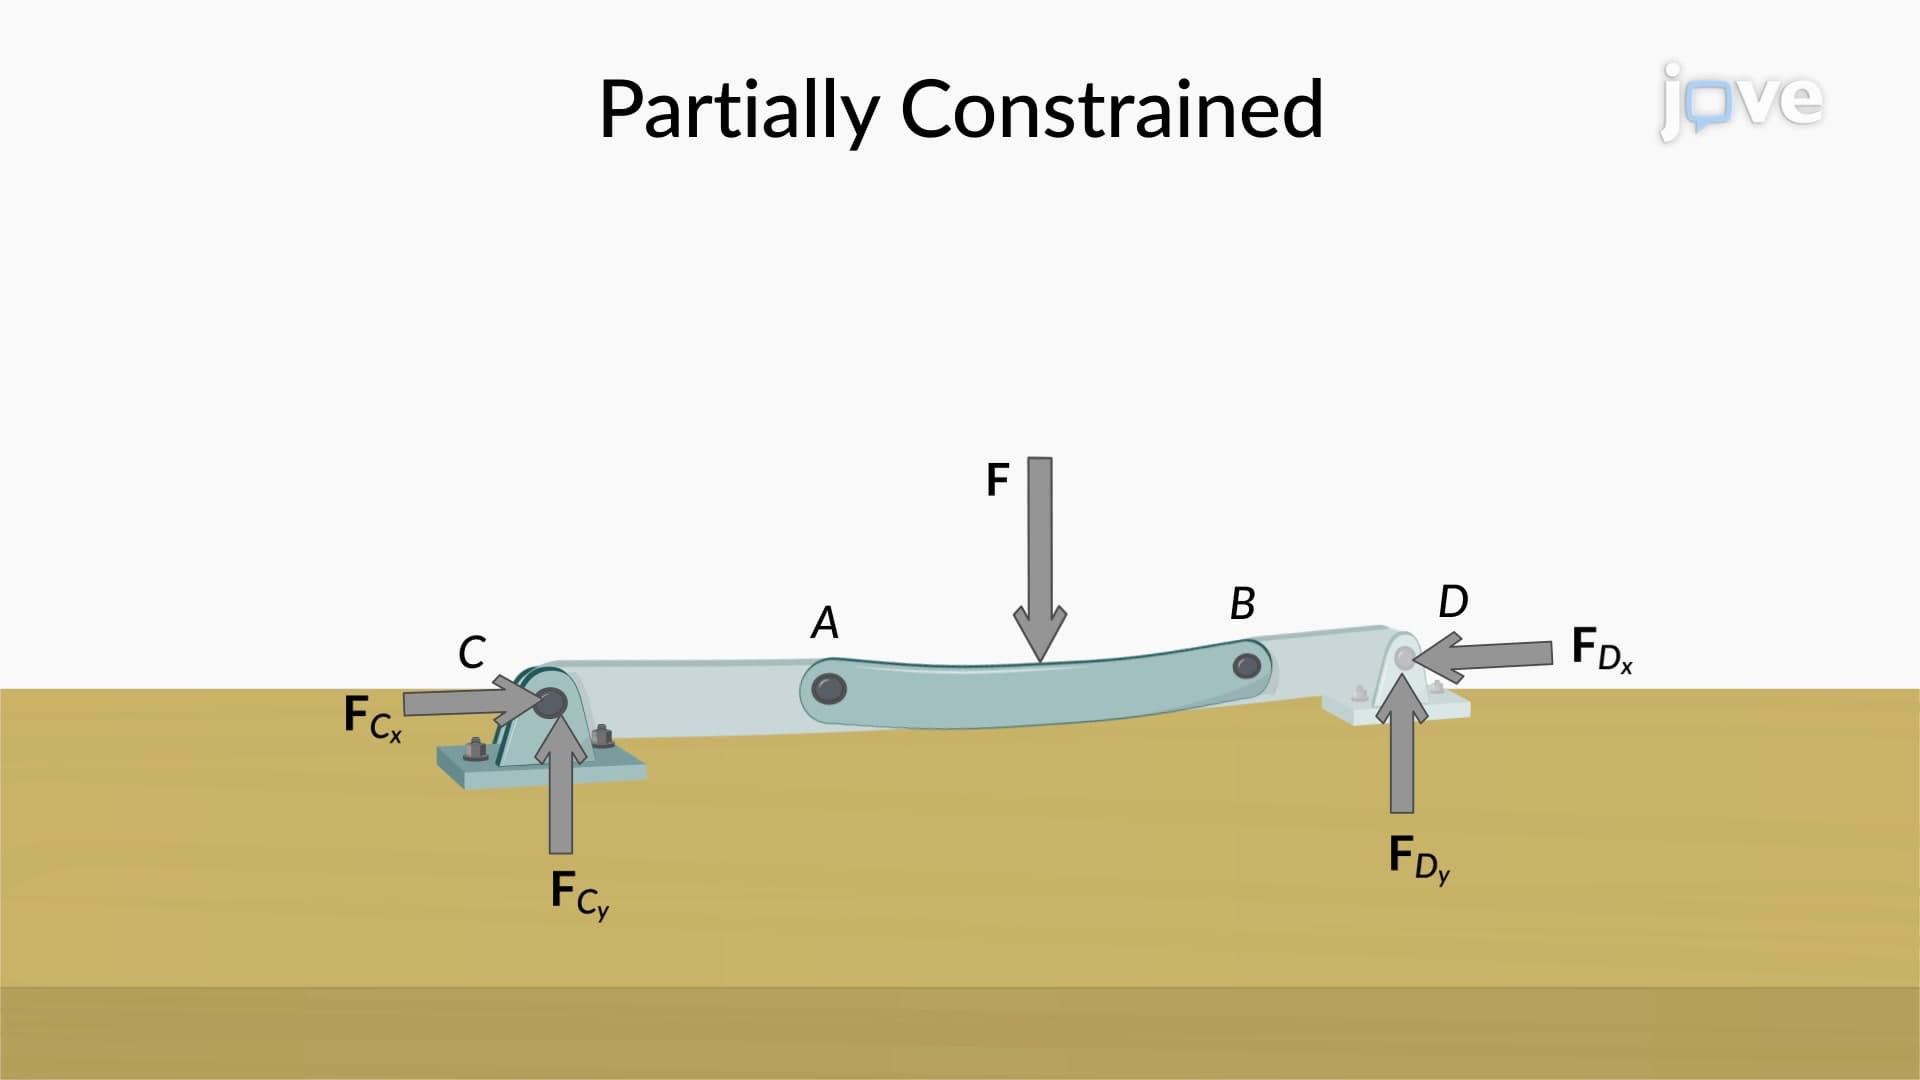
Constraints and Statical Determinacy
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:16
Statically Indeterminate Problem Solving
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...