Related Experiment Video
Updated: Oct 18, 2025

Investigating the Three-dimensional Flow Separation Induced by a Model Vocal Fold Polyp
Published on: February 3, 2014
On bifurcations of Lorenz attractors in the Lyubimov-Zaks model
1National Research University Higher School of Economics, 25/12 Bolshaya Pecherskaya Ulitsa, 603155 Nizhny Novgorod, Russia.

Abstract:
We provide numerical evidence for the existence of the Lorenz and the Rovella (contracting Lorenz) attractors in the generalization of the Lorenz model proposed by Lyubimov and Zaks. The Lorenz attractor is robustly chaotic (pseudohyperbolic) in contrast to the Rovella attractor, which is only measure-persistent (it exists for a set of parameter values, which is nowhere dense but has a positive Lebesgue measure). It is well known that in this model, for certain values of parameters, there exists a homoclinic butterfly (a pair of homoclinic loops) to the symmetric saddle equilibrium, which is neutral, i.e., its eigenvalues λ2<λ1<0<γ are such that the saddle index ν=-λ1/γ is equal to ∼1. The birth of the Lorenz attractor at this codimension-two bifurcation is established by means of numerical verification of the Shilnikov criterion. For the birth of the Rovella attractor, we propose a new criterion, which is also verified numerically.
Related Concept Videos
 01:19
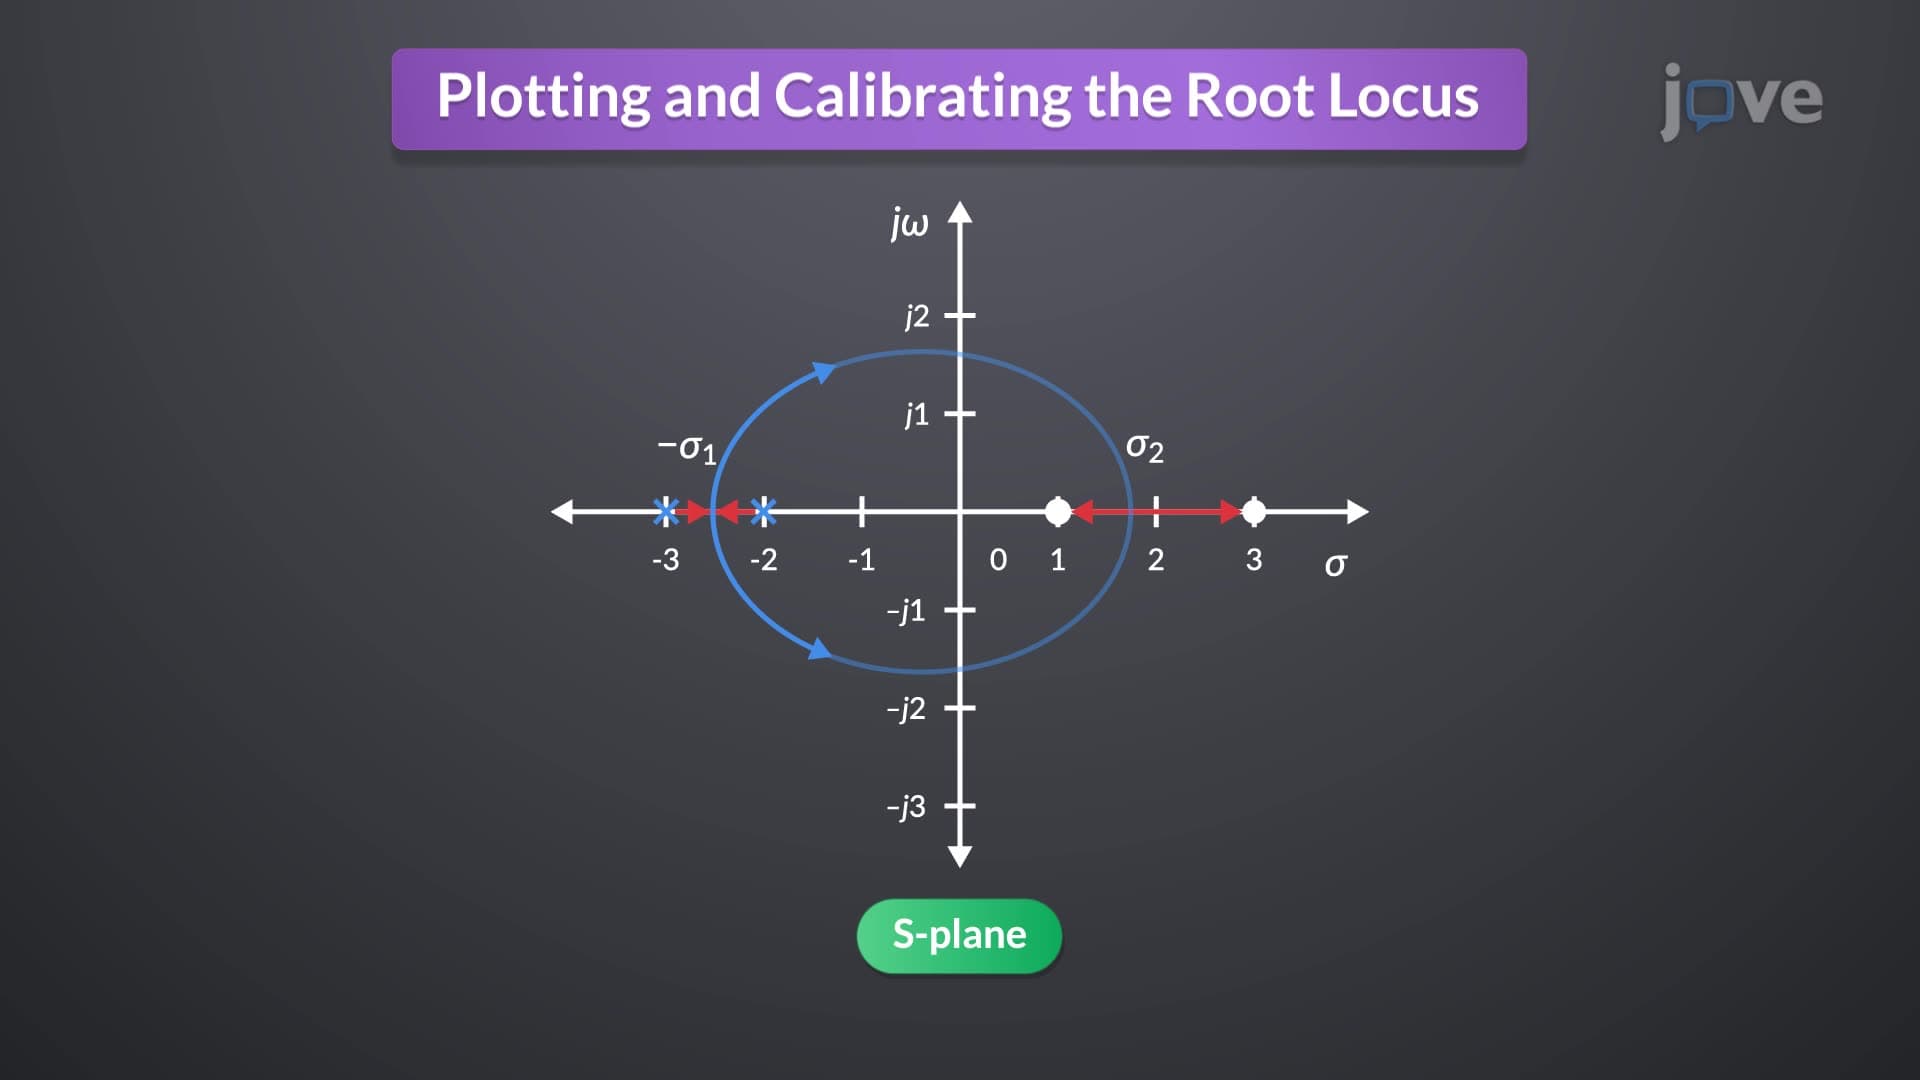
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
 01:23
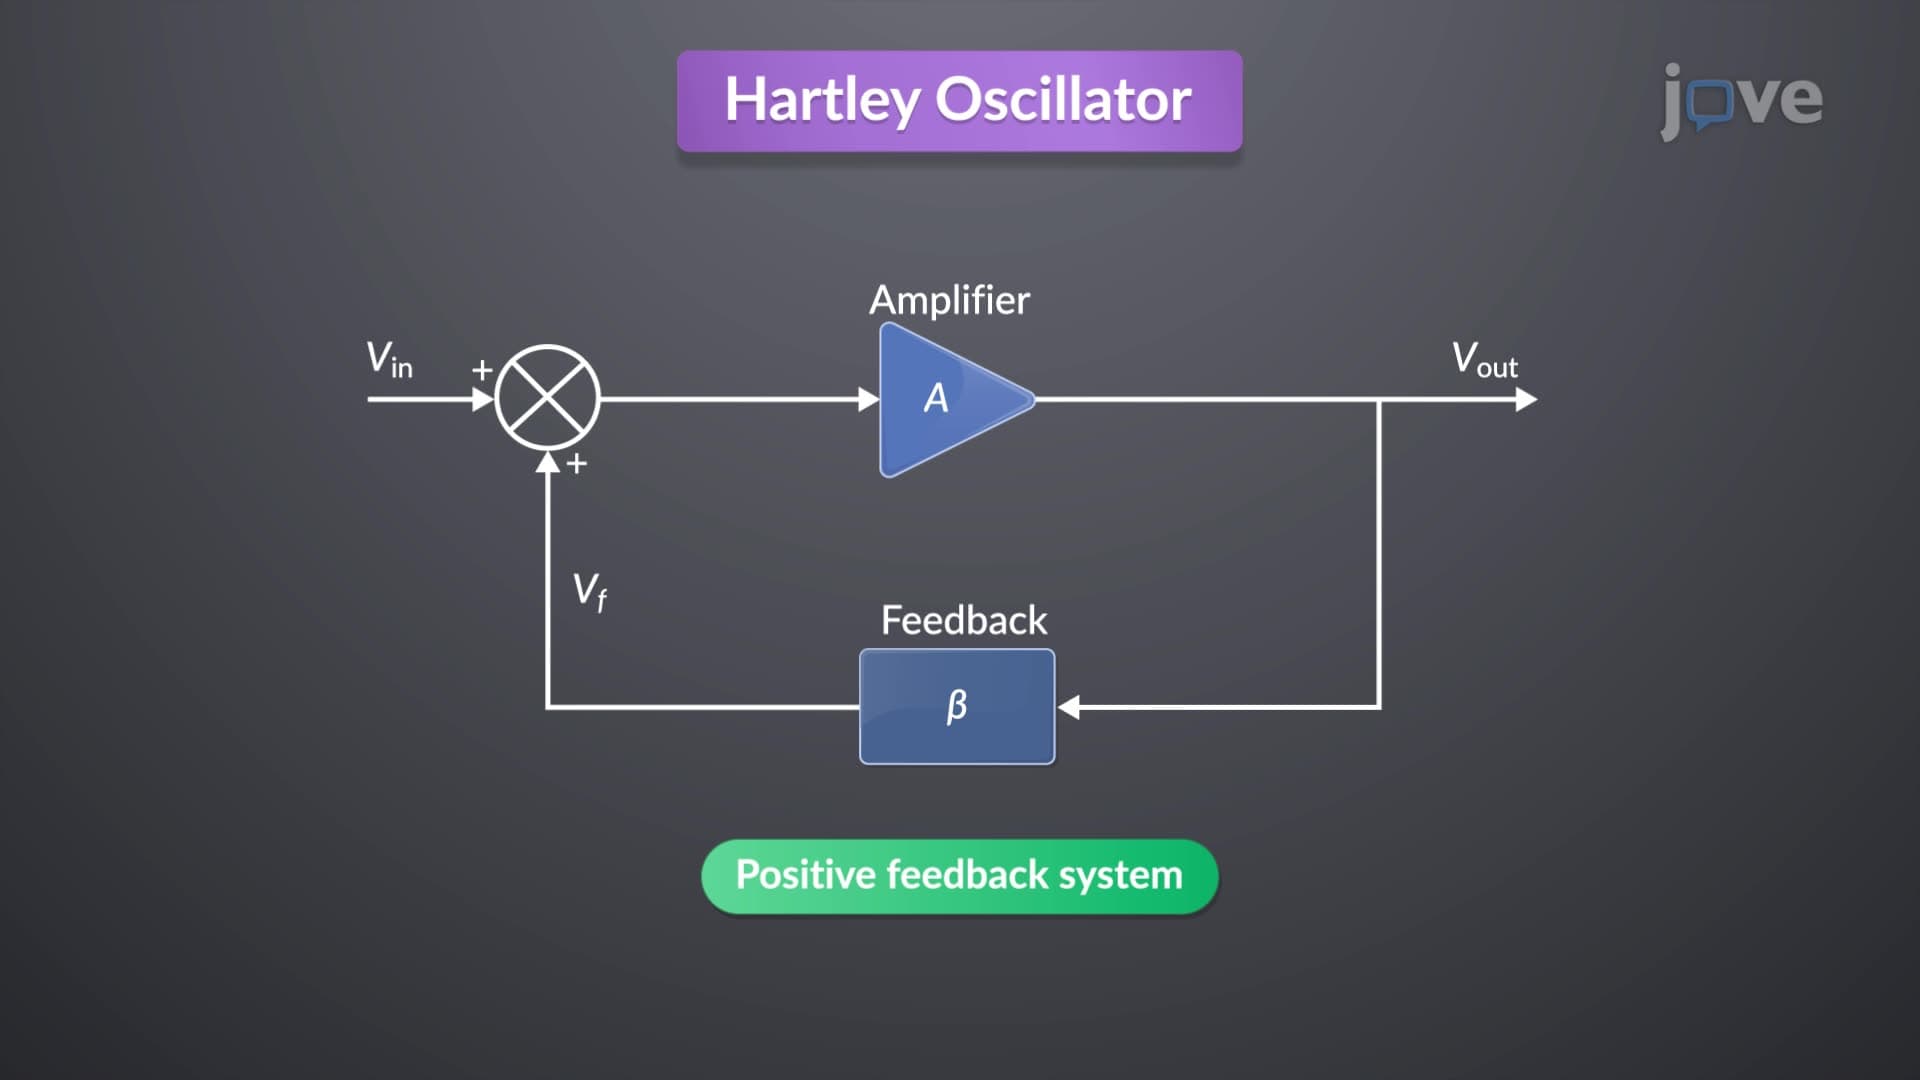
Root Loci for Positive-Feedback Systems
The construction rules for the root locus in positive feedback systems are similar to those in...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:15
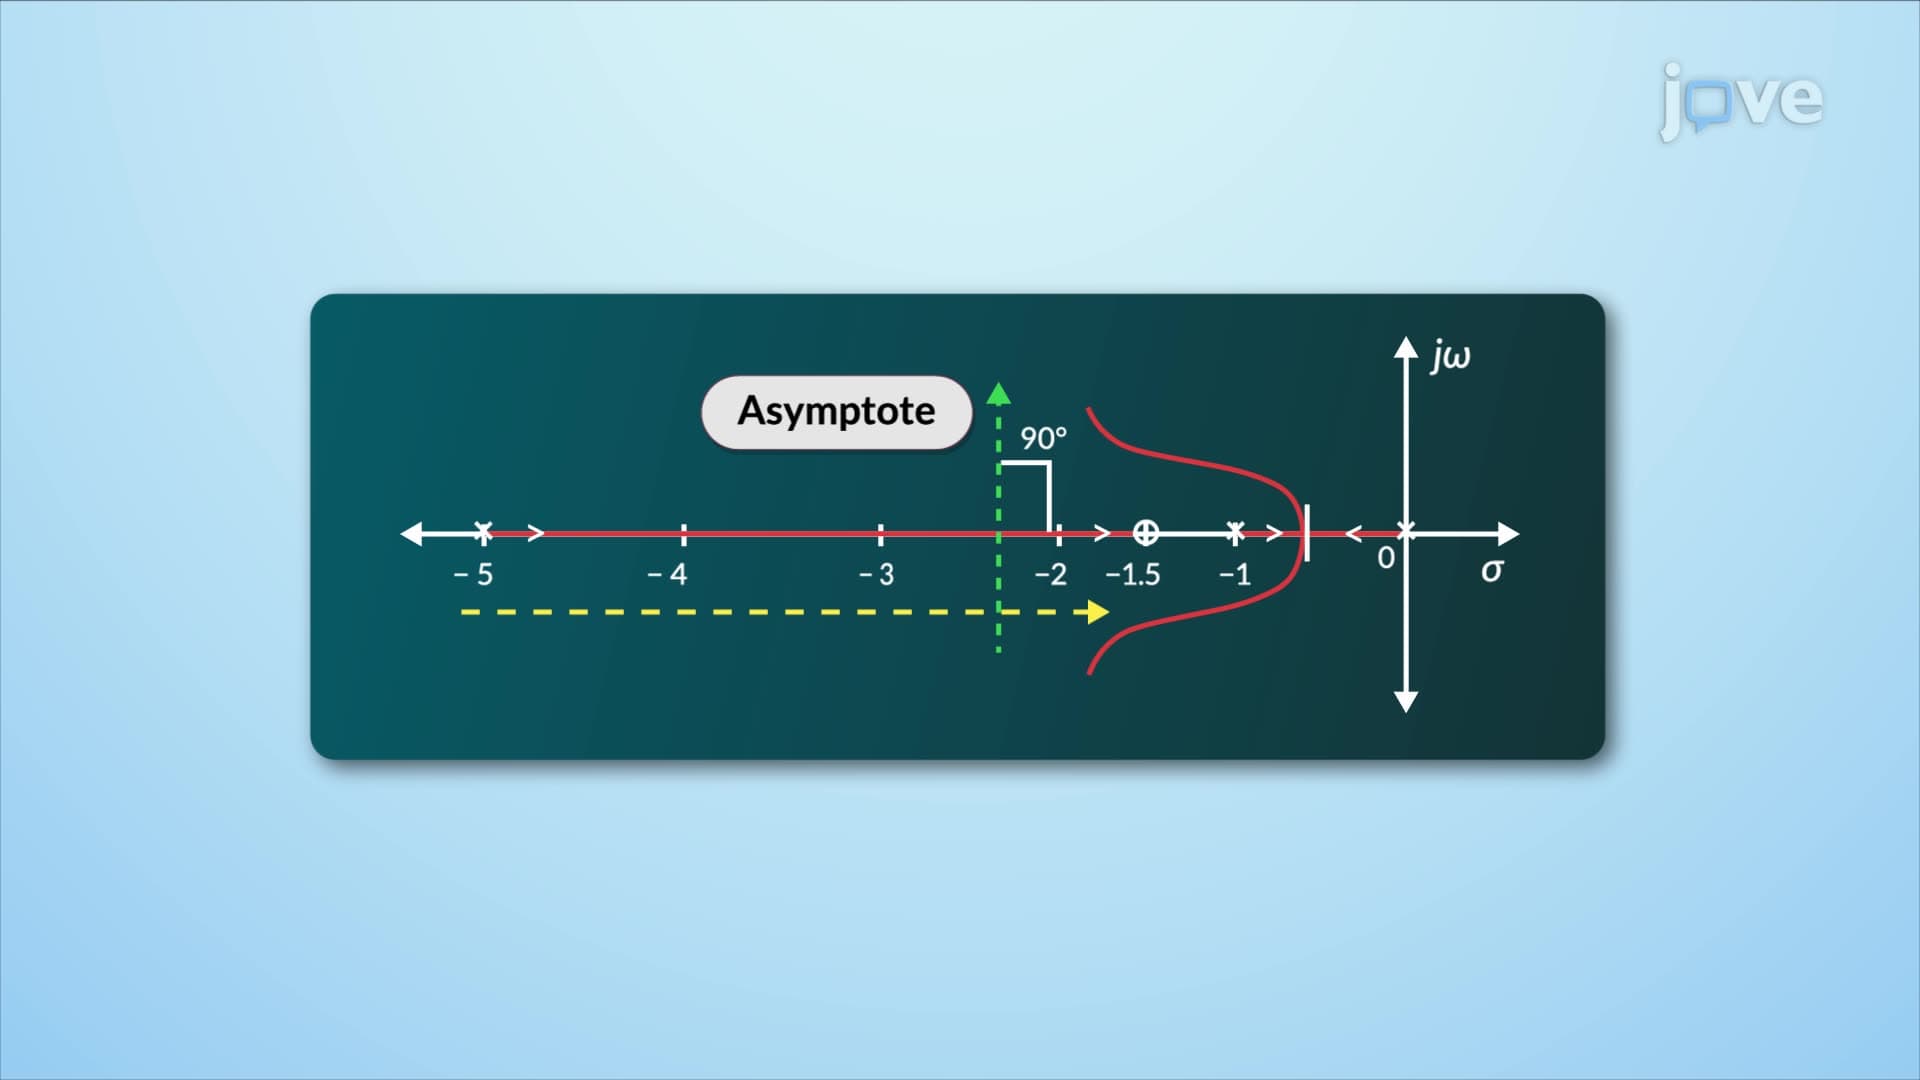
Construction of Root Locus
For positive gain values, the root locus exists on the real axis to the left of an odd number of finite open-loop poles or zeros. The root locus starts at the open-loop poles and traces the paths of the closed-loop poles as the gain...
 01:26
Transmission-Line Differential Equations
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...