Related Experiment Video
Updated: Oct 17, 2025

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Data-Driven Finite-Horizon H∞ Tracking Control With Event-Triggered Mechanism for the Continuous-Time Nonlinear

Abstract:
In this article, the neural network (NN)-based adaptive dynamic programming (ADP) event-triggered control method is presented to obtain the near-optimal control policy for the model-free finite-horizon H∞ optimal tracking control problem with constrained control input. First, using available input-output data, a data-driven model is established by a recurrent NN (RNN) to reconstruct the unknown system. Then, an augmented system with event-triggered mechanism is obtained by a tracking error system and a command generator. We present a novel event-triggering condition without Zeno behavior. On this basis, the relationship between event-triggered Hamilton-Jacobi-Isaacs (HJI) equation and time-triggered HJI equation is given in Theorem 3. Since the solution of the HJI equation is time-dependent for the augmented system, the time-dependent activation functions of NNs are considered. Moreover, an extra error is incorporated to satisfy the terminal constraints of cost function. This adaptive control pattern finds, in real time, approximations of the optimal value while also ensuring the uniform ultimate boundedness of the closed-loop system. Finally, the effectiveness of the proposed near-optimal control pattern is verified by two simulation examples.
More Related Videos
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
 10:51
An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:11
Sampling Continuous Time Signal
In the...
 01:21
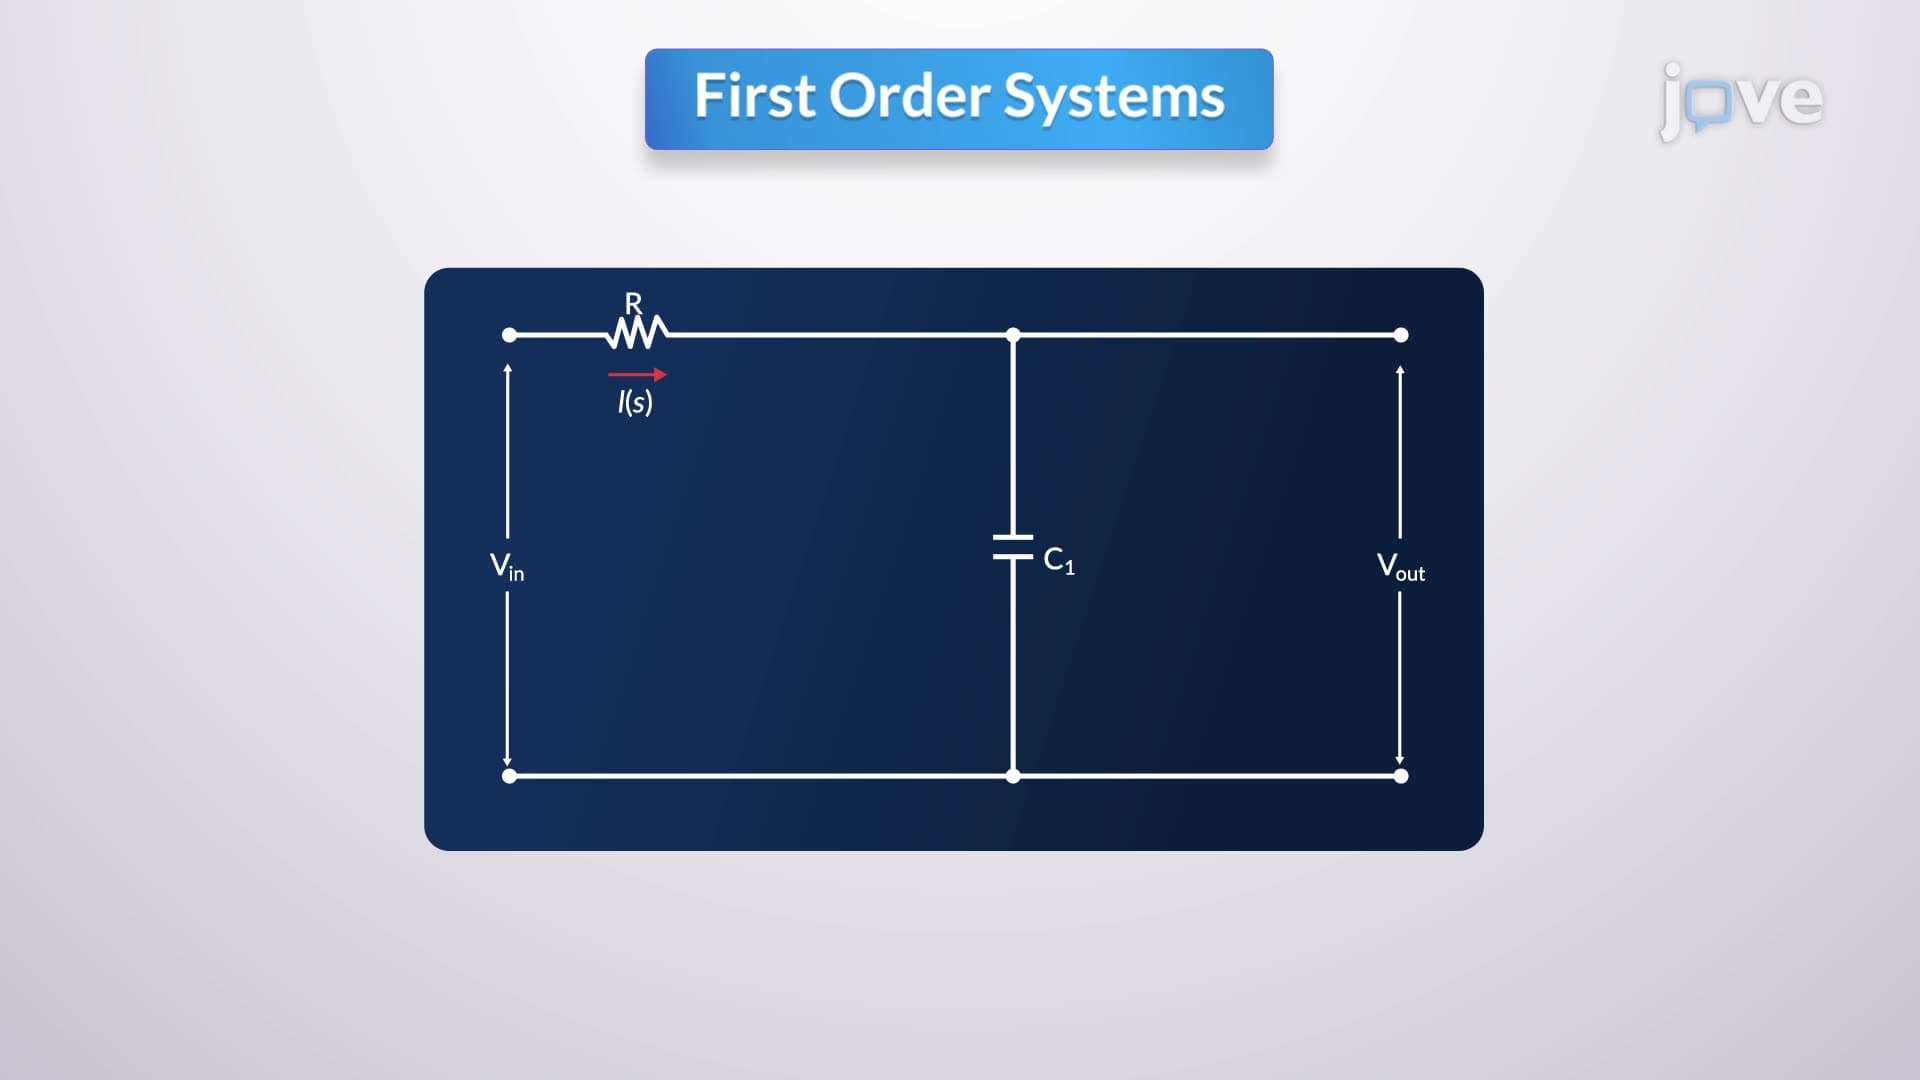
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...