Related Experiment Video
Updated: Oct 17, 2025
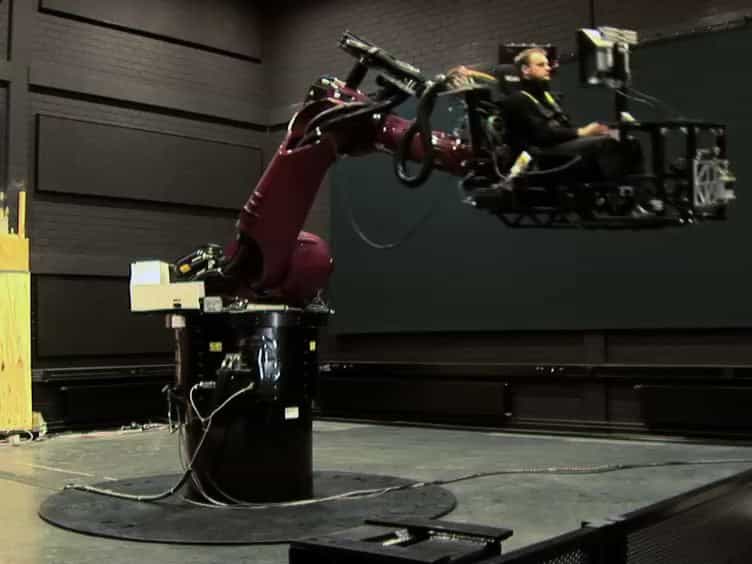

MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Semantics Aware Dynamic SLAM Based on 3D MODT
Muhammad Sualeh1, Gon-Woo Kim1
1Intelligent Robotics Laboratory, Control and Robotics Engineering Department, Chungbuk National University, Cheongju 28644, Chungbuk, Korea.

Abstract:
The idea of SLAM (Simultaneous Localization and Mapping) being a solved problem revolves around the static world assumption, even though autonomous systems are gaining environmental perception capabilities by exploiting the advances in computer vision and data-driven approaches. The computational demands and time complexities remain the main impediment in the effective fusion of the paradigms. In this paper, a framework to solve the dynamic SLAM problem is proposed. The dynamic regions of the scene are handled by making use of Visual-LiDAR based MODT (Multiple Object Detection and Tracking). Furthermore, minimal computational demands and real-time performance are ensured. The framework is tested on the KITTI Datasets and evaluated against the publicly available evaluation tools for a fair comparison with state-of-the-art SLAM algorithms. The results suggest that the proposed dynamic SLAM framework can perform in real-time with budgeted computational resources. In addition, the fused MODT provides rich semantic information that can be readily integrated into SLAM.
Related Concept Videos
 01:10
Relative Motion Analysis - Acceleration
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Three-Dimensional Force System
 01:12
Modeling and Similitude
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:05
Collisions in Multiple Dimensions: Introduction