Related Experiment Video
Updated: Oct 17, 2025
Author Spotlight: Automated Deep Brain Stimulation for Parkinson's Disease - Exploring the Possibilities and Challenges of Home Monitoring
Published on: July 14, 2023
Maximum Sum of Evidence-An Evidence-Based Solution to Object Pose Estimation in Point Cloud Data
Tyson Phillips1, Tim D'Adamo1, Peter McAree1
1School of Mechanical and Mining Engineering, The University of Queensland, Brisbane, QLD 4072, Australia.

Abstract:
The capability to estimate the pose of known geometry from point cloud data is a frequently arising requirement in robotics and automation applications. This problem is directly addressed by Iterative Closest Point (ICP), however, this method has several limitations and lacks robustness. This paper makes the case for an alternative method that seeks to find the most likely solution based on available evidence. Specifically, an evidence-based metric is described that seeks to find the pose of the object that would maximise the conditional likelihood of reproducing the observed range measurements. A seedless search heuristic is also provided to find the most likely pose estimate in light of these measurements. The method is demonstrated to provide for pose estimation (2D and 3D shape poses as well as joint-space searches), object identification/classification, and platform localisation. Furthermore, the method is shown to be robust in cluttered or non-segmented point cloud data as well as being robust to measurement uncertainty and extrinsic sensor calibration.

Related Concept Videos
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:03
Centroid of a Body: Problem Solving
The x-coordinates and y-coordinates of each element's...
 00:49
Rigid Body Equilibrium Problems - I
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:20
Calibration Curves: Linear Least Squares
For data that follow a straight line, the standard method for fitting is the linear...
 01:30
Principle of Moments: Problem Solving
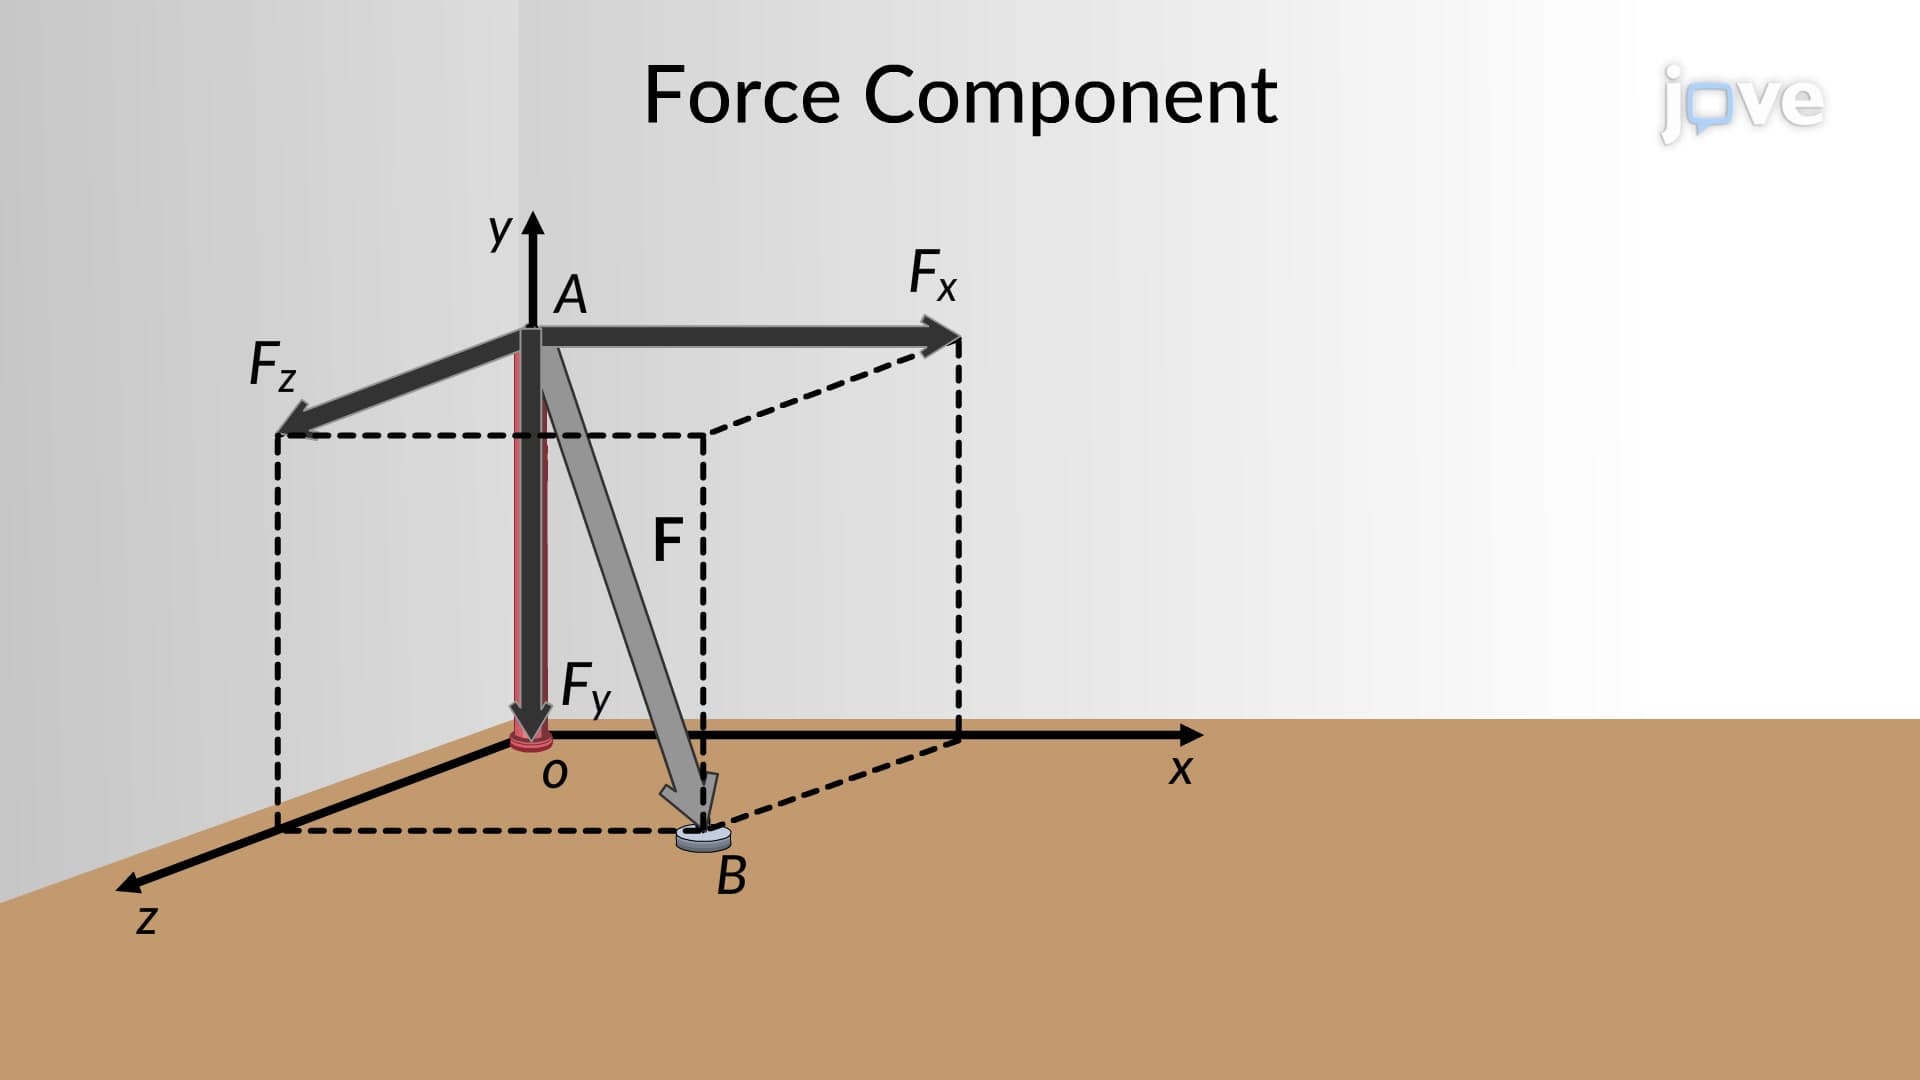
One such scenario involves a pole placed in a three-dimensional system with a cable attached. When a tension is applied to the cable, the moment about the z-axis passing through...