Open source Vicon Toolkit for motion capture and Gait Analysis
Related Experiment Video
Updated: Oct 16, 2025
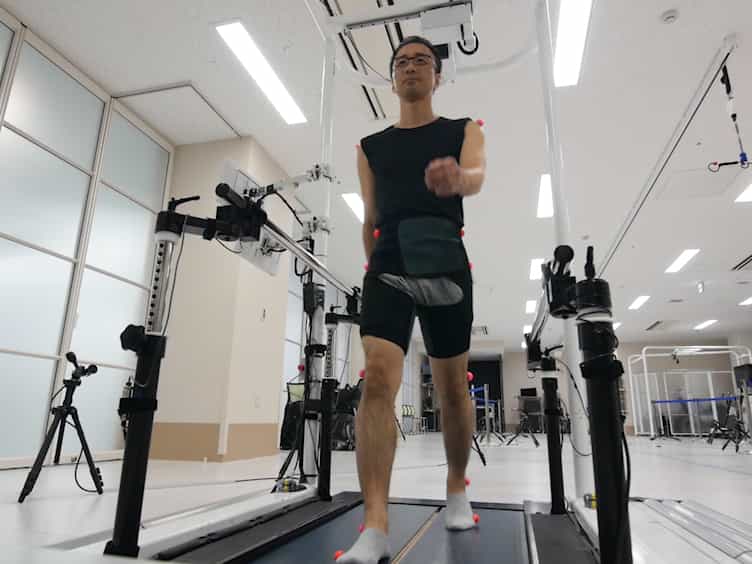
Clinical-oriented Three-dimensional Gait Analysis Method for Evaluating Gait Disorder
Published on: March 4, 2018
Nathaniel Goldfarb1, Alek Lewis2, Alex Tacescu1
1The Department of Robotics Engineering, Worcester Polytechnic Institute, 85 Prescott St, Worcester, MA 01609, United States.

Background And Objective:
The Vicon motion capture system is a popular tool for biomechanics, gait analysis, and robotics. The ASCII files produced are large and complex, making them difficult to read and analyze.
Methods:
This paper presents two packages, the Vicon Toolkit Package and the Gait Analysis Toolkit Package. They use an open-source framework for ingesting, parsing, and analyzing Vicon mocap data and performing gait analysis. The package that handles the Vicon analysis is separated from the Gait Analysis package to allow for abstraction and expansion, and is not specific only to the Vicon system.
Results:
Our Vicon Toolkit provides tools to work directly with the marker data and other Vicon Nexus system outputs. The Gait Toolkit provides tools for performing gait analysis, EMG filtering, and learning trajectories. The packages are built upon a core library, GaitCore, that provides unified objects to perform operations and store data.
Conclusion:
This paper will show how to use the packages' tools and the expected outputs. All the tools are open-source and written in Python3.x for ease of use and access to other powerful libraries.
Related Concept Videos
 01:15
Torque Free Motion
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:17
Central-Force Motion