Related Experiment Video
Updated: Oct 16, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
A trajectory-based loss function to learn missing terms in bifurcating dynamical systems
Rahel Vortmeyer-Kley1, Pascal Nieters2, Gordon Pipa2
1Institute of Cognitive Science, Osnabrück University, Wachsbleiche 27, 49090, Osnabrück, Germany. rahel.vortmeyer-kley@uni-osnabrueck.de.

Abstract:
Missing terms in dynamical systems are a challenging problem for modeling. Recent developments in the combination of machine learning and dynamical system theory open possibilities for a solution. We show how physics-informed differential equations and machine learning-combined in the Universal Differential Equation (UDE) framework by Rackauckas et al.-can be modified to discover missing terms in systems that undergo sudden fundamental changes in their dynamical behavior called bifurcations. With this we enable the application of the UDE approach to a wider class of problems which are common in many real world applications. The choice of the loss function, which compares the training data trajectory in state space and the current estimated solution trajectory of the UDE to optimize the solution, plays a crucial role within this approach. The Mean Square Error as loss function contains the risk of a reconstruction which completely misses the dynamical behavior of the training data. By contrast, our suggested trajectory-based loss function which optimizes two largely independent components, the length and angle of state space vectors of the training data, performs reliable well in examples of systems from neuroscience, chemistry and biology showing Saddle-Node, Pitchfork, Hopf and Period-doubling bifurcations.

Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:26
Transmission-Line Differential Equations
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:22
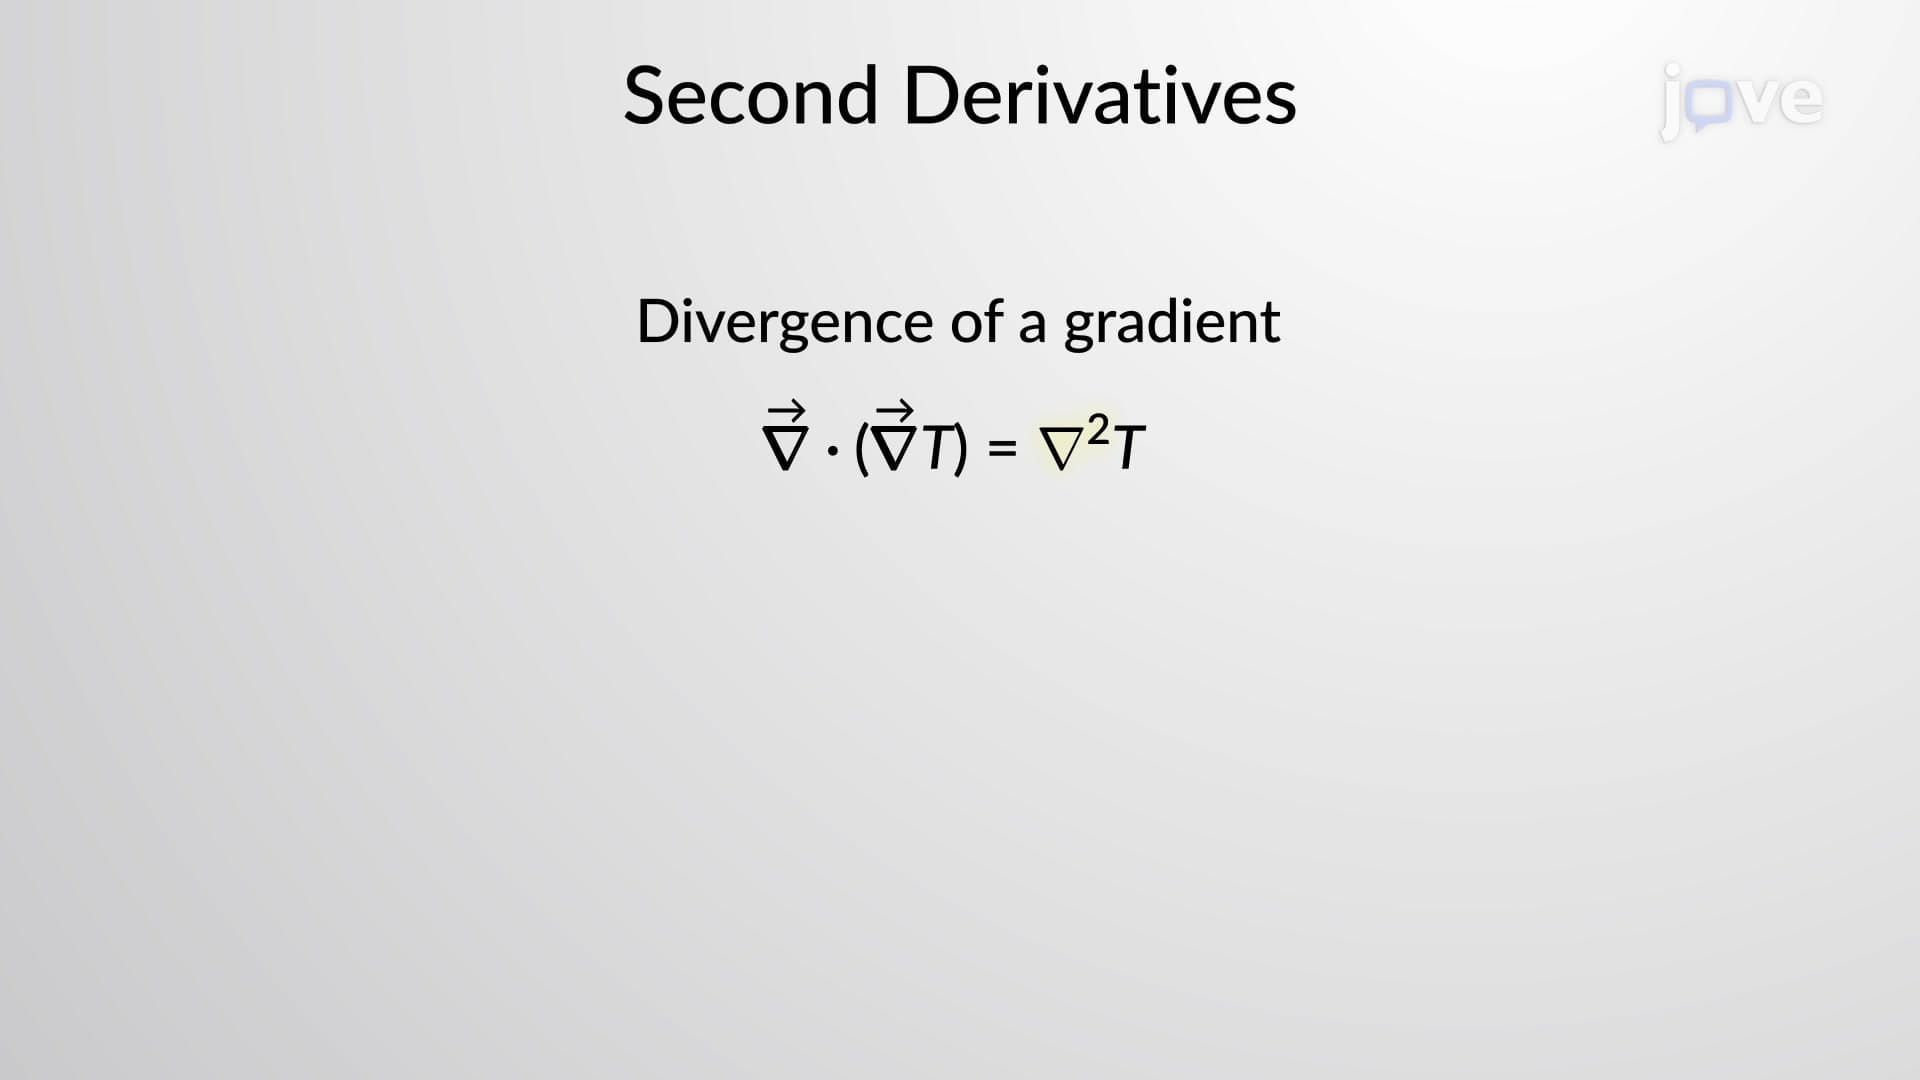
Second Derivatives and Laplace Operator
Consider a scalar function. The curl of its...
 01:18
Second Order systems II
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....