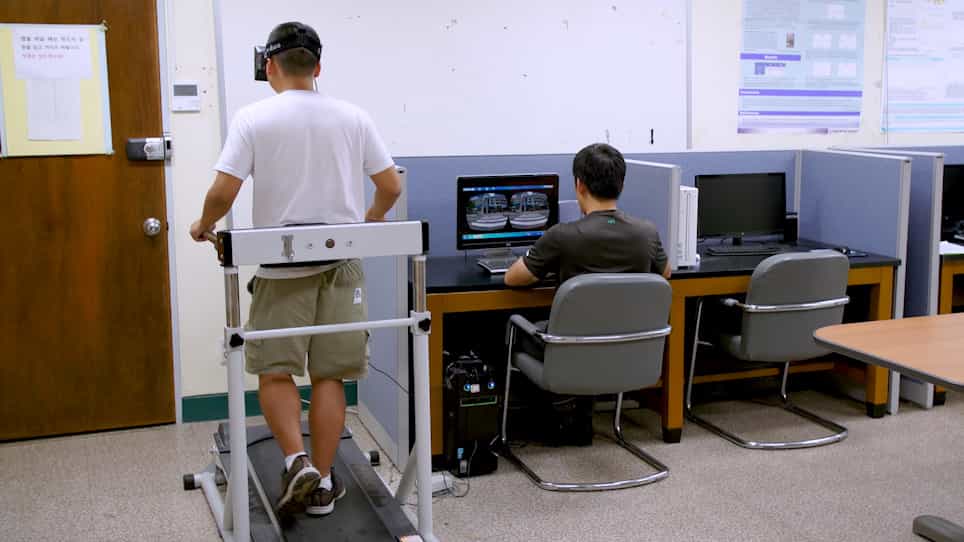
Related Experiment Video
Updated: Oct 16, 2025


Trajectory Data Analyses for Pedestrian Space-time Activity Study
Published on: February 25, 2013
Understanding Private Car Aggregation Effect via Spatio-Temporal Analysis of Trajectory Data

Abstract:
Understanding the private car aggregation effect is conducive to a broad range of applications, from intelligent transportation management to urban planning. However, this work is challenging, especially on weekends, due to the inefficient representations of spatiotemporal features for such aggregation effect and the considerable randomness of private car mobility on weekends. In this article, we propose a deep learning framework for a spatiotemporal attention network (STANet) with a neural algorithm logic unit (NALU), the so-called STANet-NALU, to understand the dynamic aggregation effect of private cars on weekends. Specifically: 1) we design an improved kernel density estimator (KDE) by defining a log-cosh loss function to calculate the spatial distribution of the aggregation effect with guaranteed robustness and 2) we utilize the stay time of private cars as a temporal feature to represent the nonlinear temporal correlation of the aggregation effect. Next, we propose a spatiotemporal attention module that separately captures the dynamic spatial correlation and nonlinear temporal correlation of the private car aggregation effect, and then we design a gate control unit to fuse spatiotemporal features adaptively. Further, we establish the STANet-NALU structure, which provides the model with numerical extrapolation ability to generate promising prediction results of the private car aggregation effect on weekends. We conduct extensive experiments based on real-world private car trajectories data. The results reveal that the proposed STANet-NALU outperforms the well-known existing methods in terms of various metrics, including the mean absolute error (MAE), root mean square error (RMSE), Kullback-Leibler divergence (KL), and R2.

Related Concept Videos
 01:41
Social Traps
 01:27
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:10
Relative Motion Analysis - Acceleration
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:15
Scatter Plot
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...