Related Experiment Video
Updated: Oct 16, 2025

An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
Robust Tracking Control of the Euler-Lagrange System Based on Barrier Lyapunov Function and Self-Structuring Neural
Yi Wang1, He Ma1, Weidong Wu2
1College of Medicine and Biological Information Engineering, Northeastern University, Shenyang 110016, China.

Abstract:
This article studies the robust tracking control problems of Euler-Lagrange (EL) systems with uncertainties. To enhance the robustness of the control systems, an asymmetric tan-type barrier Lyapunov function (ATBLF) is used to dynamic constraint position tracking errors. To deal with the problems of the system uncertainties, the self-structuring neural network (SSNN) is developed to estimate the unknown dynamics model and avoid the calculation burden. The robust compensator is designed to estimate and compensate neural network (NN) approximation errors and unknown disturbances. In addition, a relative threshold event-triggered strategy is introduced, which greatly saves communication resources. Under the proposed robust control scheme, tracking behavior can be implemented with disturbance and unknown dynamics of the EL systems. All signals in the closed-loop system are proved to be bounded by stability analysis, and the tracking error can converge to the neighborhood near the origin. The numerical simulation results show the effectiveness and the validity of the proposed robust control scheme.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 08:18
WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:10
Control Systems
At the heart...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:19
Root-Locus Method
This system can be represented by a block...
 01:19
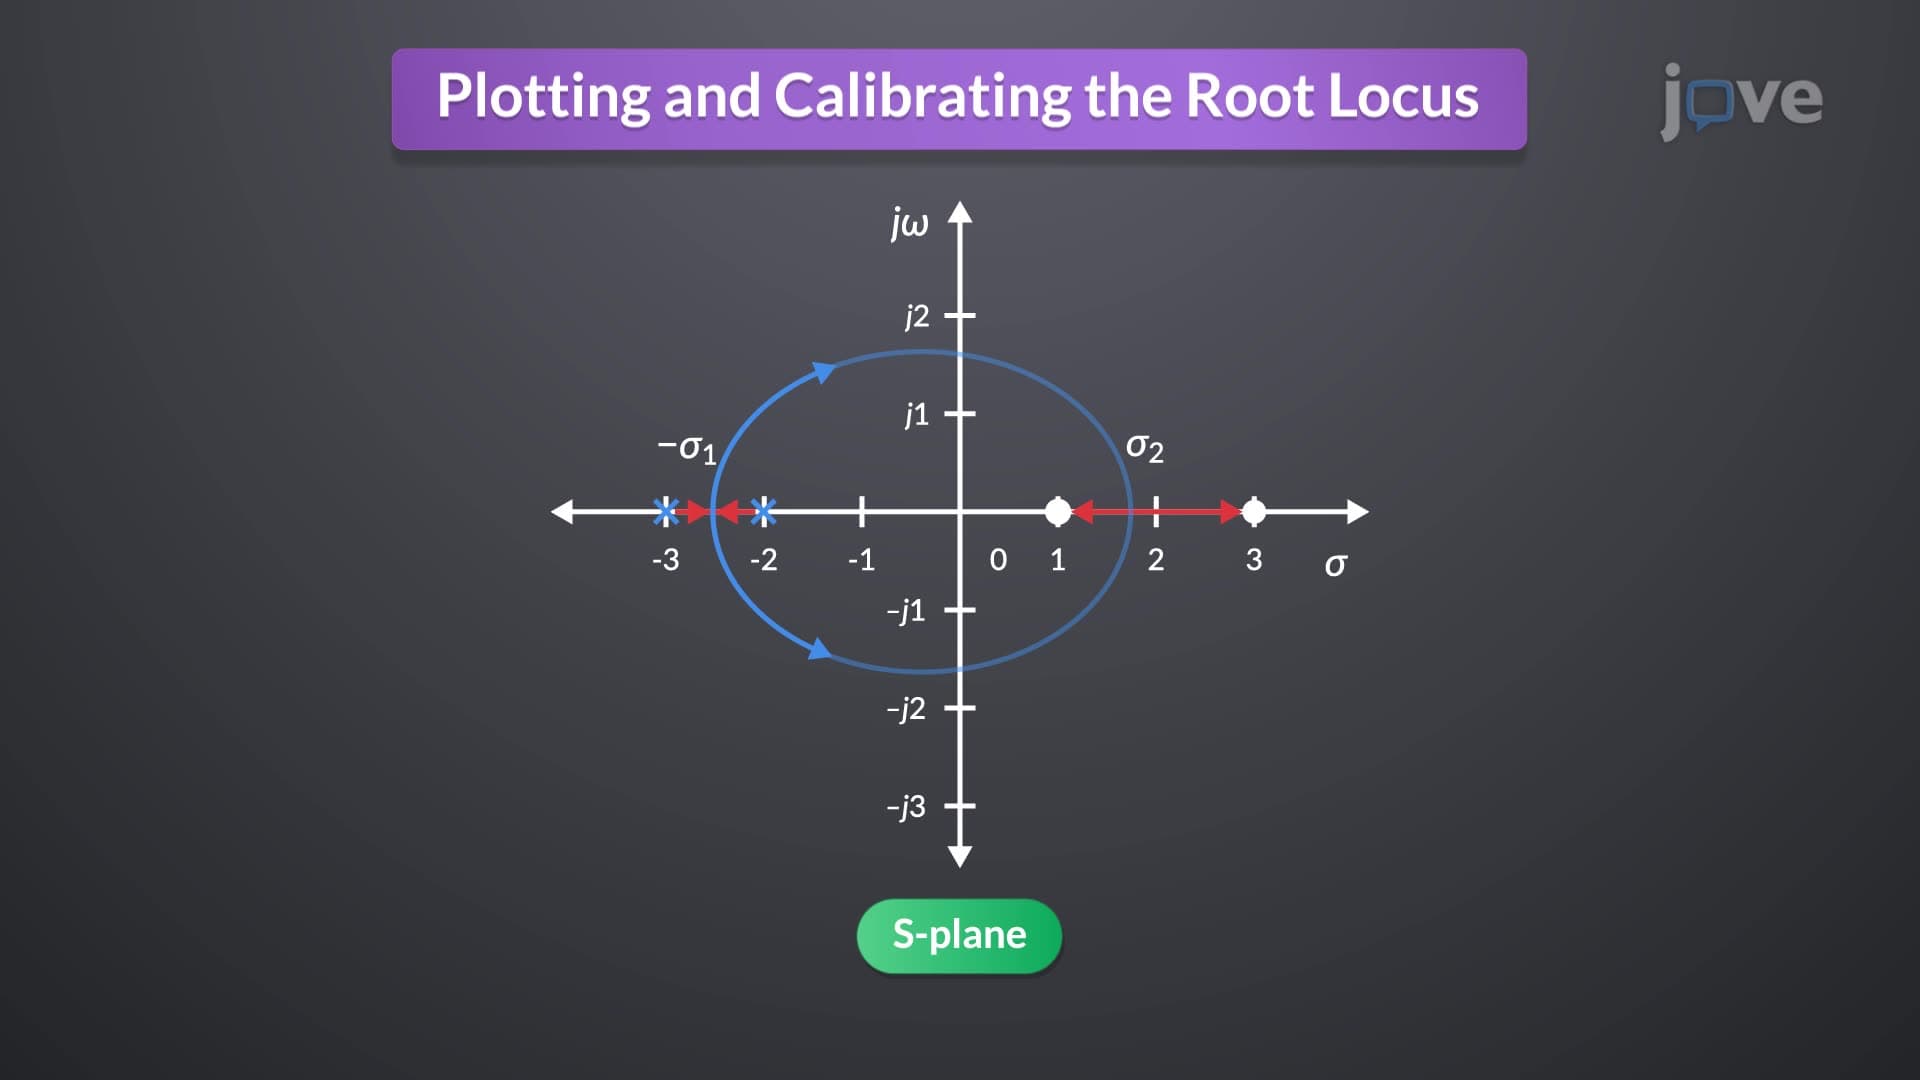
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...