Related Experiment Video
Updated: Oct 15, 2025

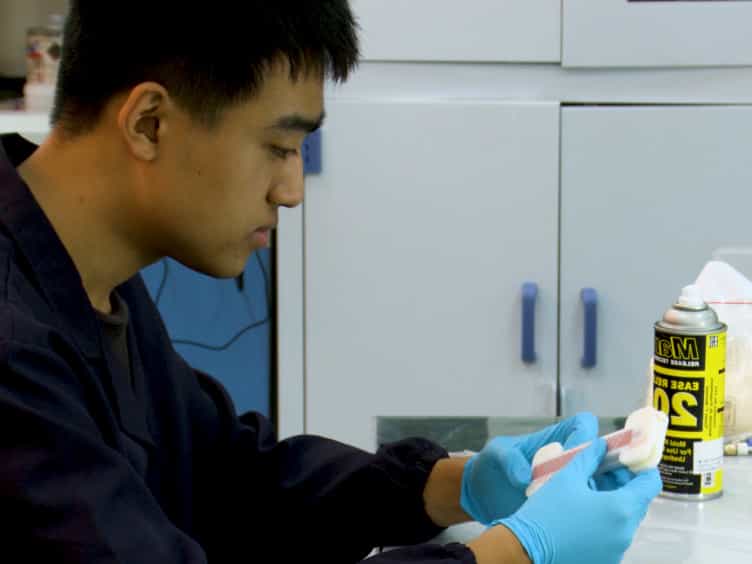
Rod-based Fabrication of Customizable Soft Robotic Pneumatic Gripper Devices for Delicate Tissue Manipulation
Published on: August 2, 2016
Three-Fingered Soft Pneumatic Gripper Integrating Joint-Tuning Capability
Lei Liu1, Junshi Zhang2, Geng Liu1
1School of Mechanical and Precision Instrument Engineering, Xi'an University of Technology, Xi'an, China.

Abstract:
Compared with traditional rigid grippers, soft grippers are made of lightweight and soft materials and have the characteristics of flexible contact and strong adaptability, which are widely utilized to grasp fragile objects with complex contours and shapes. In this article, we design and fabricate a three-fingered stiffness-tunable soft gripper by integrating the joint-tuning capability. The soft fingers are composed of an internal bending actuator and an external fiber-jamming jacket, under an actuation of pneumatic pressure. Static and kinematic models are established to detect the bending angle and end trajectory of the internal bending actuator. Meanwhile, the bending angle and blocking force of bending actuator are experimentally measured and are comparably analyzed with the theoretical predictions. Jamming pressure is applied in the stiffness-tunable jacket to explore the variable stiffness and load-carrying capability of the soft finger. By incorporating the stiffness-tunable property, the grasping performance of various weights and types of goods, as well as the maximum grasping force of the soft gripper, is investigated. Finally, by patterning the stiffness-tunable jacket on the bending actuator, the variable curvature bending deformation and joint-tuning capability of the soft finger are achieved. This proposed soft gripper holds great potential applications in soft robotics community.

Related Concept Videos
 01:30
Three-Dimensional Force System
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 01:07
Development of the Limb Synovial Joints
The mesenchymal stem cells differentiate into chondrocytes that form the hyaline cartilage, and later the cartilaginous model of the bone. This model further transforms into a bone. This process is known as endochondral ossification.
During development, the limbs...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:22
Mechanical Systems
 01:17
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi...