Related Experiment Video
Updated: Oct 15, 2025

Author Spotlight: Unlocking New Insights in fNIRS Studies - A Novel Framework for Inter-Brain Synchrony Analysis
Published on: October 6, 2023
Overlapped speech detection using phase features
Shikha Baghel1, S R Mahadeva Prasanna2, Prithwijit Guha1
1Department of Electronics and Electrical Engineering, Indian Institute of Technology Guwahati, Guwahati-781039, India.

Abstract:
Simultaneous speech of multiple speakers is known as overlapped speech, which causes problems for speech recognition and speaker diarization systems. The present work uses previously less utilized signal phase information in the task of overlapped speech detection. In this context, Instantaneous Frequency Cosine Coefficient (IFCC) and Modified Group Delay Cepstral Coefficient (MGDCC) features are explored. IFCC captures the time-varying phase characteristics, while MGDCC represents the frequency-varying information of the phase spectrum. A Convolutional Neural Network and Long Short-Term Memory (CNN-LSTM)-based classifier is used for the classification. The present work uses synthetically generated overlapped speech from the GRID corpus. The proposed method is benchmarked against three baseline approaches that use magnitude spectrum features. It is observed that the combination of IFCC and MGDCC features with CNN-LSTM classifier provides better performance than the baselines. The combination of phase features with magnitude-based MFCC feature provides the best performance, indicating the importance of complementary information. The present study also investigates the effect of segment duration, genders, and number of simultaneous speakers on the overlapped speech detection system. Finally, the proposed method is also evaluated on real overlapped data from the AMI corpus.
More Related Videos
 09:09
Foreign Accent and Forensic Speaker Identification in Voice Lineups: The Influence of Acoustic Features Based on Prosody
Published on: September 27, 2024
 05:38
Interaction between Phonological and Semantic Processes in Visual Word Recognition using Electrophysiology
Published on: June 29, 2021
Related Concept Videos
 01:10
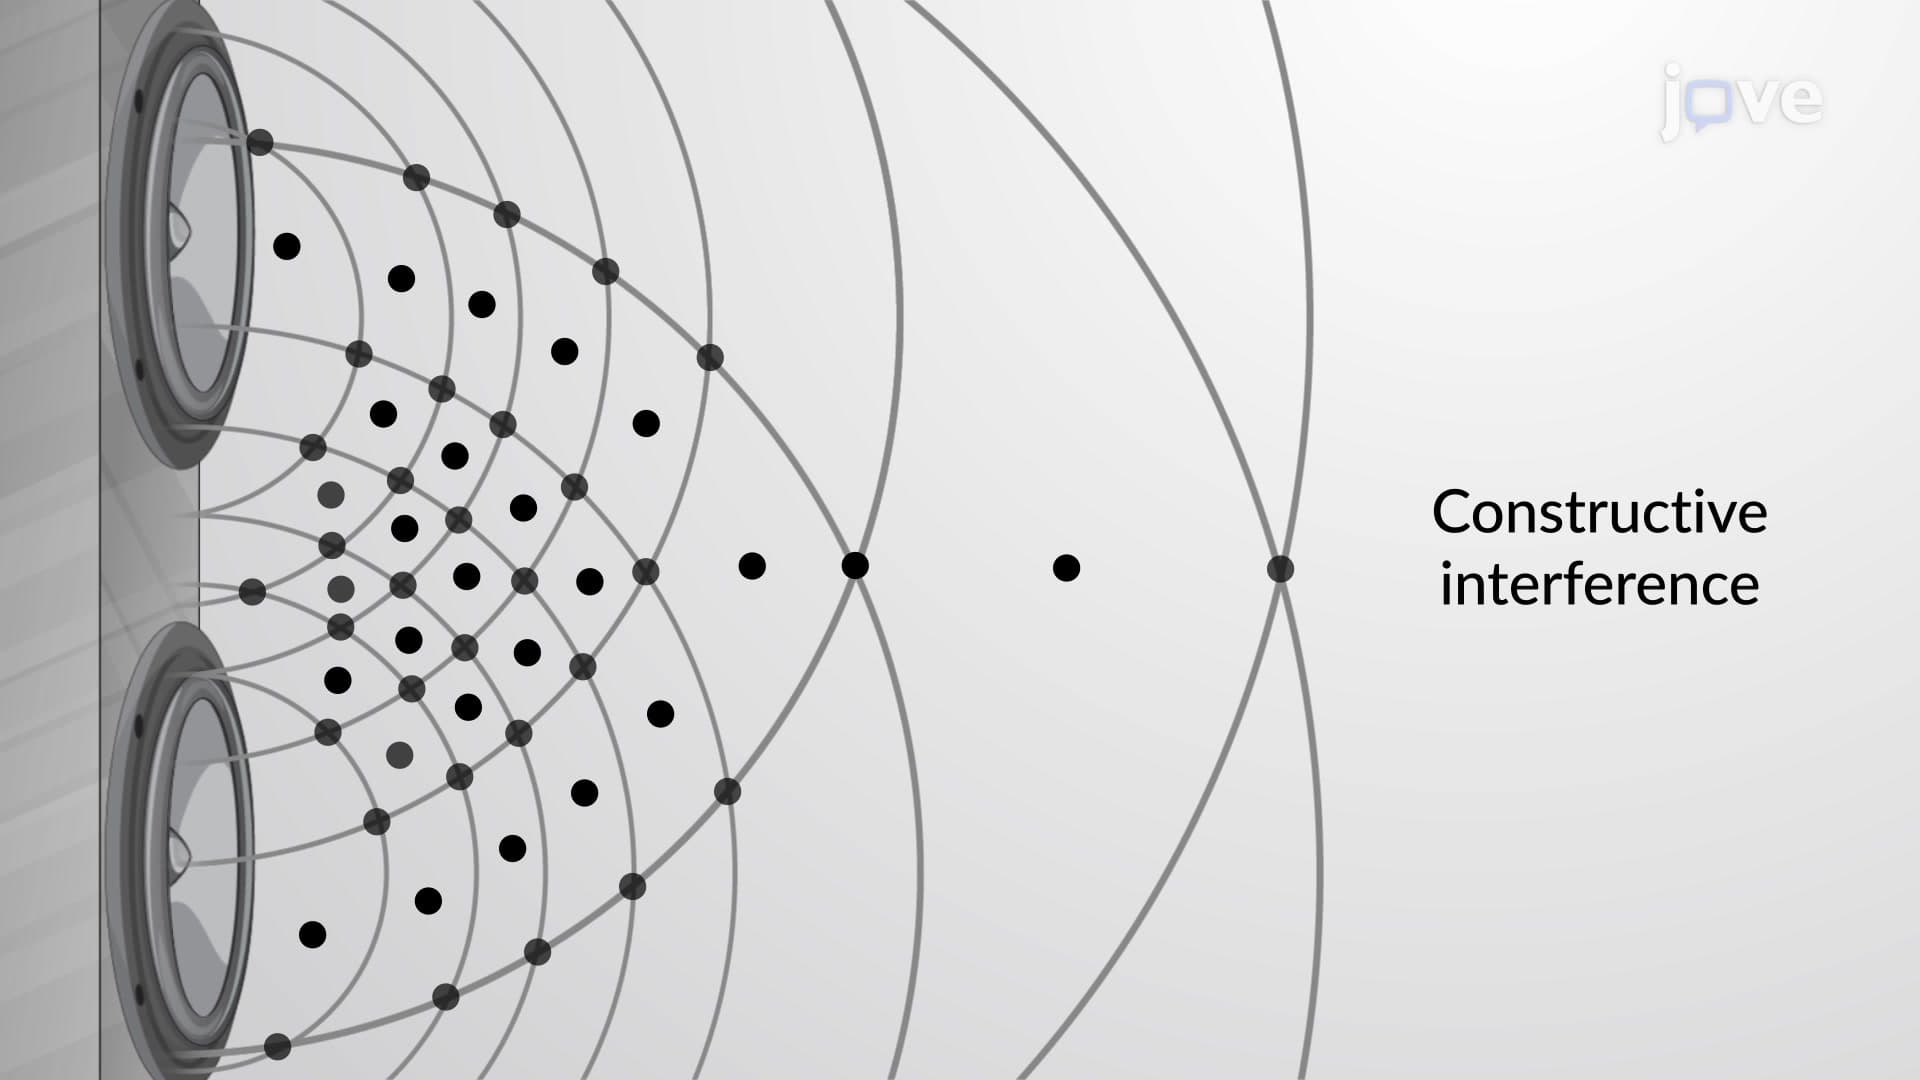
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...
 01:02
¹H NMR: Interpreting Distorted and Overlapping Signals
As Δν decreases and the signals move closer, the doublets appear increasingly distorted. The intensities of the inner lines increase at the cost of those of the outer lines as the signals are...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...
 01:24
Frequency-Domain Interpretation of PD Control
The proportional control gain, combined with the...