Behaviour Recognition with Kinodynamic Planning Over Continuous Domains
Related Experiment Video
Updated: Oct 13, 2025

Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
Grady Fitzpatrick1, Nir Lipovetzky1, Michael Papasimeon2
1The University of Melbourne, Parkville, VIC, Australia.

Abstract:
We investigate the application of state-of-the-art goal recognition techniques for behaviour recognition over complex continuous domains using model predictive control (MPC) for trajectory generation. We formally define the problem of kinodynamic behaviour recognition and establish a set of baseline behaviours and performance measures in the complex domain of unmanned aerial maneuvers. We evaluate how well our approach performs over a range of standard aerial maneuvers and representative initial configurations of varying complexity. The work also highlights future research directions in compound model-based behaviour recognition and team behaviour recognition where multiple agents may be acting simultaneously.

Related Concept Videos
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:15
Kinematic Equations: Problem Solving
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
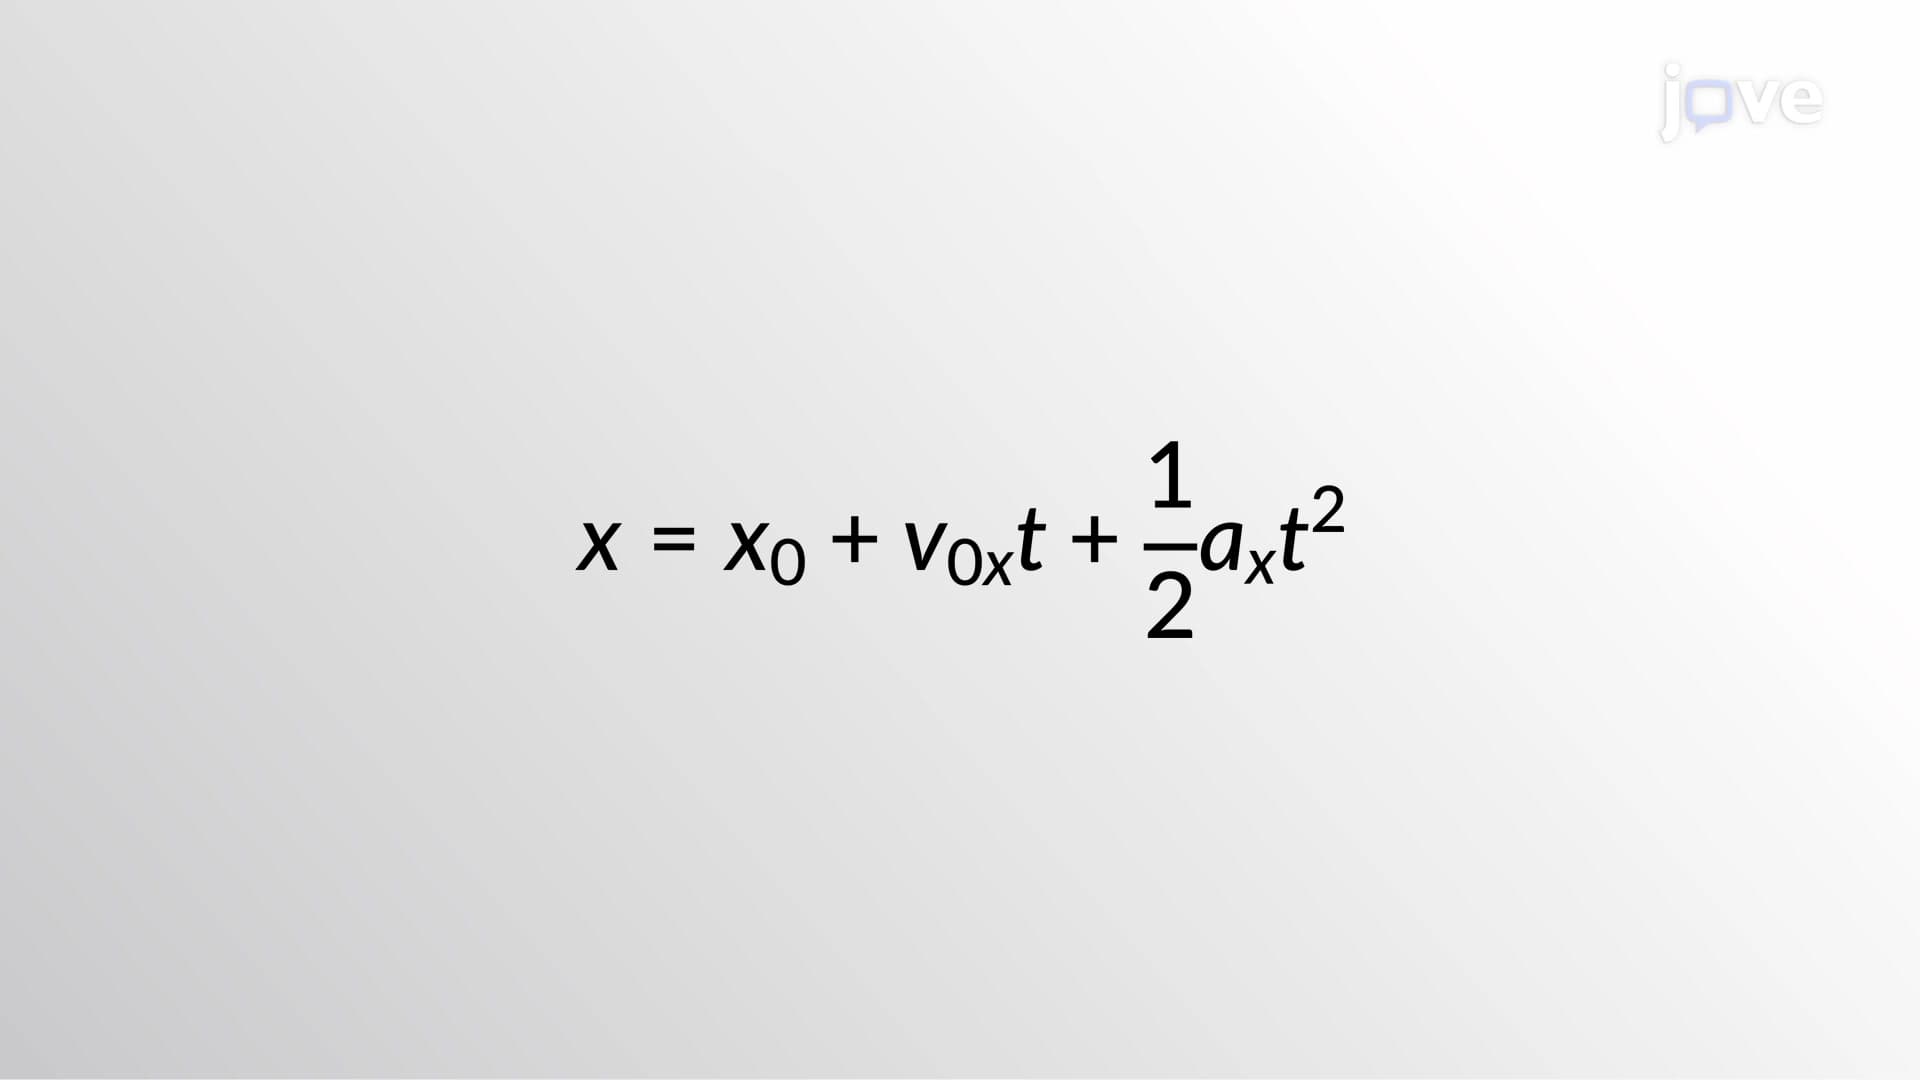 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...