Related Experiment Video
Updated: Oct 13, 2025
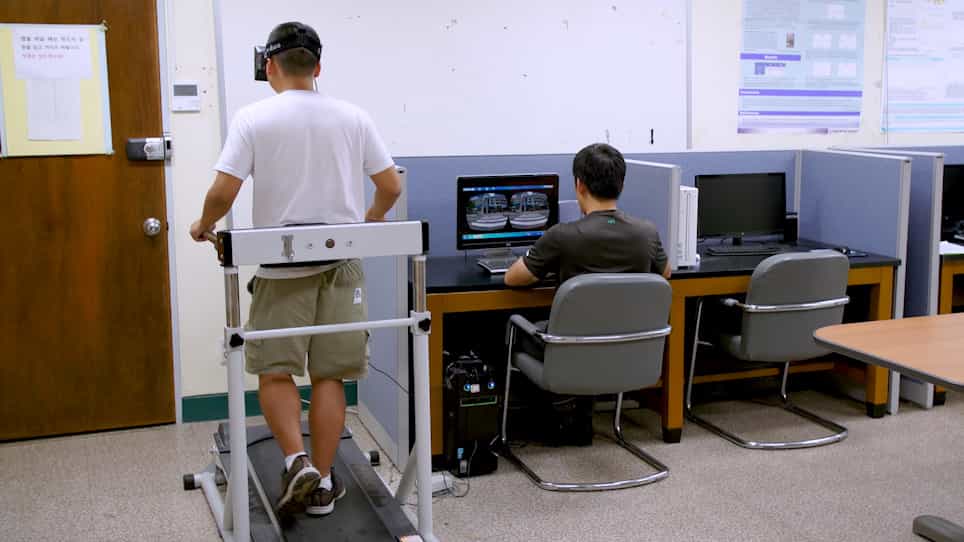

Using a Virtual Reality Walking Simulator to Investigate Pedestrian Behavior
Published on: June 9, 2020
Interactions between autonomous vehicles and pedestrians at unsignalized mid-block crosswalks considering occlusions
Hong Zhu1, Miho Iryo-Asano1, Wael K M Alhajyaseen2
1Department of Environmental Engineering and Architecture, Graduate School of Environmental Studies, Nagoya University, Nagoya 464-8603, Japan.

Abstract:
Visibility can be identified as one of the critical determinants for the safety performance of autonomous vehicles (AVs) on unsignalized mid-block crosswalks (UMC), which may be significantly influenced by build-up environment and surrounding vehicles. This study investigates the safety performance when AVs interact with pedestrians approaching from far-side sidewalks to UMCs considering the visual occlusion of opposing vehicles. A mathematical model is proposed for judging the visibilities of objects from observers' location under the impact of visual obstacles and is embedded into an agent-based pedestrian-vehicle interaction framework. Two yielding decision modules is assumed for AVs: The normal decision module implements the pedestrian priority rule simply based on the current detectable information, whereas the memory aid decision module extends AVs' detection abilities by incorporating the memory data. Through simulation experiments, it is found that the percentages of short post encroachment time (%SPET) between AVs and far-side pedestrians reach peaks when the pedestrian flow rate is 300-400 ped/h. When opposing vehicles are in stationary queue conditions, %SPETs are only sensitive to the net distance between the last opposing vehicles in the queue and crosswalks (Dqueue). As the Dqueue decreases to lower than 15 m, %SPETs start to increase drastically. However, when opposing vehicles are in free flow conditions, %SPETs are influenced by multiple factors such as pedestrians' crossing decisions, sizes and flow rates of opposing vehicles. Furthermore, only when opposing vehicles are in free flow conditions, memory aid AVs can significantly eliminate the impacts of opposite vehicles. Finally, several countermeasures are developed to enhance the visibility and safety at UMCs based on the findings of this study.


Related Concept Videos
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:05
Collisions in Multiple Dimensions: Introduction
 01:19
Types of Collisions - II
 01:10
Design Example: Measuring Distance Between Two Points with Obstructions
 01:15
Elastic Collisions: Case Study
 01:04
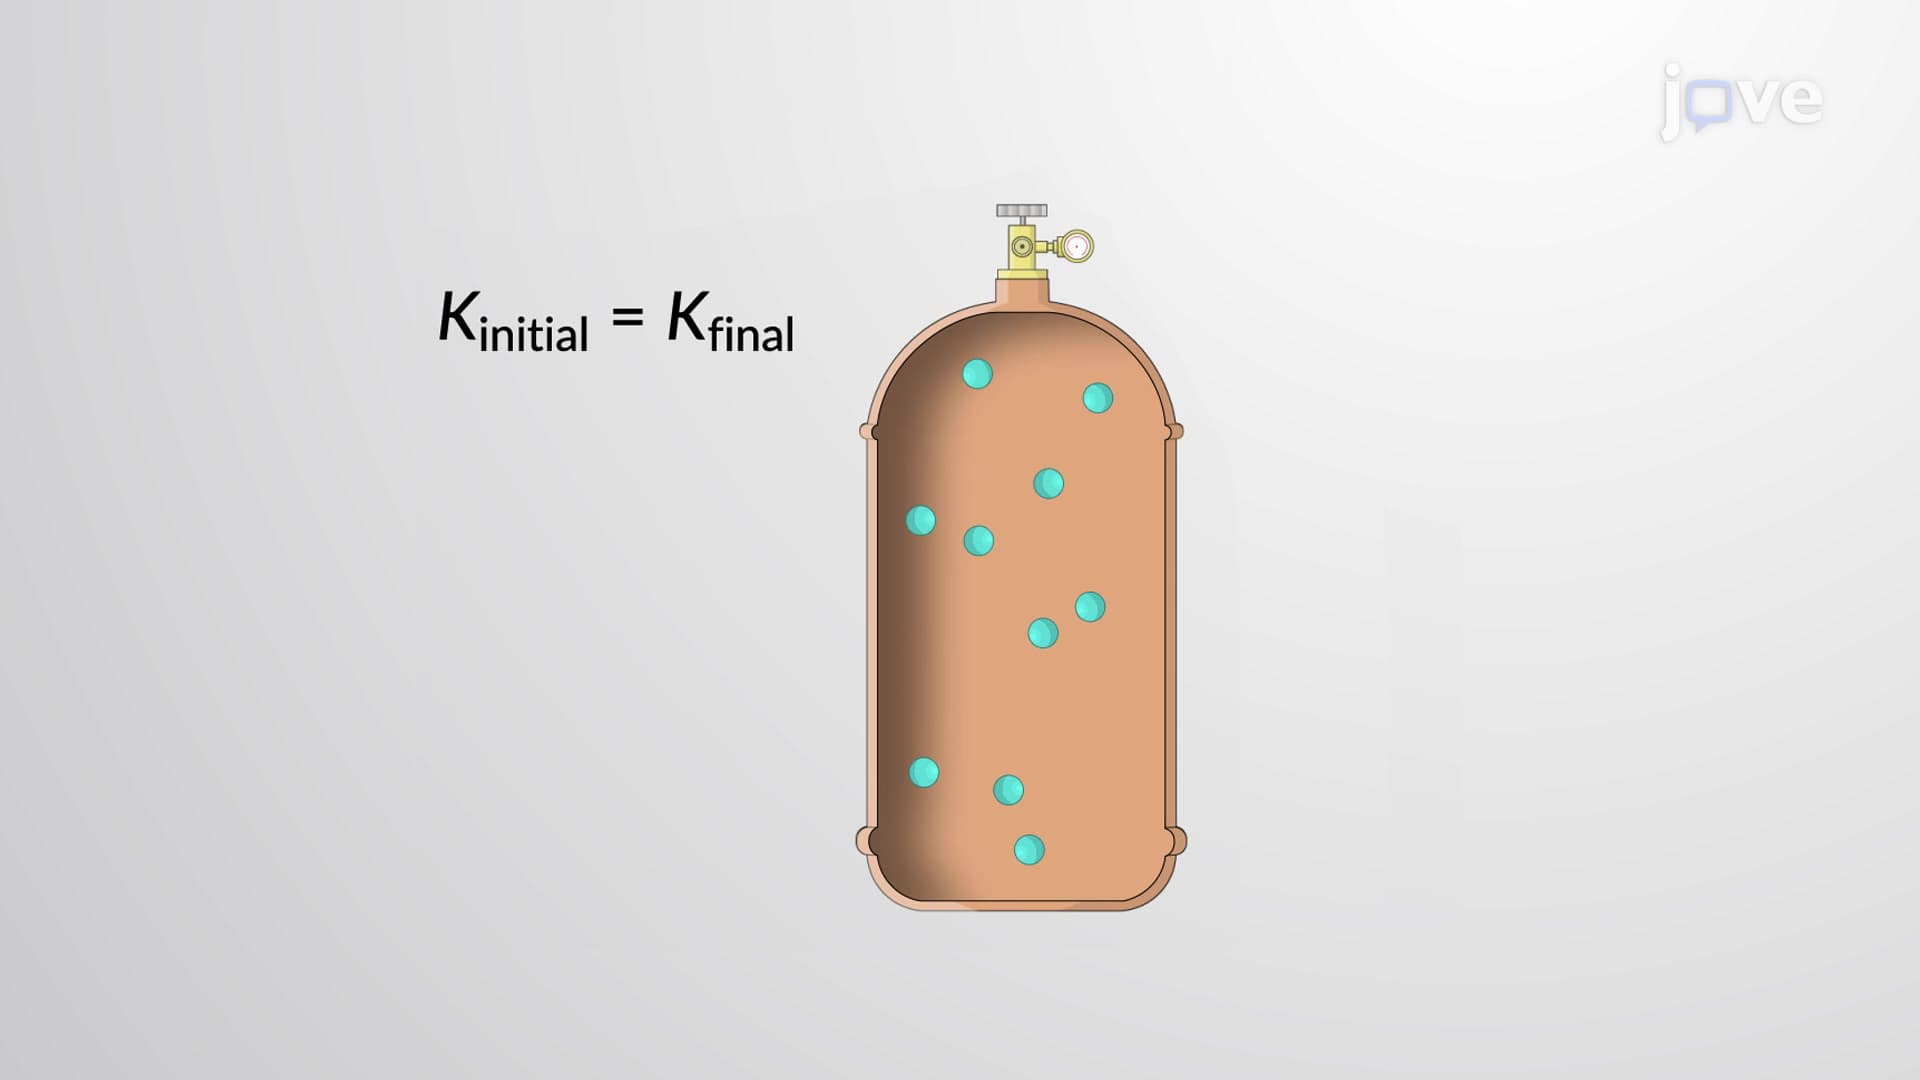
Types Of Collisions - I