Three dimensional stabilization controller based on improved quaternion transformation for fixed-wing UAVs
Related Experiment Video
Updated: Oct 12, 2025
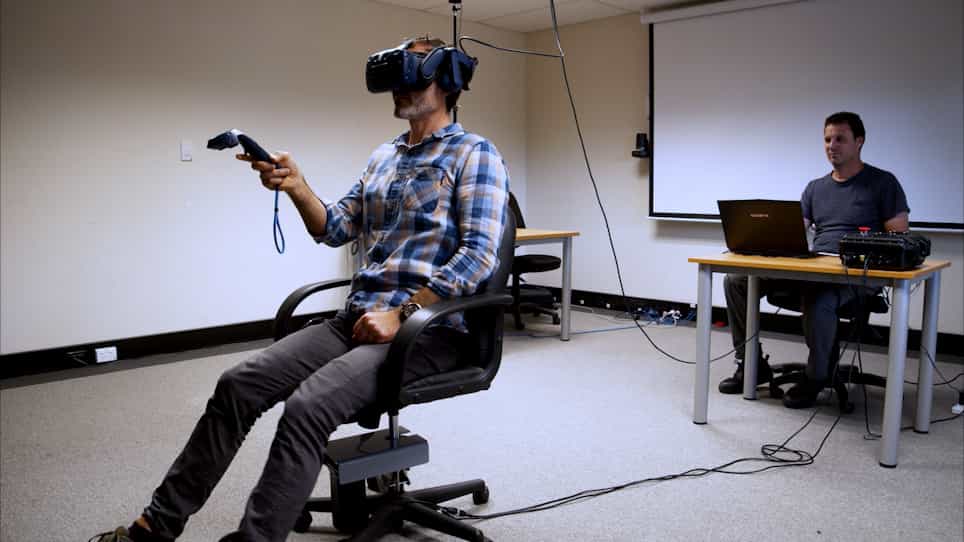
Controlled Rotation of Human Observers in a Virtual Reality Environment
Published on: April 21, 2022
Pengyun Chen1, Tong Guan1, Guobing Zhang1
1College of Mechatronics Engineering, North University of China, Taiyuan 030051, China.

Abstract:
To realize the three-dimensional stabilization control of fixed-wing unmanned aerial vehicles (UAVs), we analyze the nonholonomic characteristics, constraint non-integrability, and controllability of UAVs. To simplify the trigonometric function term in the dynamics of the UAV and avoid the singularity problem of the Euler angle in describing attitude, we use the quaternion theory to transform the dynamics of the UAV to avoid the complex trigonometric function derivation, which makes the dynamic matrix more concise. Based on this, a continuous periodic time-varying controller (CPTVC) is designed, and the effectiveness of the controller is proved using the homogeneous method. Finally, the results of the hardware in a loop simulation indicated that the exponential stability provided by the feedback controller can realize the three-dimensional stabilization of any initial position.

Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System
 01:24
Gyroscope: Precession
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...