Related Experiment Video
Updated: Oct 12, 2025

Folding and Characterization of a Bio-responsive Robot from DNA Origami
Published on: December 3, 2015
A Cut-and-Fold Self-Sustained Compliant Oscillator for Autonomous Actuation of Origami-Inspired Robots
1Department of Mechanical and Aerospace Engineering and University of California, Los Angeles, California, USA.

Abstract:
Origami-inspired robots are of particular interest due to their potential for rapid and accessible design and fabrication of elegant designs and complex functionalities through cutting and folding of flexible two-dimensional sheets or even strings, that is, printable manufacturing. Yet, origami robots still require bulky rigid components or electronics for actuation and control to accomplish tasks with reliability, programmability, ability to output substantial force, and durability, restricting their full potential. In this study, we present a printable self-sustained compliant oscillator that generates periodic actuation using only constant electrical power, without discrete components or electronic control hardware. This oscillator is robust (9 out of 10 prototypes worked successfully on the first try), configurable (with tunable periods from 3 to 12 s), powerful (can overcome hydrodynamic resistance to consistently propel a swimmer at ∼1.6 body lengths/min or 3.66 mm/s), and long lasting (∼103 cycles); it enables driving macroscale devices with prescribed autonomous behaviors, for example, locomotion and sequencing. This oscillator is also fully functional underwater and in high magnetic fields. Our analytical model characterizes essential parameters of the oscillation period, enabling programmable design of the oscillator. The printable oscillator can be integrated into origami-inspired systems seamlessly and monolithically, allowing rapid design and prototyping; the resulting integrated devices are lightweight, low cost, compliant, electronic free, and nonmagnetic, enabling practical applications in extreme areas. We demonstrate the functionalities of the oscillator with: (1) autonomous gliding of a printable swimmer, (2) LED flashing, and (3) fluid stirring. This work paves the way for realizing fully printable autonomous robots with high integration of actuation and control.
Related Concept Videos
 01:30
Oscillations In An LC Circuit
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:30
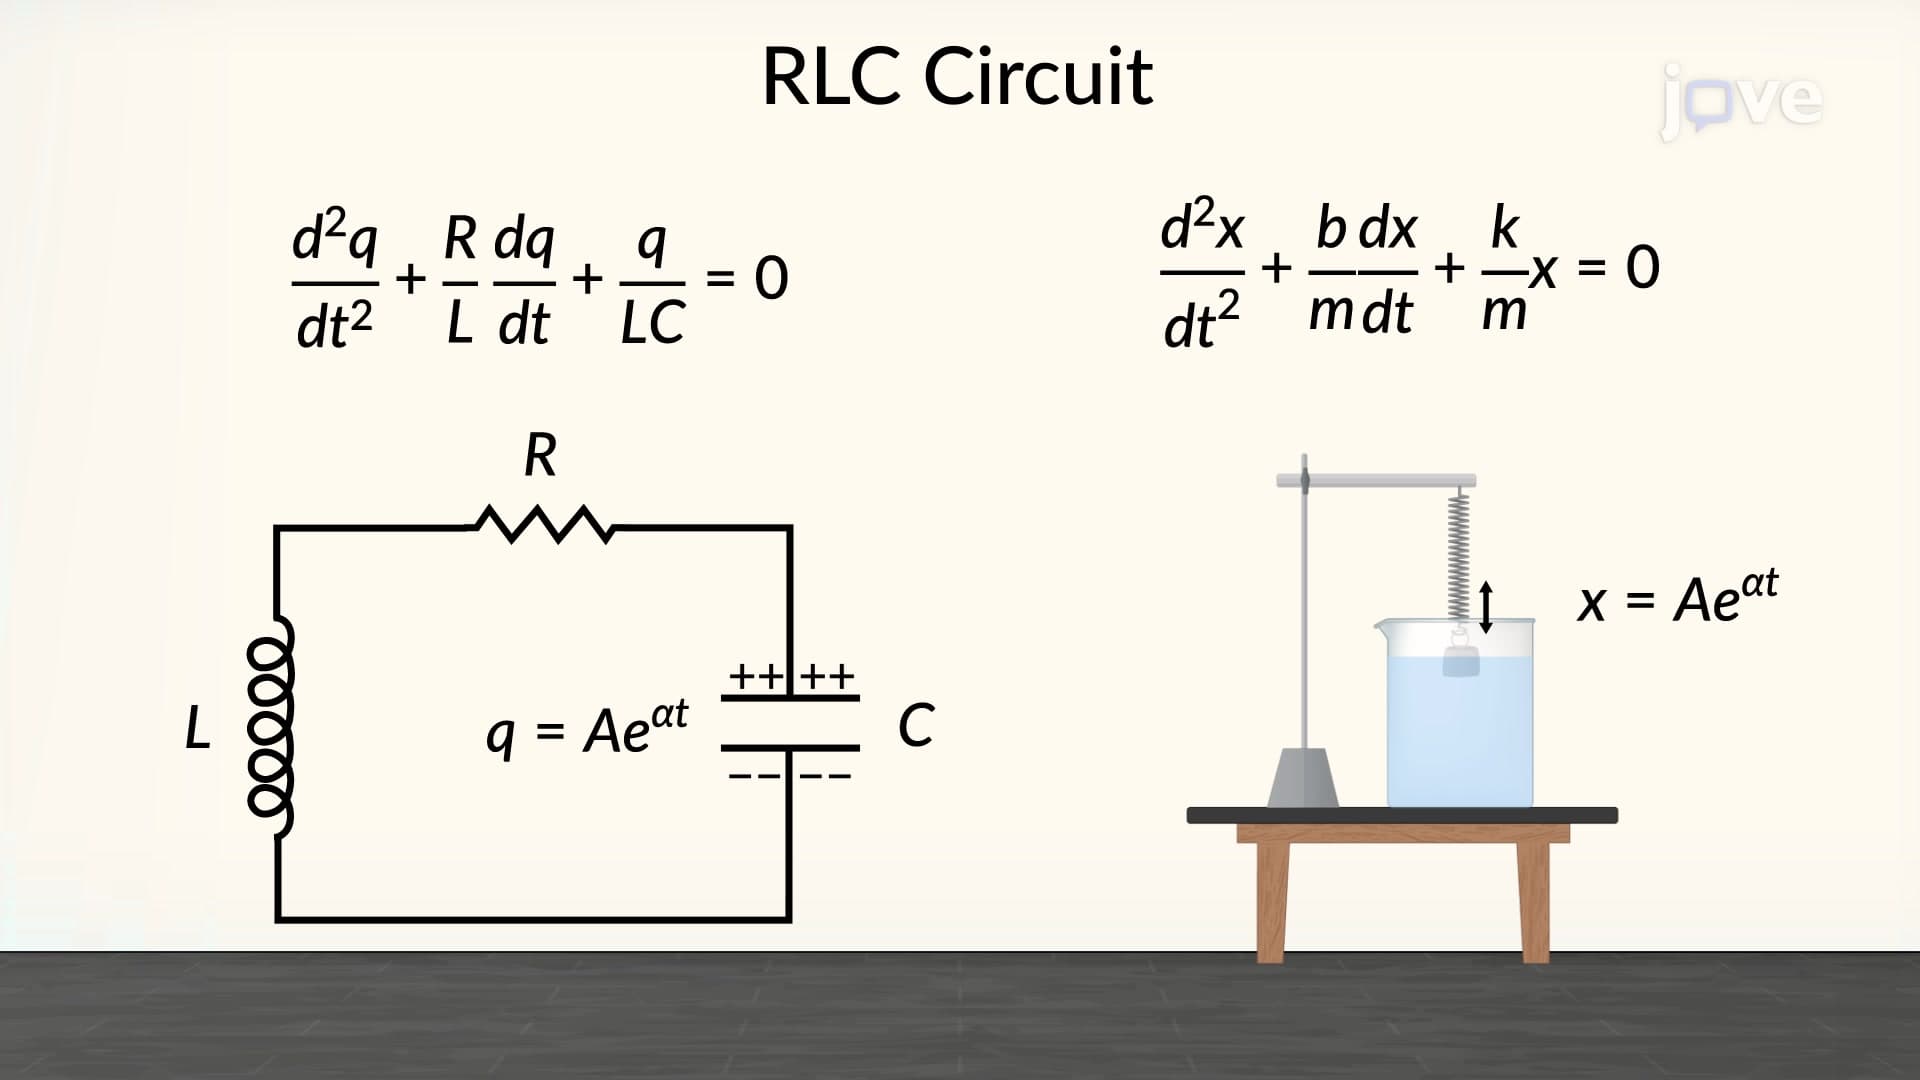
RLC Circuit as a Damped Oscillator
Consider a series RLC circuit. Here, the presence of resistance in the circuit leads to energy loss due to joule heating in the resistance. Therefore, the total electromagnetic energy in the circuit is no longer constant and decreases with time. Since the magnitude of charge, current, and potential difference continuously decreases, their oscillations are said to be damped. This is...
 01:06
Forced Oscillations
 01:17
Design Example: Underdamped Parallel RLC Circuit
Starting with a fixed...
 01:22
Mechanical Systems