Related Experiment Video
Updated: Oct 12, 2025

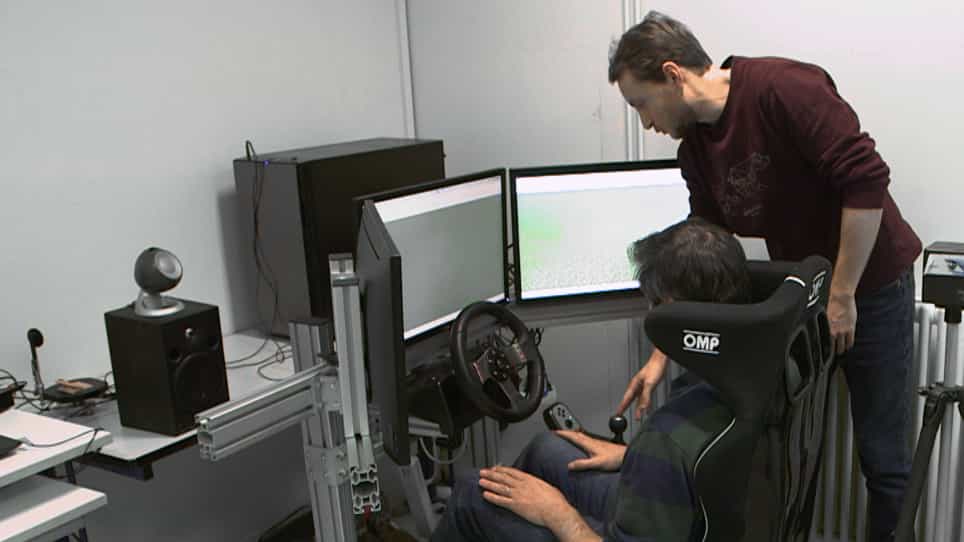
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
A proactive lane-changing risk prediction framework considering driving intention recognition and different
Qiangqiang Shangguan1, Ting Fu1, Junhua Wang1
1The Key Laboratory of Road and Traffic Engineering, Ministry of Education, Tongji University, Shanghai, China; College of Transportation Engineering, Tongji University, 4800 Cao'an Highway, Shanghai 201804, China.

Abstract:
Proactive lane-changing (LC) risk prediction can assist driver's LC decision-making to ensure driving safety. However, most previous studies on LC risk prediction did not consider the driver's intention recognition, which made it difficult to guarantee the timeliness and practicability of LC risk prediction. Moreover, the difference in driving risks and its influencing factors between LC to left lane (LCL) and LC to right lane (LCR) have rarely been investigated. To bridge the above research gaps, this study proposes a proactive LC risk prediction framework which integrates the LC intention recognition module and LC risk prediction module. The Long Short-term Memory (LSTM) neural network with time-series input was employed to recognize the driver's LC intention. The Light Gradient Boosting Machine (LGBM) algorithm was then applied to predict the LC risk. Feature importance analysis was lastly conducted to obtain the key features that affect the LC risk. The highD trajectory dataset was used for framework validation. Results show that the recognition accuracy of the driver's LCL, LCR and lane-keeping (LK) intentions based on the proposed LSTM model are 97%, 96% and 97%, respectively. Meanwhile, the LGBM algorithm outperforms other machine learning algorithms in LC risk prediction. The results from feature importance analysis show that the interaction characteristics of the LC vehicle and its preceding vehicle in the current lane have the greatest impact on the LC risk. The proposed framework could potentially be implemented in advanced driver-assistance system (ADAS) or autonomous driving system for improved driving safety.
Related Concept Videos
 02:24
Predicting Reaction Outcomes
 01:17
Rolling Resistance: Problem Solving
 01:20
Decision Making
Automatic decision-making is fast, intuitive, and relies on gut feelings...
 01:14
Decision Making: Traditional Method
First, a specific claim about the population parameter is decided based on the research question and is stated in a simple form. Further, an opposing statement to this claim is also stated. These statements can act as null and alternative hypotheses, out of which a null hypothesis would be a...
 01:03
Prediction Intervals
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.
 01:12
Observational Learning