Related Experiment Video
Updated: Oct 11, 2025


Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
Distributed Time-Varying Optimization of Second-Order Multiagent Systems Under Limited Interaction Ranges

Abstract:
This article investigates the distributed time-varying optimization problem for second-order multiagent systems (MASs) under limited interaction ranges. The goal is to seek the minimum of the sum of local time-varying cost functions (CFs), where each CF is only available to the corresponding agent. Limited communication range refers to the scenario where the agents have limited sensing and communication capabilities, that is, a pair of agents can communicate with each other only if their distance is within a certain range. To handle such a problem, a new continuous connectivity-preserving mechanism is presented to preserve the connectivity of the considered network. Then, two distributed optimization algorithms are presented to solve the optimization problem with time-varying CFs and time-invariant CFs, respectively. Theoretical analysis and two numerical examples are provided to verify the effectiveness of the methods.
Related Concept Videos
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:18
Second Order systems II
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:15
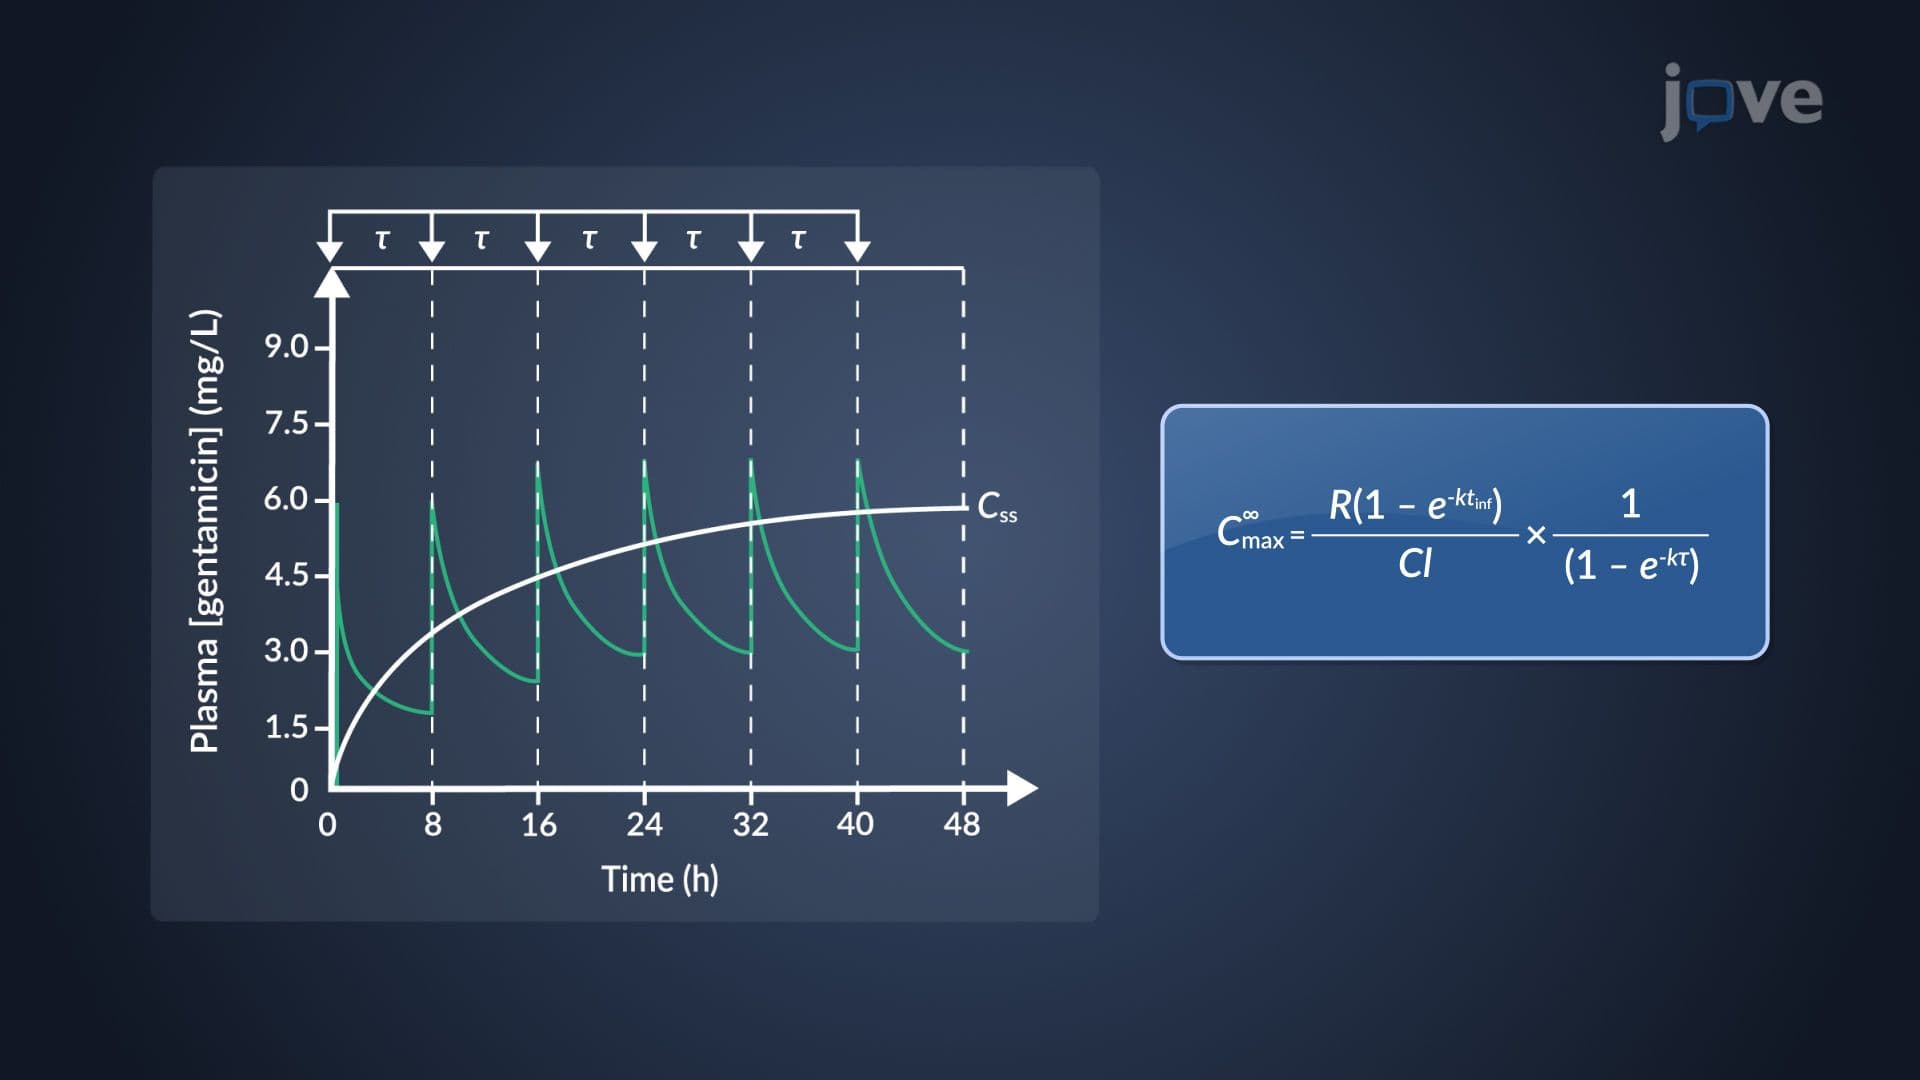
Determination of Multiple Dosing Parameters: Steady-State, Minimum and Maximum Concentrations
 01:22
Multi-input and Multi-variable systems
In the absence...