Related Experiment Video
Updated: Oct 10, 2025


Rod-based Fabrication of Customizable Soft Robotic Pneumatic Gripper Devices for Delicate Tissue Manipulation
Published on: August 2, 2016
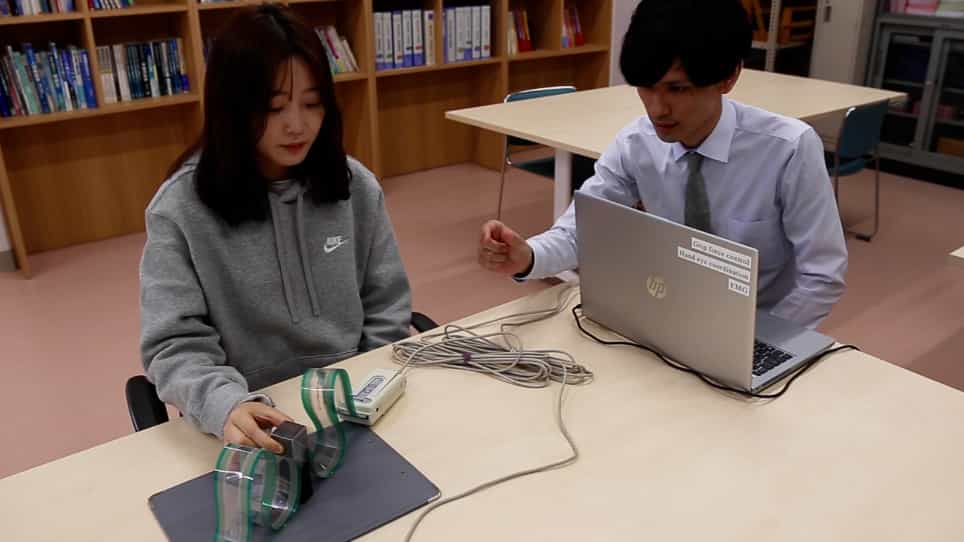
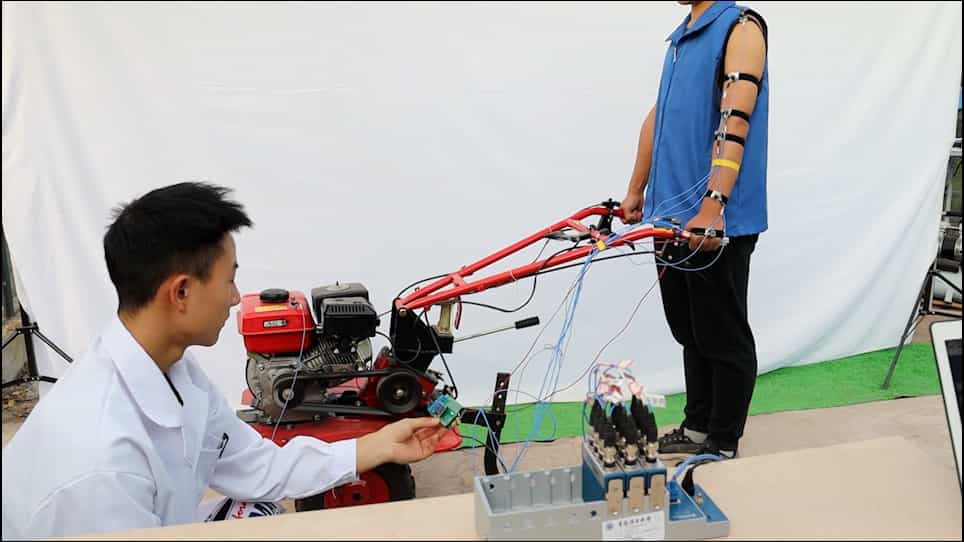
Isolating In-Situ Grip and Push Force Distribution from Hand-Handle Contact Pressure with an Industrial Electric
Cederick Landry1, Daniel Loewen1, Harish Rao1
1Department of Mechanical and Mechatronics Engineering, University of Waterloo, 200 University Avenue West, Waterloo, ON N2L 3G1, Canada.

Objectives:
Grip force during hand tool operation is the primary contributor to tendon strain and related wrist injuries, whereas push force is a contributor to shoulder injuries. However, both cannot be directly measured using a single measurement instrument. The objective of this research was to develop and test an algorithm to isolate the grip and push force distributions from in-situ hand-handle pressure measurements and to quantify their distributions among industrial workers using an electric nutrunner.
Methods:
Experienced automobile assembly line workers used an industrial nutrunner to tighten fasteners at various locations and postures. The pressure applied by the hand on the tool handle was measured dynamically using pressure sensors mounted on the handle. An algorithm was developed to compute the push force applied to the handle of an electric pistol-grip nutrunner based on recorded pressure measurements. An optimization problem was solved to find the contribution of each measured pressure to the actual pushing force of the tool. Finally, the grip force was determined from the difference between the measured pressure and the calculated pushing pressure.
Results:
The grip force and push force were successfully isolated and there was no correlation between the two forces. The computed grip force increased from low to high fastener locations, whereas the push force significantly increased during overhead fastening. A significant difference across the participants' computed grip forces was observed. The grip force distribution showed that its contribution to total hand force was larger than other definitions in the literature.
Conclusions:
The developed algorithm can aid in better understanding the risk of injury associated with different tasks through the notion of grip and push force distribution. This was shown to be important as even workers with considerable power tool experience applied significantly more grip and push force than other participants, all of whom successfully completed each task. Moreover, the fact that both forces were uncorrelated shows the need for extracting them independently.
Related Concept Videos
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:19
Net Torque Calculations
 01:18
Stress Concentrations in Circular Shafts
 01:17
Frictional Forces on Screws
A jack with a square-threaded screw is a mechanical device used to lift heavy loads by applying a force at its handle. When the force is applied, the screw turns, raising the load. The screw can...
 01:13
Angle of Twist: Problem Solving
 01:09
Transmission Shafts: Problem Solving
Next, use bending moment diagrams for the shaft to...