Related Experiment Video
Updated: Oct 10, 2025
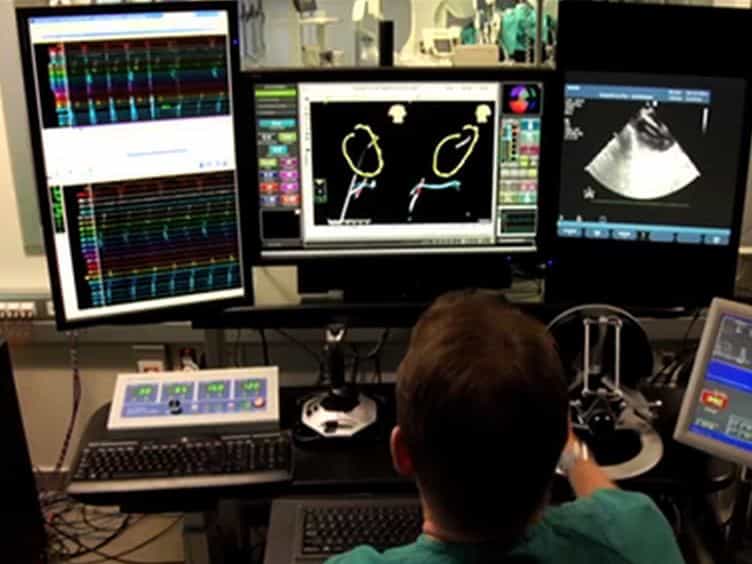
Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
Localization of Point-of-Interest Positions on Cardiac Surface for Robotic-Assisted Beating Heart Surgery

Abstract:
One of the critical components of robotic-assisted beating heart surgery is precise localization of a point-of-interest (POI) position on cardiac surface, which needs to be tracked by the robotic instruments. This is challenging as the incoming sensor measurements, from which POI position is localized, might be noisy and incomplete. This paper presents two Bayesian filtering based localization approaches to localize POI position online from sonomicrometer measurements. Specifically, extended Kalman filter (EKF) and particle filter (PF) localization algorithms are explored to estimate the state of POI position. The estimations of upcoming heart motion generated by the generalized adaptive predictor, which is demonstrated in the authors' past work, are also incorporated to generate an improved motion model. The proposed methods are validated with prerecorded in-vivo heart motion data.