Related Experiment Video
Updated: Oct 10, 2025
A Method for Evaluating Timeliness and Accuracy of Volitional Motor Responses to Vibrotactile Stimuli
Published on: August 2, 2016
Locomotion Control With Frequency and Motor Pattern Adaptations
Mathias Thor1, Beck Strohmer1, Poramate Manoonpong1,2
1Embodied AI and Neurorobotics Lab, SDU Biorobotics, The Mærsk Mc-Kinney Møller Institute, The University of Southern Denmark, Odense, Denmark.

Abstract:
Existing adaptive locomotion control mechanisms for legged robots are usually aimed at one specific type of adaptation and rarely combined with others. Adaptive mechanisms thus stay at a conceptual level without their coupling effect with other mechanisms being investigated. However, we hypothesize that the combination of adaptation mechanisms can be exploited for enhanced and more efficient locomotion control as in biological systems. Therefore, in this work, we present a central pattern generator (CPG) based locomotion controller integrating both a frequency and motor pattern adaptation mechanisms. We use the state-of-the-art Dual Integral Learner for frequency adaptation, which can automatically and quickly adapt the CPG frequency, enabling the entire motor pattern or output signal of the CPG to be followed at a proper high frequency with low tracking error. Consequently, the legged robot can move with high energy efficiency and perform the generated locomotion with high precision. The versatile state-of-the-art CPG-RBF network is used as a motor pattern adaptation mechanism. Using this network, the motor patterns or joint trajectories can be adapted to fit the robot's morphology and perform sensorimotor integration enabling online motor pattern adaptation based on sensory feedback. The results show that the two adaptation mechanisms can be combined for adaptive locomotion control of a hexapod robot in a complex environment. Using the CPG-RBF network for motor pattern adaptation, the hexapod learned basic straight forward walking, steering, and step climbing. In general, the frequency and motor pattern mechanisms complement each other well and their combination can be seen as an essential step toward further studies on adaptive locomotion control.
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:22
Muscle Stimulation Frequency
Wave summation
At low firing rates, motor neurons induce individual twitch contractions in muscle fibers. These twitches...
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:11
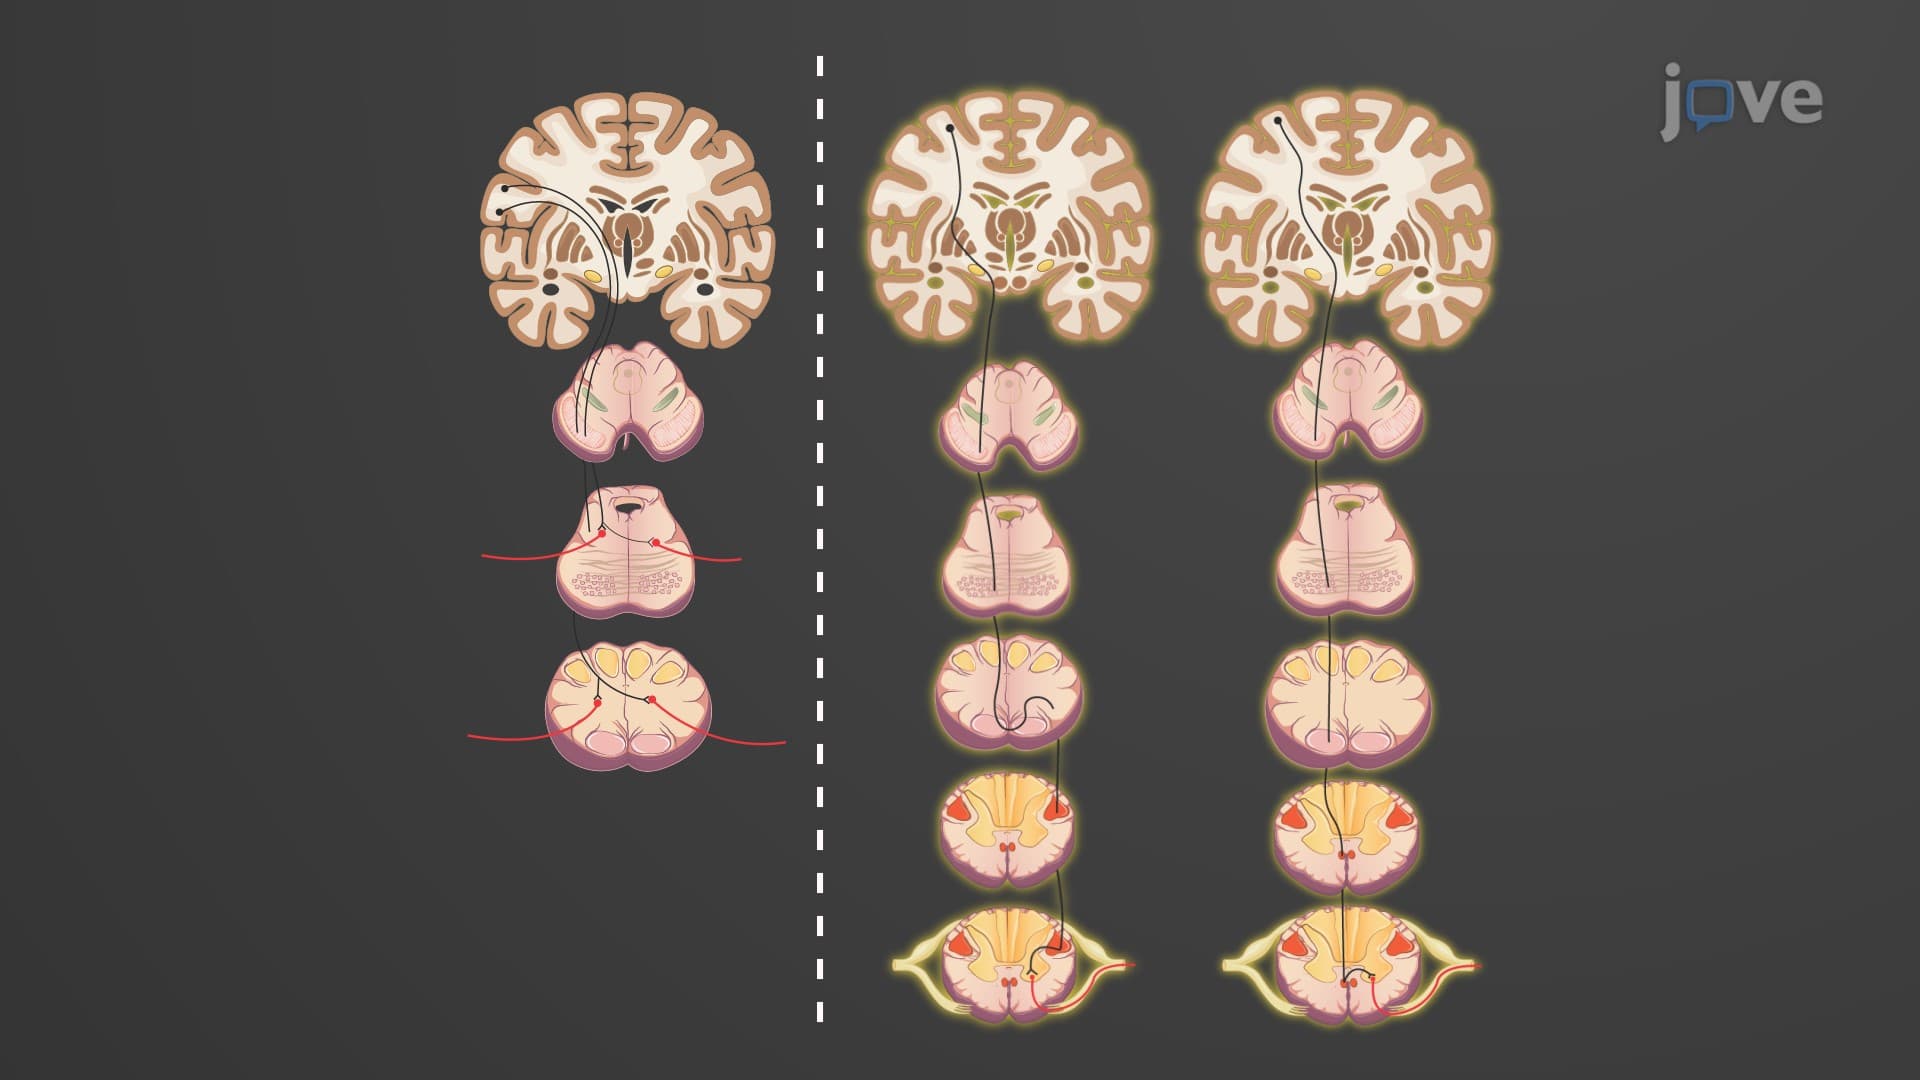
Direct Motor Pathways
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
 01:28
Load-frequency control
 01:20
Motor Unit Stimulation
The latent period of contraction marks the onset of excitation-contraction coupling, when the action potential propagates across the sarcolemma, preparing the muscle fibers for contraction. As the fibers enter the contraction phase, the...