Related Experiment Video
Updated: Oct 9, 2025


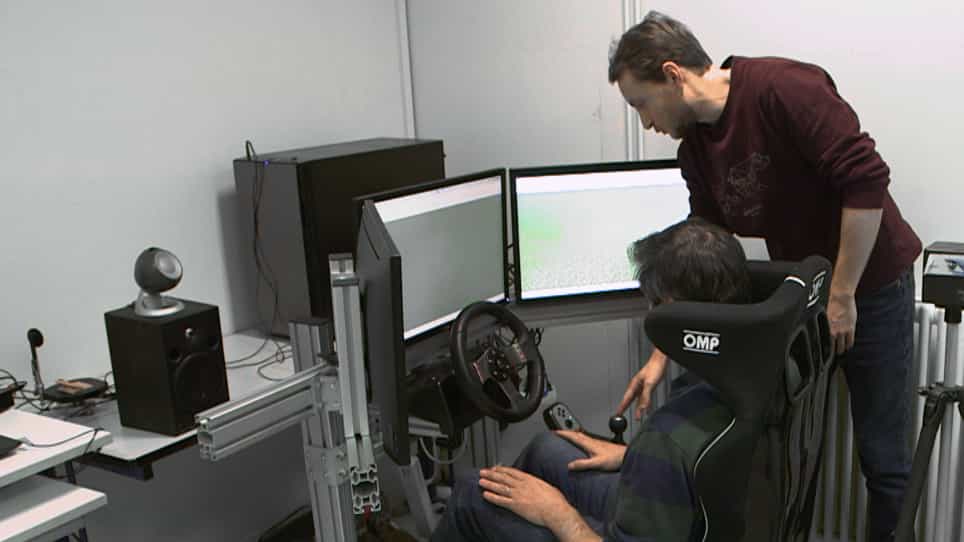
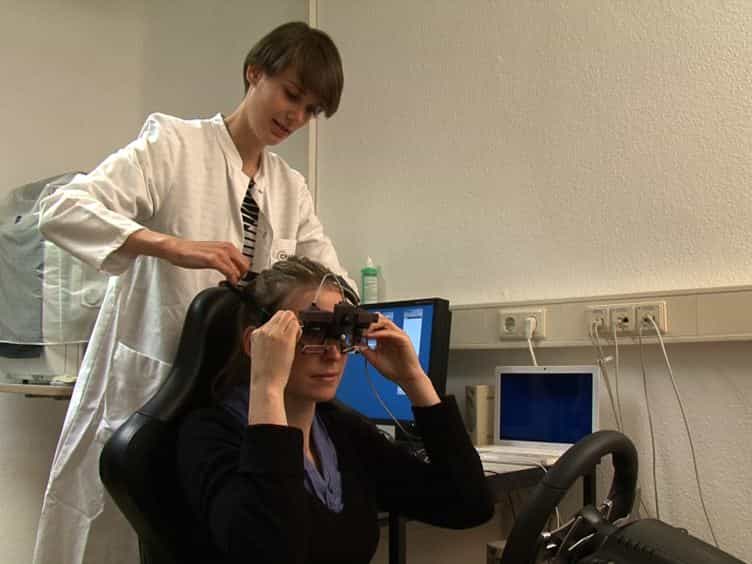
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Takeover requests for automated driving: The effects of signal direction, lead time, and modality on takeover
Gaojian Huang1, Brandon J Pitts2
1Department of Industrial and Systems Engineering, San Jose State University, One Washington Sq., San Jose, CA 95192, United States.

Abstract:
Vehicle-to-driver takeover will still be needed in semi-autonomous vehicles. Due to the complexity of the takeover process, it is important to develop interfaces to support good takeover performance. Multimodal displays have been proposed as a candidate for the design of takeover requests (TORs), but many questions remain unanswered regarding the effectiveness of this approach. This study investigated the effects of takeover signal direction (ipsilateral vs. contralateral), lead time (4 vs. 7 s), and modality (uni-, bi-, and trimodal combinations of visual, auditory, and tactile signals) on automated vehicle takeover performance. Twenty-four participants rode in a simulated SAE Level 3 vehicle and performed a series of takeover tasks when presented with a TOR. Overall, single and multimodal signals with a tactile component were correlated with the faster takeover and information processing times, and were perceived as most useful. Ipsilateral signals showed a marginally significant benefit to takeover times compared to contralateral signals. Finally, a shorter lead time was associated with faster takeover times, but also poorer takeover quality. Findings from this study can inform the design of in-vehicle information and warning systems for next-generation transportation.
More Related Videos
Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:22
Multi-input and Multi-variable systems
In the absence...
 01:25
Directional Relays
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...