A Pose-Only Solution to Visual Reconstruction and Navigation
Related Experiment Video
Updated: Oct 8, 2025
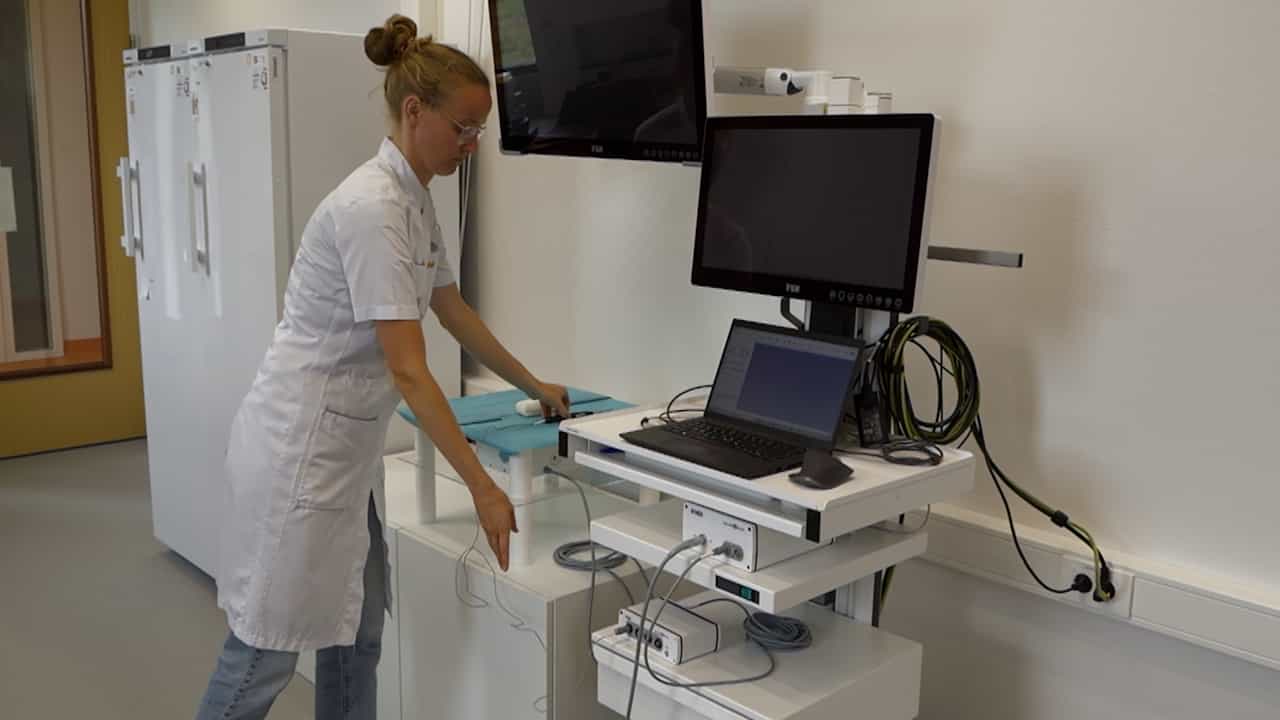
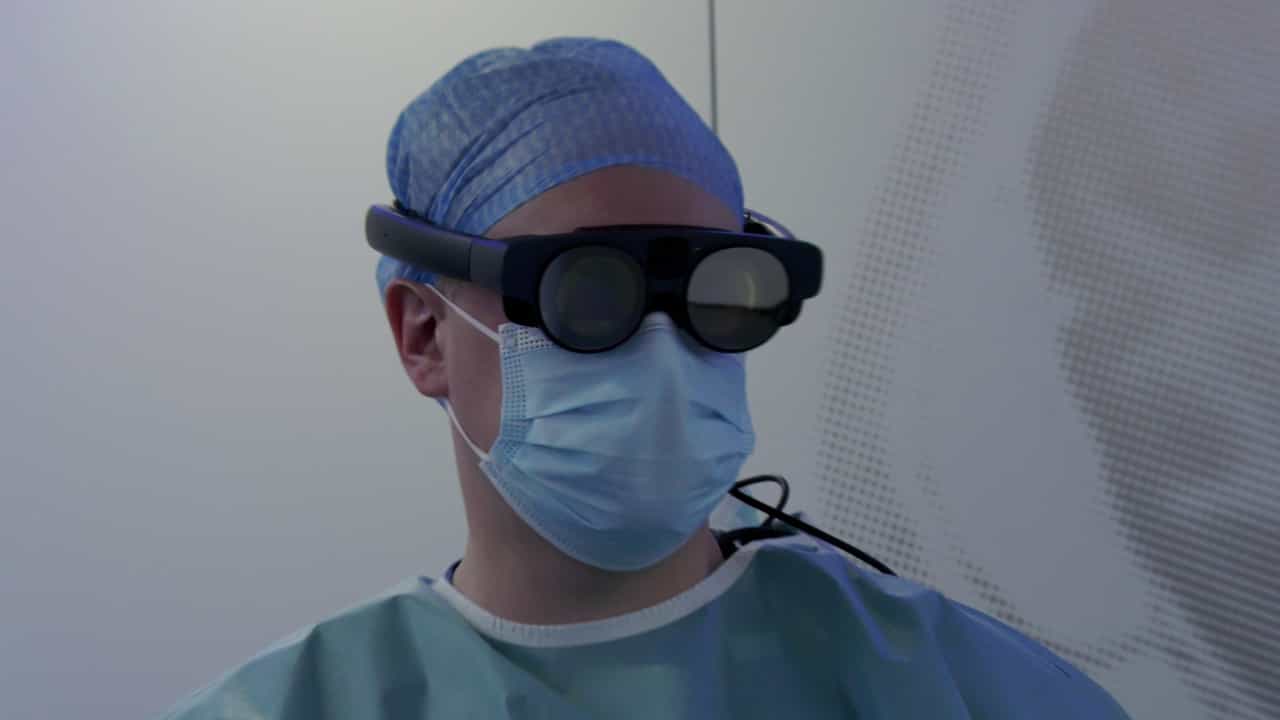
Technical Approach for Infrared Tracking for Soft Tissue Navigation with a Holographic Head-Mounted Display and Preclinical Validation
Published on: September 2, 2025

Abstract:
Visual navigation and three-dimensional (3D) scene reconstruction are essential for robotics to interact with the surrounding environment. Large-scale scenarios and computational robustness are great challenges facing the research community to achieve this goal. This paper raises a pose-only imaging geometry representation and algorithms that might help solve these challenges. The pose-only representation, equivalent to the classical multiple-view geometry, is discovered to be linearly related to camera global translations, which allows for efficient and robust camera motion estimation. As a result, the spatial feature coordinates can be analytically reconstructed and do not require nonlinear optimization. Comprehensive experiments demonstrate that the computational efficiency of recovering the scene and associated camera poses is significantly improved by 2-4 orders of magnitude.

Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:03
Centroid of a Body: Problem Solving
The x-coordinates and y-coordinates of each element's...