Force Control Strategy of Five-Digit Precision Grasping With Aligned and Unaligned Configurations
Related Experiment Video
Updated: Oct 8, 2025
Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
Po-Tsun Chen1,2, Hsiu-Yun Hsu3, You-Hua Su4
1Chang Gung University, Taoyuan.

Objective:
To investigate the digit force control during a five-digit precision grasp in aligned (AG) and unaligned grasping (UG) configurations.
Background:
The effects of various cylindrical handles for tools on power grasp performance have been previously investigated. However, there is little information on force control strategy of precision grasp to fit various grasping configurations.
Method:
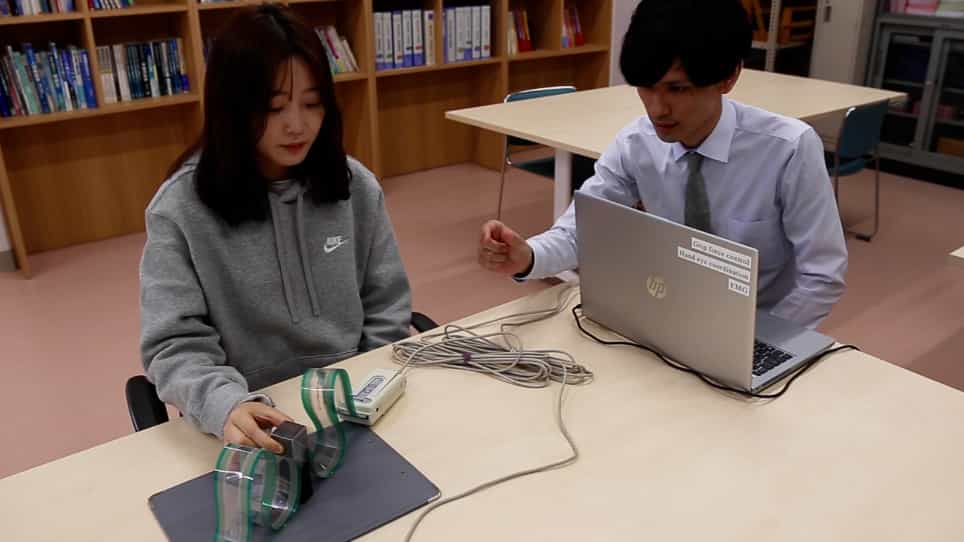
Twenty healthy young adults were recruited to perform a lift-hold-lower task. The AG and UG configurations on a cylindrical simulator with force transducers were adjusted for each individual. The applied force and moment, the force variability during holding, and force correlations between thumb and each finger were measured.
Result:
No differences in applied force, force correlation, repeatability, and variability were found between configurations. However, the moments applied in UG were significantly larger than those in AG.
Conclusion:
The force control during precision grasp did not change significantly across AG and UG except for the digit moment. The simulator is controlled efficiently with large moment during UG, which is thus the optimal configuration for precision grasping with a cylindrical handle. Further research should consider the effects of task type and handle design on force control, especially for individuals with hand disorders.
Application:
To design the handle of specific tool, one should consider the appropriate configuration according to the task requirements of precision grasping to reduce the risk of accumulating extra loads on digits with a cylindrical handle.
Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...