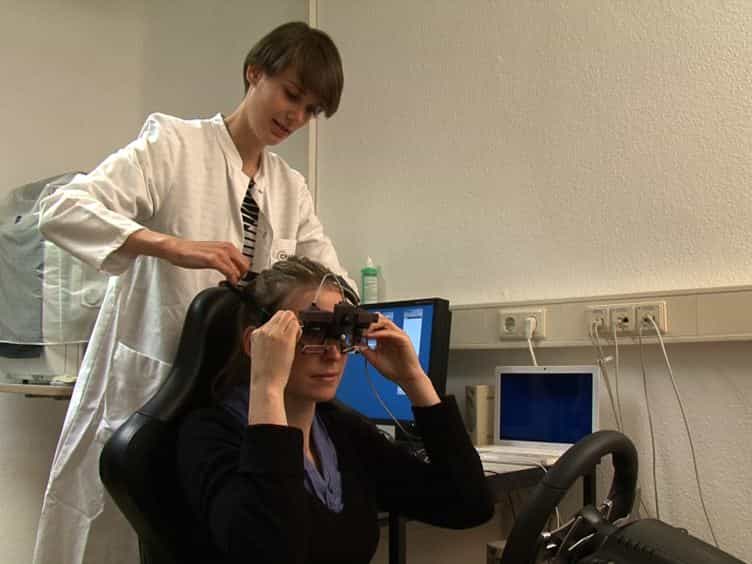
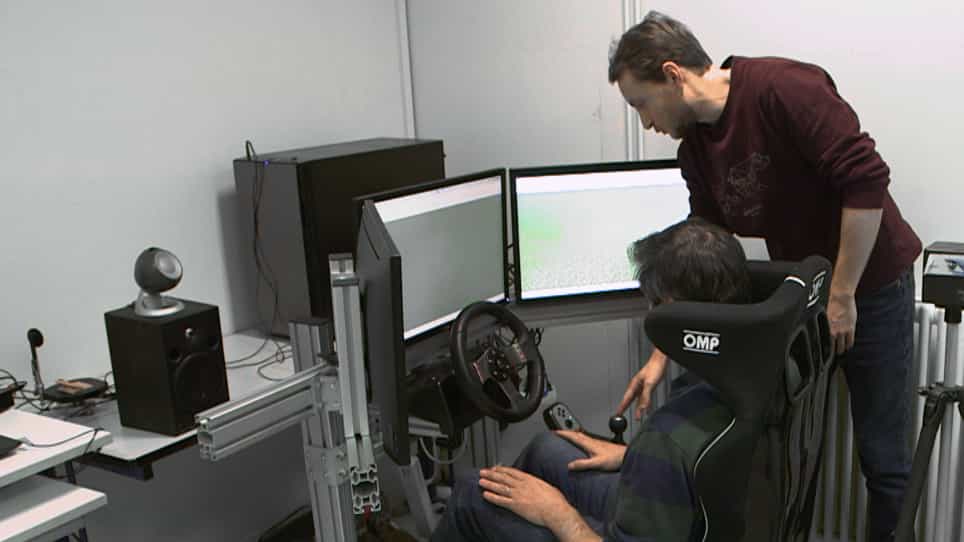
Related Experiment Video
Updated: Oct 7, 2025


Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Driver operational level identification of driving risk and graded time-based alarm under near-crash conditions: A
Xianyu Li1, Zhongyin Guo2, Yi Li3
1Tongji Architectural Design (Group) Co. Ltd, Shanghai 200092, China; Shanghai Engineering Research Center of Road Safety and Smart Mobility, Shanghai 200092, China.

Abstract:
Rear-end collision and side collision are two types of accidents with the highest accident rate in the world. Numerous studies have focused on rear-end accident research, but only a few constructive countermeasures are put forward. Driving risk evolution at the driver operational level before an accident is critical to collision avoidance. This paper puts forward a driver operational level identification of driving risk and graded alarm under near-crash conditions. Firstly, driving simulation is utilized to acquire the operation data of SV (subjective vehicle) under the condition of emergent deceleration of LV (leading vehicle). The kinematic model is built to characterize the law of the risk discrimination indices of SV including THW (time headway), SHW (space headway) and TTCi (the reciprocal of time to collision). The predicted results are consistent with the naturalistic driving data. Secondly, the three-dimensional distribution 'speed-spacing-TTCi' is applied to classify the risky driving state of SV. The precarious distribution is concentrated at the area where relative velocity increased to 23-40 km/h and spacing decreased to 18-30 m. Finally, based on the reaction time and braking distance reduction, the optimal external intervention is determined to be the acousto-optic way by driving simulation. For moderate drivers, a three-level alarm of 2.94 s, 1.94 s and 1.1 s is calibrated considering different driving styles and cumulative frequency curve of reaction time.