Related Experiment Video
Updated: Oct 7, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Geometric Brownian information engine: Upper bound of the achievable work under feedback control
Syed Yunus Ali1, Rafna Rafeek1, Debasish Mondal1
1Department of Chemistry and Center for Molecular and Optical Sciences and Technologies, Indian Institute of Technology Tirupati, Yerpedu 517619, Andhra Pradesh, India.

Abstract:
We design a geometric Brownian information engine by considering overdamped Brownian particles inside a two-dimensional monolobal confinement with irregular width along the transport direction. Under such detention, particles experience an effective entropic potential which has a logarithmic form. We employ a feedback control protocol as an outcome of error-free position measurement. The protocol comprises three stages: measurement, feedback, and relaxation. We reposition the center of the confinement to the measurement distance (xp) instantaneously when the position of the trapped particle crosses xp for the first time. Then, the particle is allowed for thermal relaxation. We calculate the extractable work, total information, and unavailable information associated with the feedback control using this equilibrium probability distribution function. We find the exact analytical value of the upper bound of extractable work as (53-2ln2)kBT. We introduce a constant force G downward to the transverse coordinate (y). A change in G alters the effective potential of the system and tunes the relative dominance of entropic and energetic contributions in it. The upper bound of the achievable work shows a crossover from (53-2ln2)kBT to 12kBT when the system changes from an entropy-dominated regime to an energy-dominated one. Compared to an energetic analog, the loss of information during the relaxation process is higher in the entropy-dominated region, which accredits the less value in achievable work. Theoretical predictions are in good agreement with the Langevin dynamics simulation studies.

Related Concept Videos
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:14
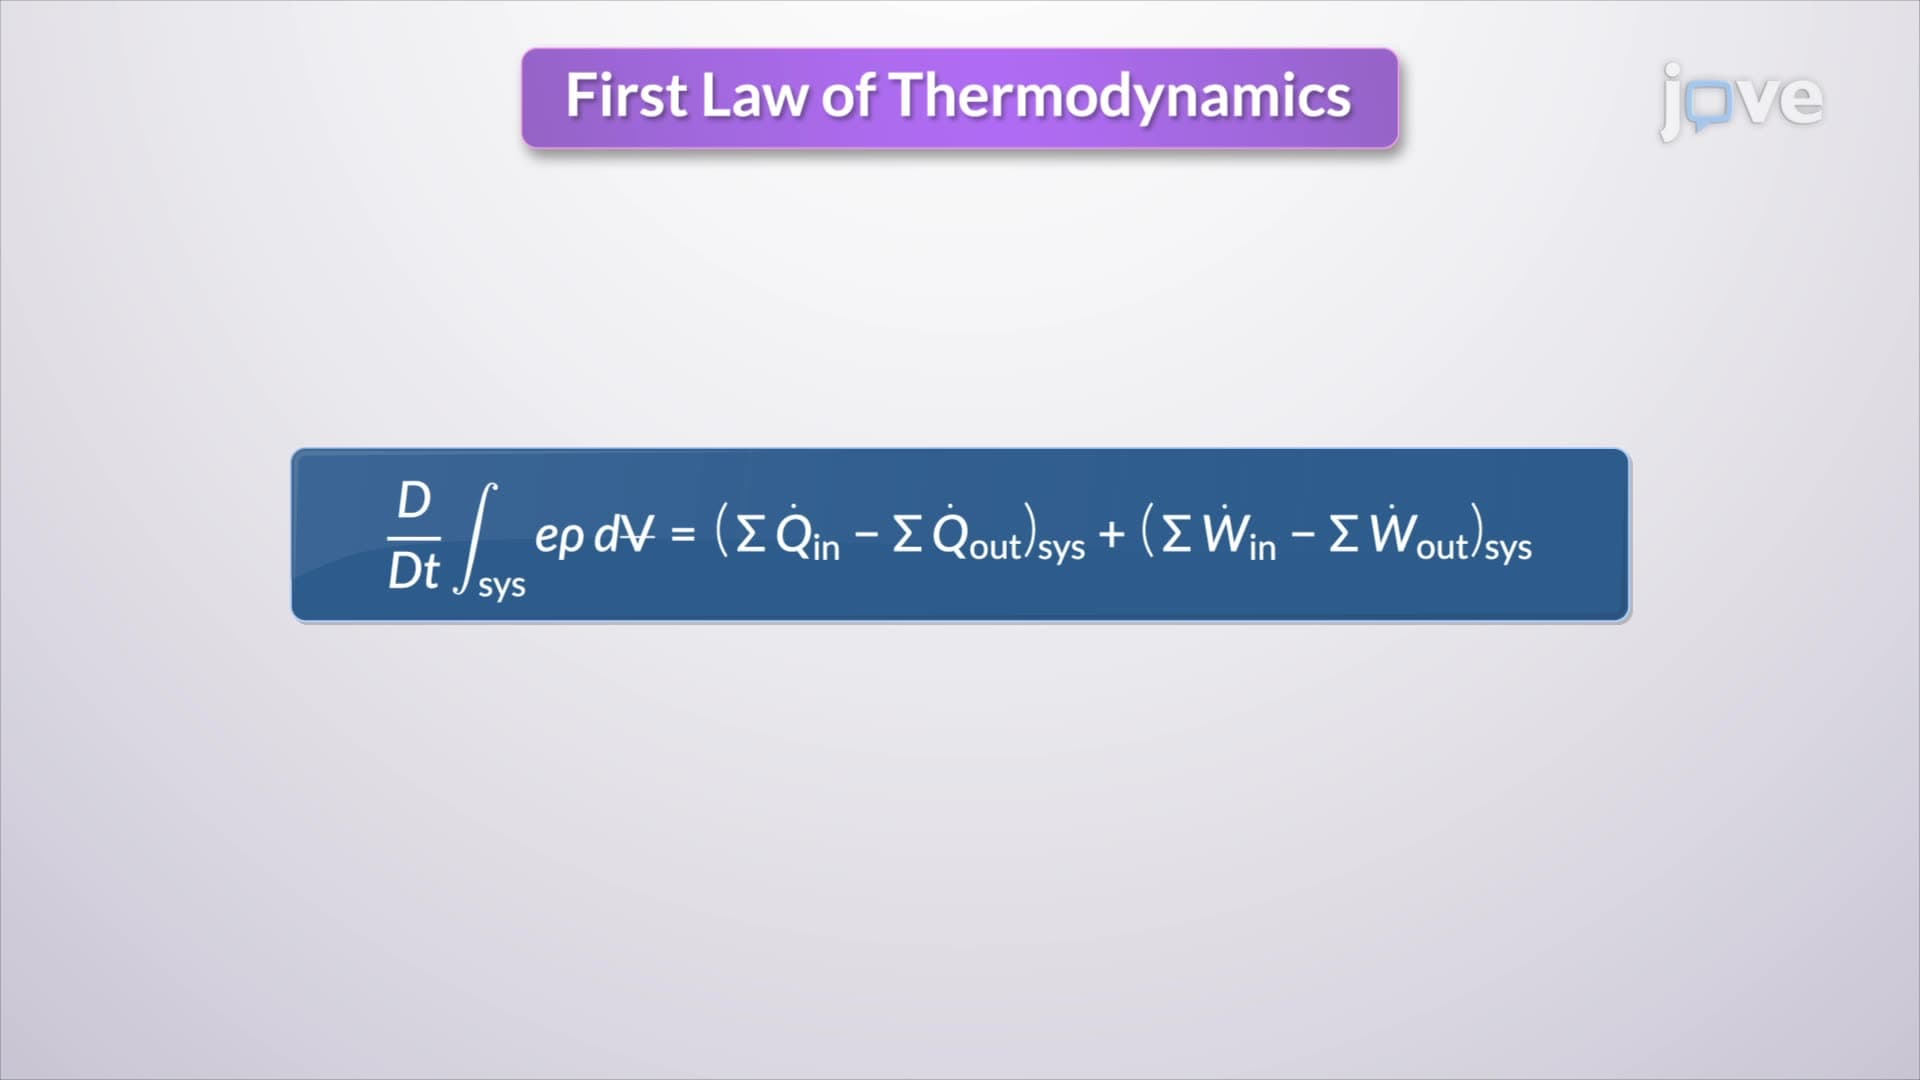
Conservation of Energy in Control Volume
For steady flow systems, the time derivative of the stored energy becomes zero since there is no energy accumulation within the control volume. This simplifies the energy equation to:
 01:10
Control Systems
At the heart...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....