Related Experiment Video
Updated: Oct 5, 2025


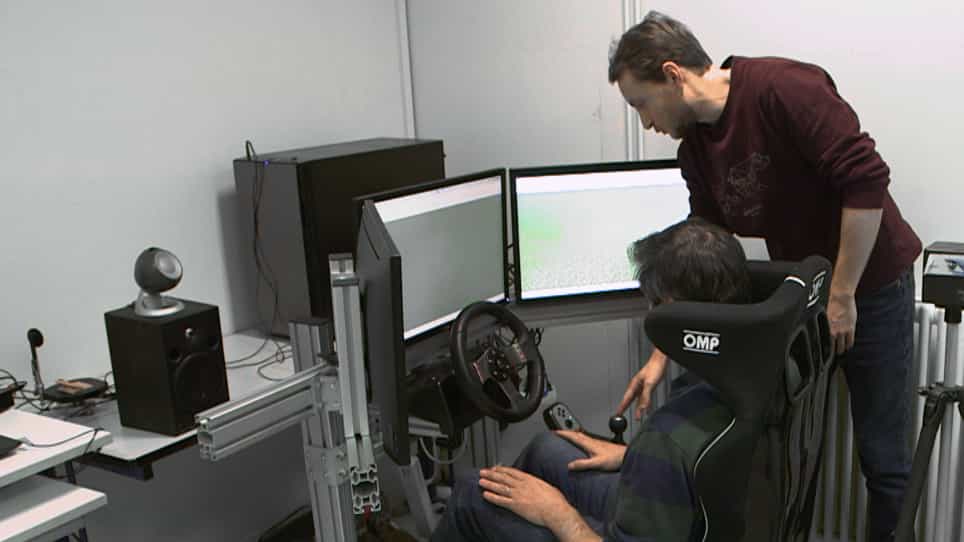
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
A Novel Intelligent Approach to Lane-Change Behavior Prediction for Intelligent and Connected Vehicles
Luyao Du1, Wei Chen1, Jing Ji2
1School of Automation, Wuhan University of Technology, Wuhan 430070, China.

Abstract:
The prediction of lane-change behavior is a challenging issue in intelligent and connected vehicles (ICVs), which can help vehicles predict in advance and change lanes safely. In this paper, a novel intelligent approach, which considering both the driving style-based lane-change environment and the driving trajectory-related parameters of the ICV and surrounding vehicles, is proposed to predict the lane-change behaviors for ICVs. By analyzing the characteristics of the lane-change behavior of the vehicle, a modified dataset for the prediction of lane-change behavior was established based on the Next-Generation Simulation (NGSIM) dataset, which is made up of real vehicle trajectories collected by camera. In the proposed approach, the hidden Markov model (HMM)-based model is designed to judge whether the current environment is suitable for lane change according to the driving environment parameters around the vehicle; then according to the driving state of the vehicle, a learning-based prediction-then-judgment model is proposed and designed to realize the prediction of the ICV's lane-change behavior. Experiments are implemented by using the modified dataset. From the experimental results, the lane-change probability value on the target lane in the truth of the lane-change behavior calculated by the designed HMM-based model is basically above 0.5, indicating that the model can make a more accurate judgment on the surrounding lane-change environment. The proposed learning-based prediction-then-judgment model has an accuracy of 99.32% for the prediction of lane-change behavior, and the accuracy of the lane-change detection algorithm in the model is 99.56%. The experimental results show that the proposed approach has a good performance in the prediction of lane-change behavior, which could effectively assist ICVs to change lanes safely.

Related Concept Videos
 01:14
Decision Making: Traditional Method
First, a specific claim about the population parameter is decided based on the research question and is stated in a simple form. Further, an opposing statement to this claim is also stated. These statements can act as null and alternative hypotheses, out of which a null hypothesis would be a...
 01:12
Observational Learning
 01:20
Decision Making
Automatic decision-making is fast, intuitive, and relies on gut feelings...
 01:17
Rolling Resistance: Problem Solving
 01:28
Automatic Processing and Automatic Social Behavior
 01:25
The Anchoring-and-Adjustment Heuristic